Journal of System Simulation ›› 2026, Vol. 38 ›› Issue (8): 2250-2264.doi: 10.16182/j.issn1004731x.joss.25-0947
• Papers • Previous Articles
Wang Juan1,2, Li Guorui2, Fan Zhiyong1,2, Chen Huijie2
Received:2025-09-29
Revised:2025-10-26
Online:2026-08-28
Published:2026-08-31
Contact:
Li Guorui
CLC Number:
Wang Juan, Li Guorui, Fan Zhiyong, Chen Huijie. Fault-tolerant Control Method for All-type Actuator Faults of eVTOL Aircraft[J]. Journal of System Simulation, 2026, 38(8): 2250-2264.
Fig. 1
Coaxial octocopter
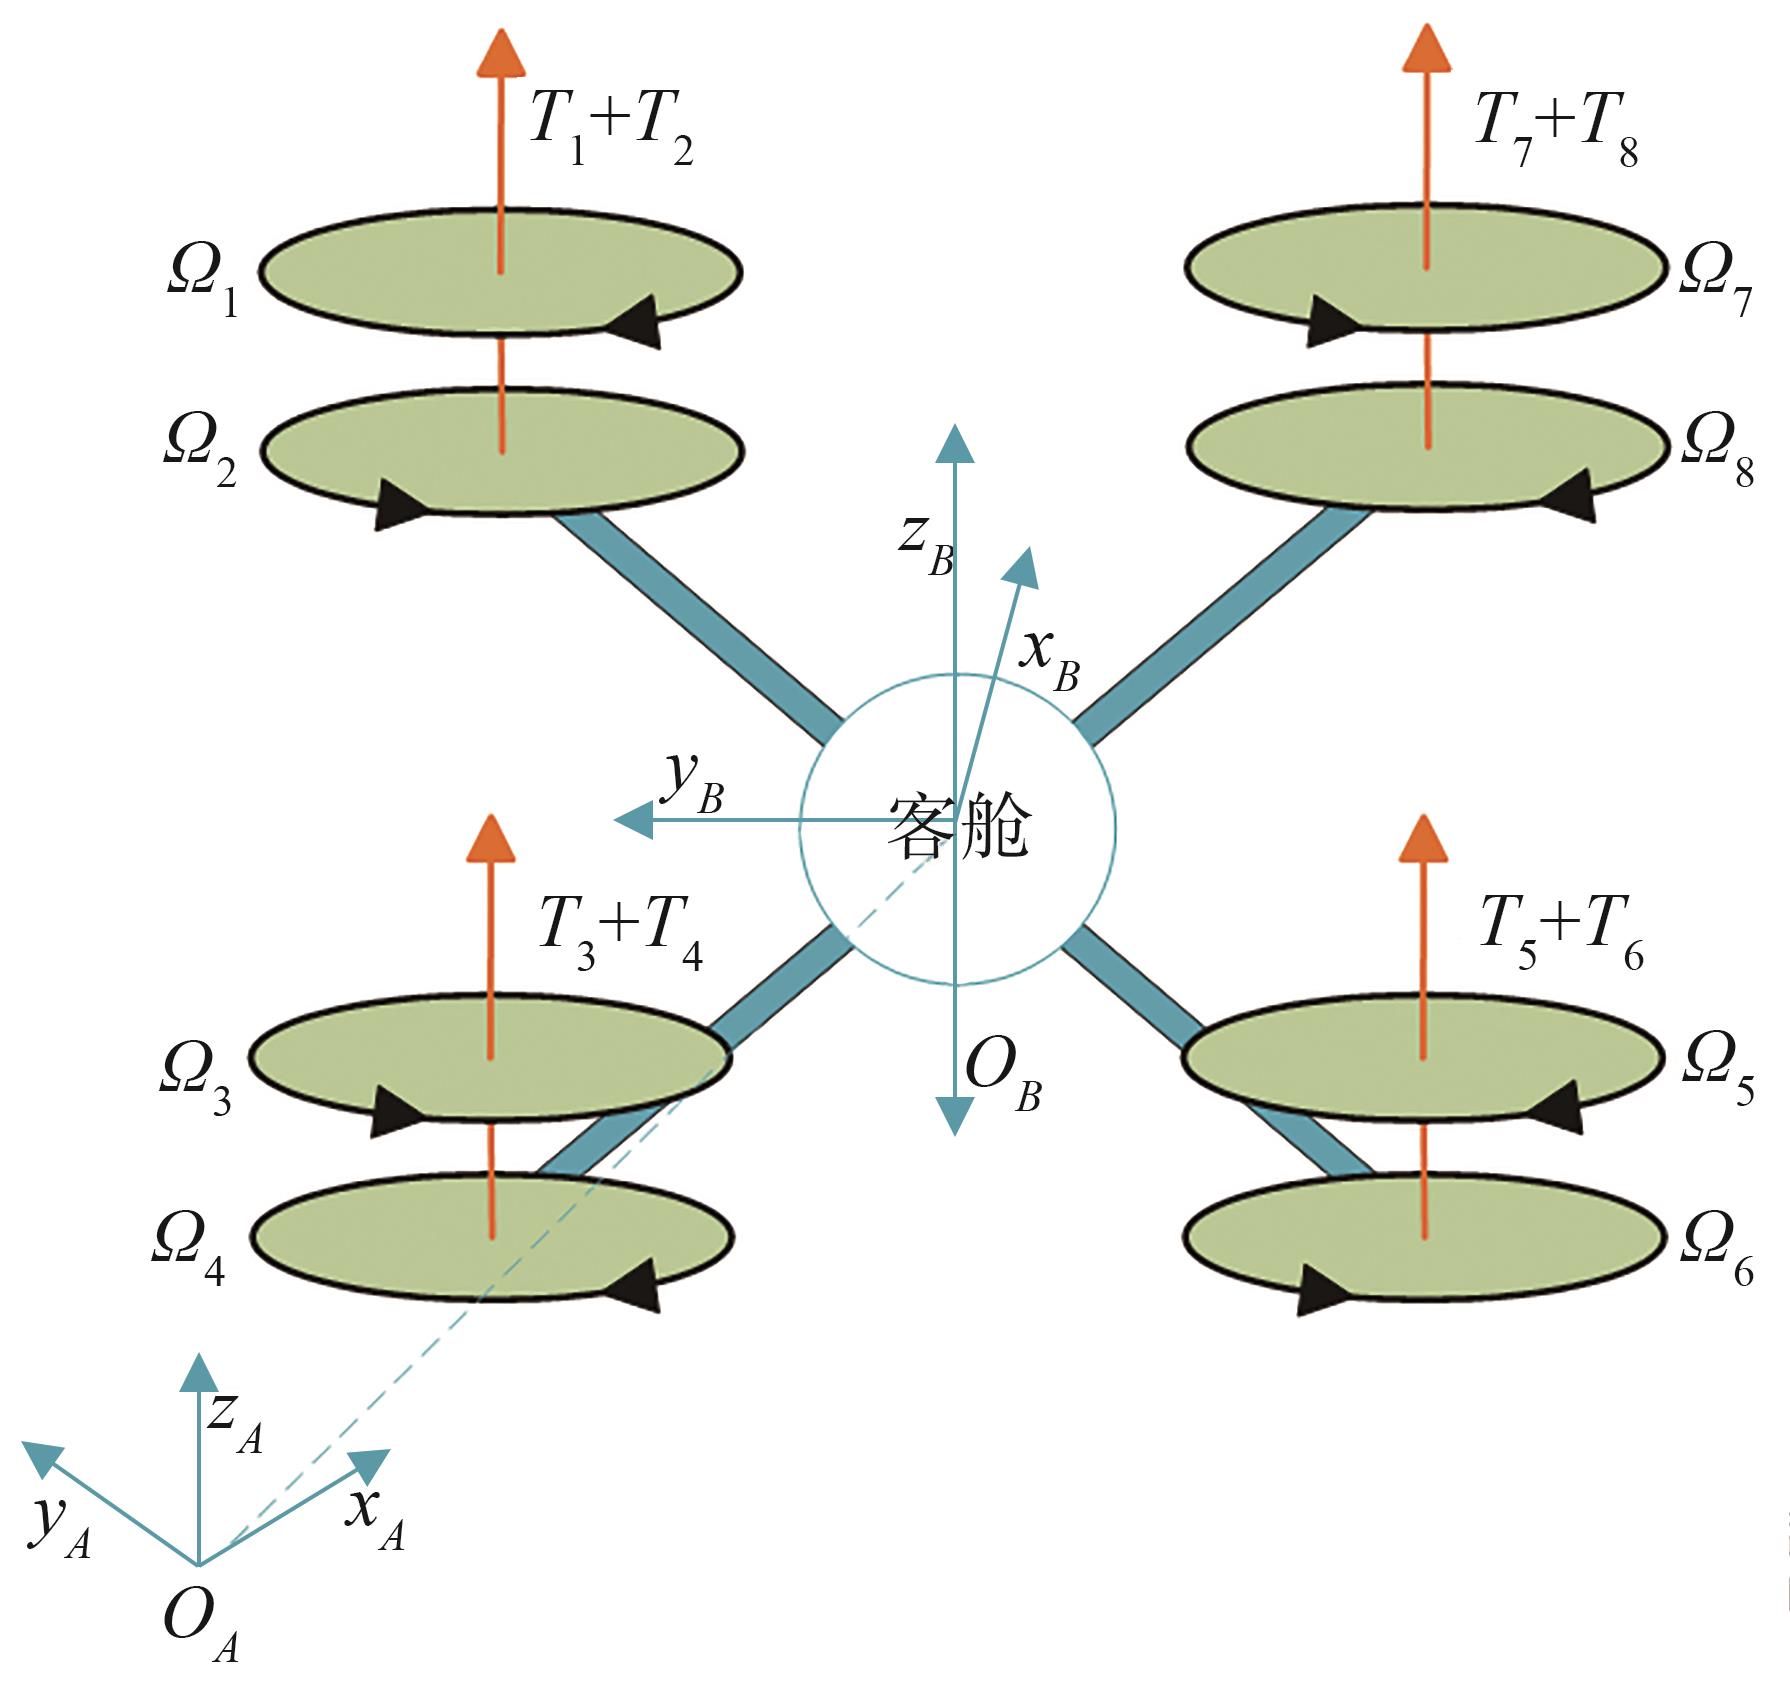
Fig. 2
Control structure of fault-tolerant controller for coaxial octocopter eVTOL
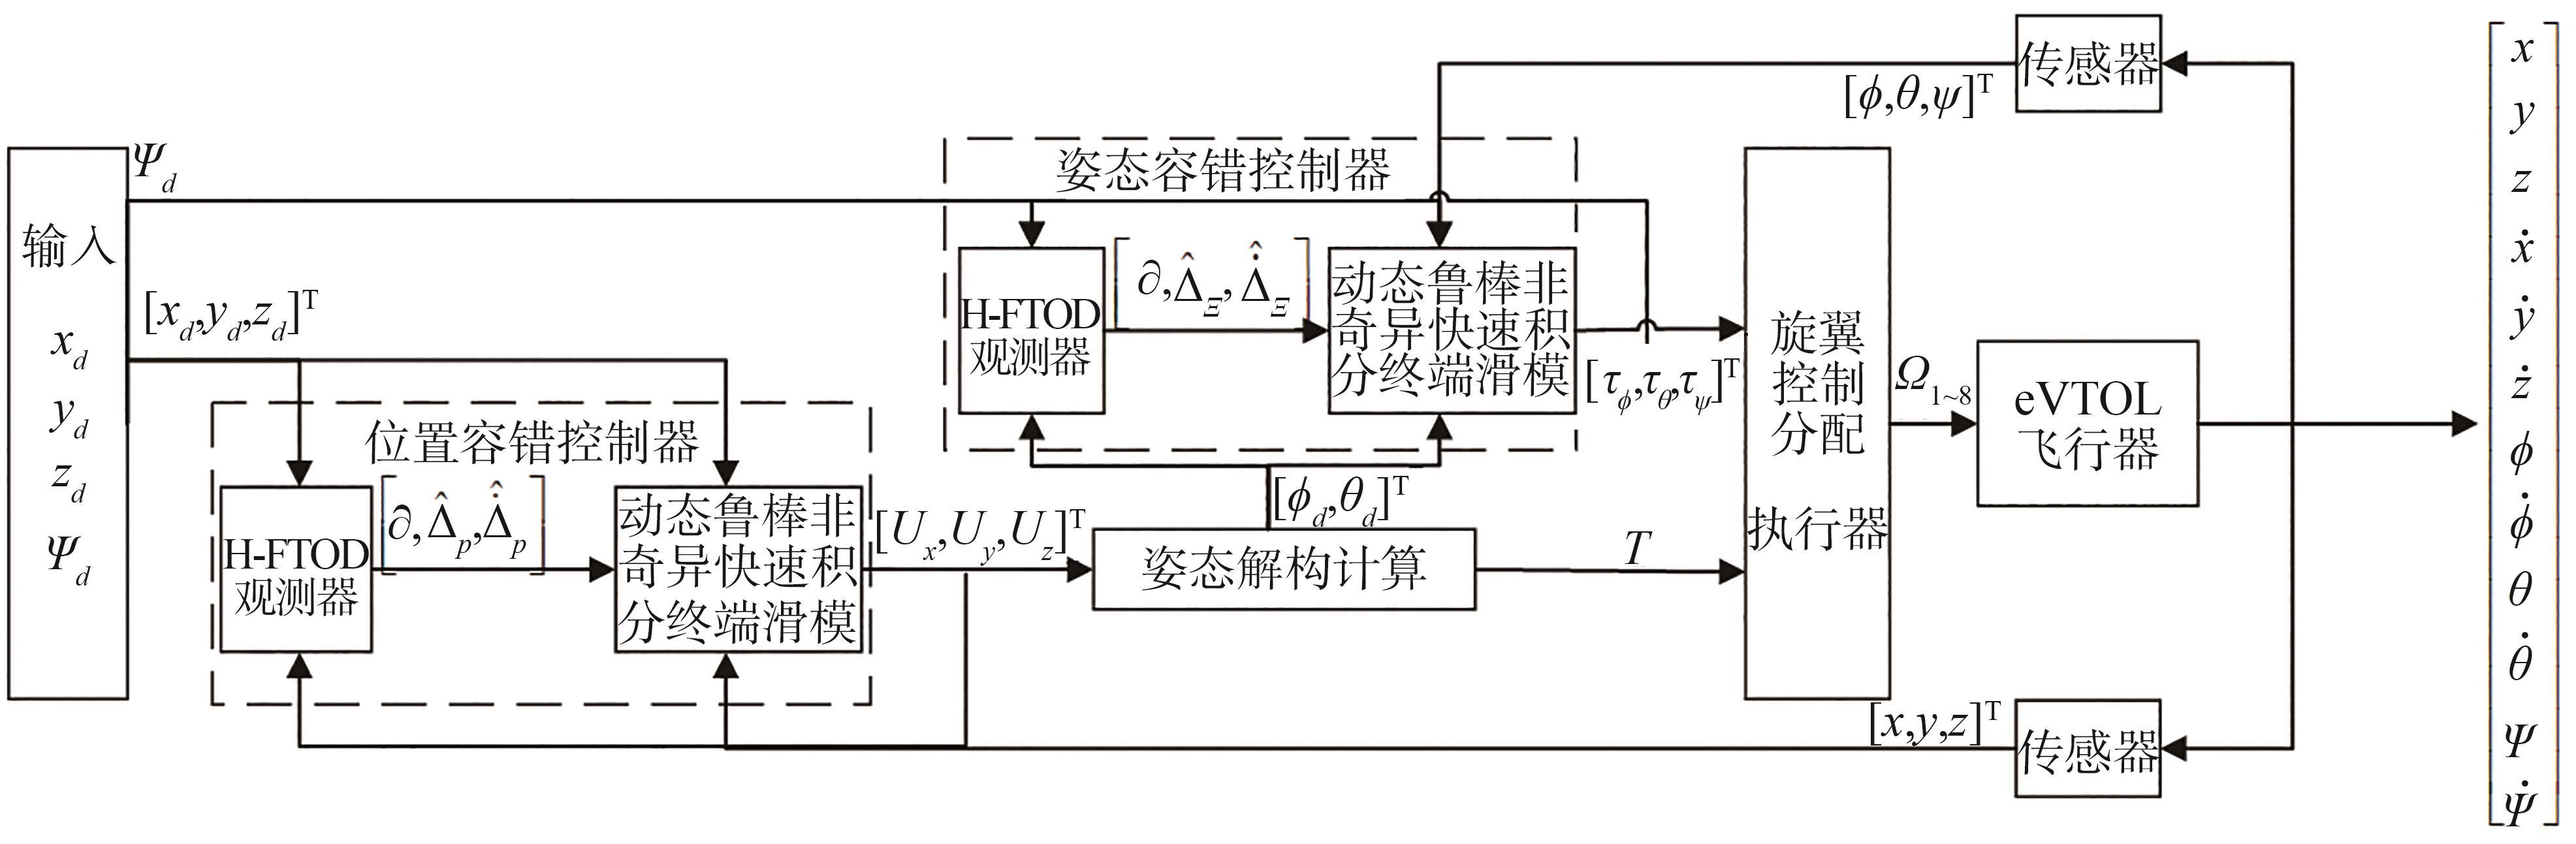
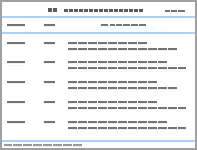
Table 1
Summary of basic parameters of eVTOL model
| 符号 | 参数 |
|---|---|
| 220 | |
| 1.65 | |
| 0.6 | |
| 0.018 5 | |
| 164 | |
| 281 | |
| 1.13 | |
| 0.011 6 |
Table 2
Parameters of controller and observer
| 符号 | 参数 | 符号 | 参数 |
|---|---|---|---|
| 210 | 10 | ||
| 150 | 10 | ||
| 80 | 40 | ||
| 30 | 20 | ||
| 0.01 | 0.01 | ||
| 20 |
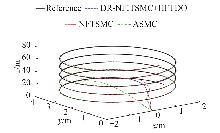
Fig. 3
Single-rotor fault experiment: three-dimensional tracking
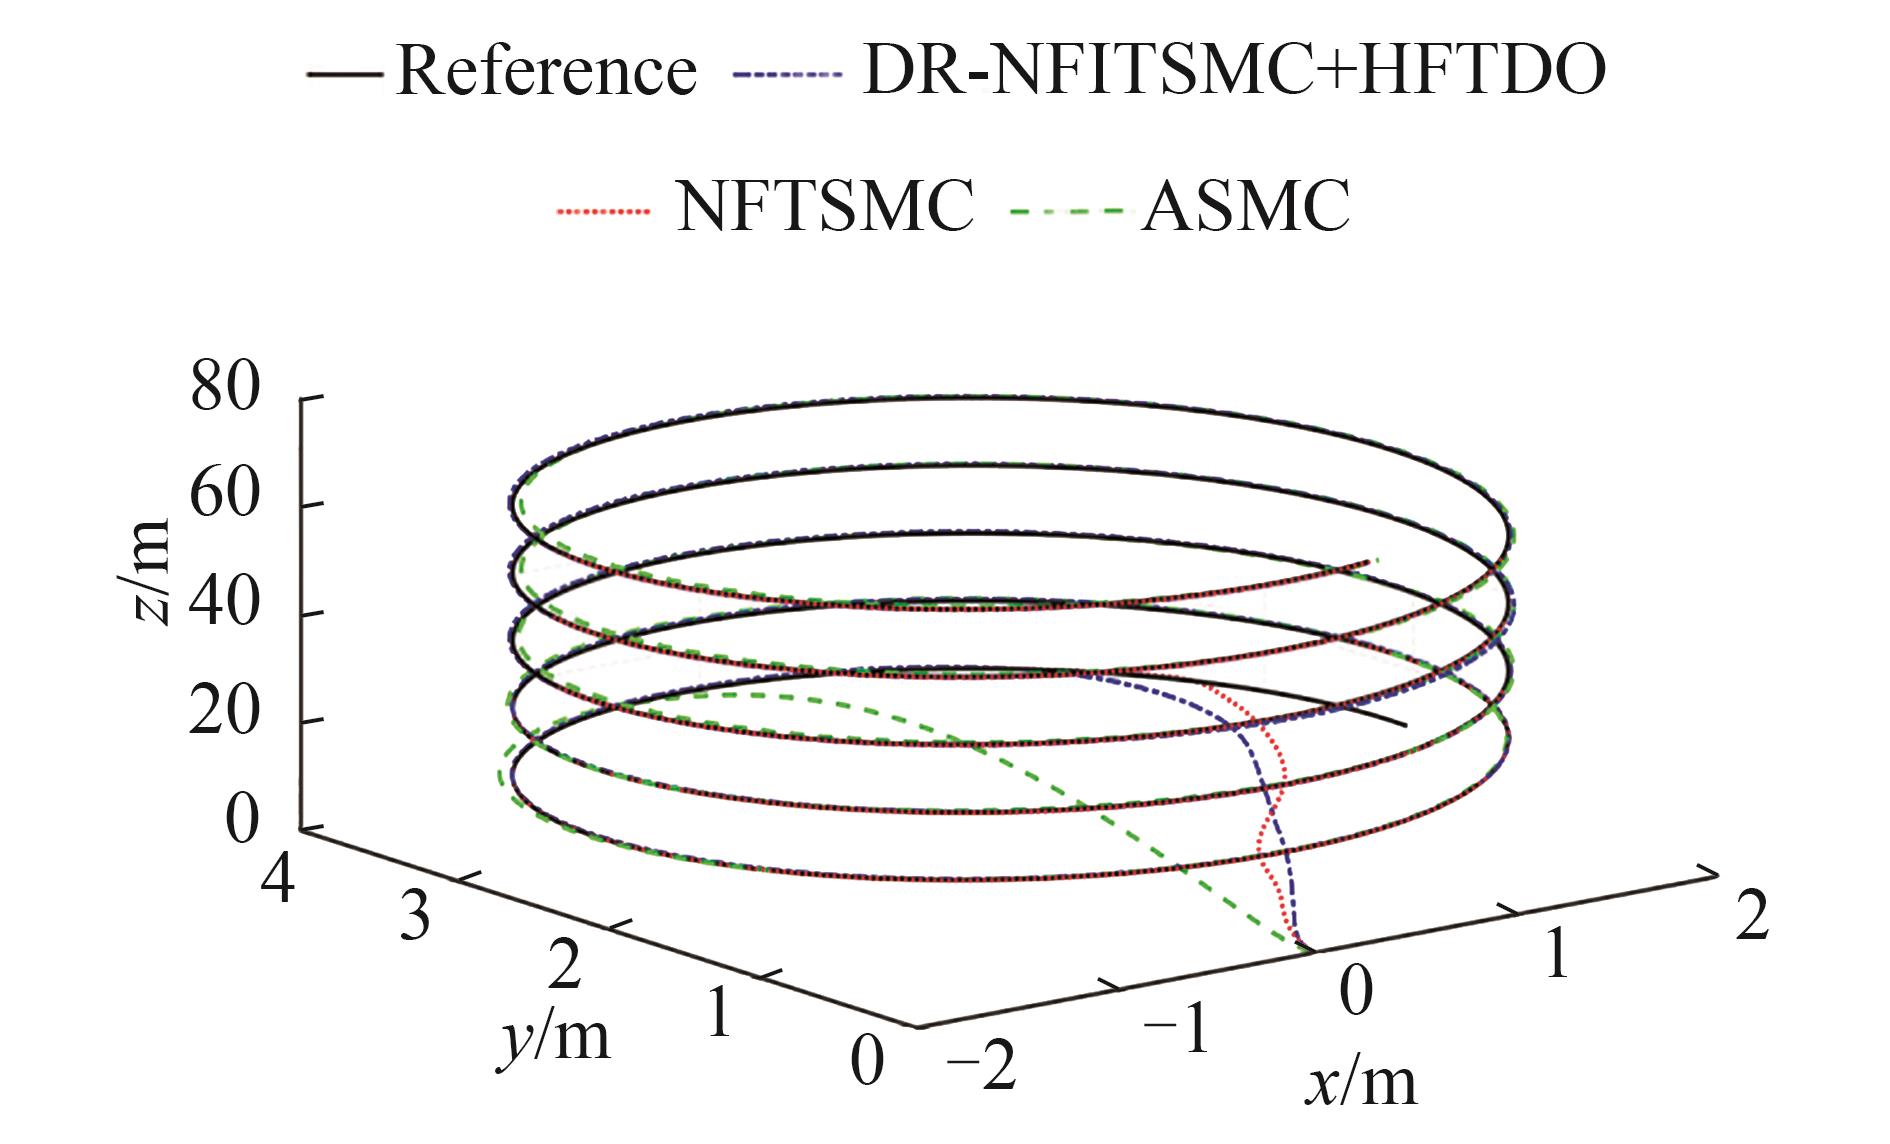
Fig. 4
Single-rotor fault experiment: position tracking
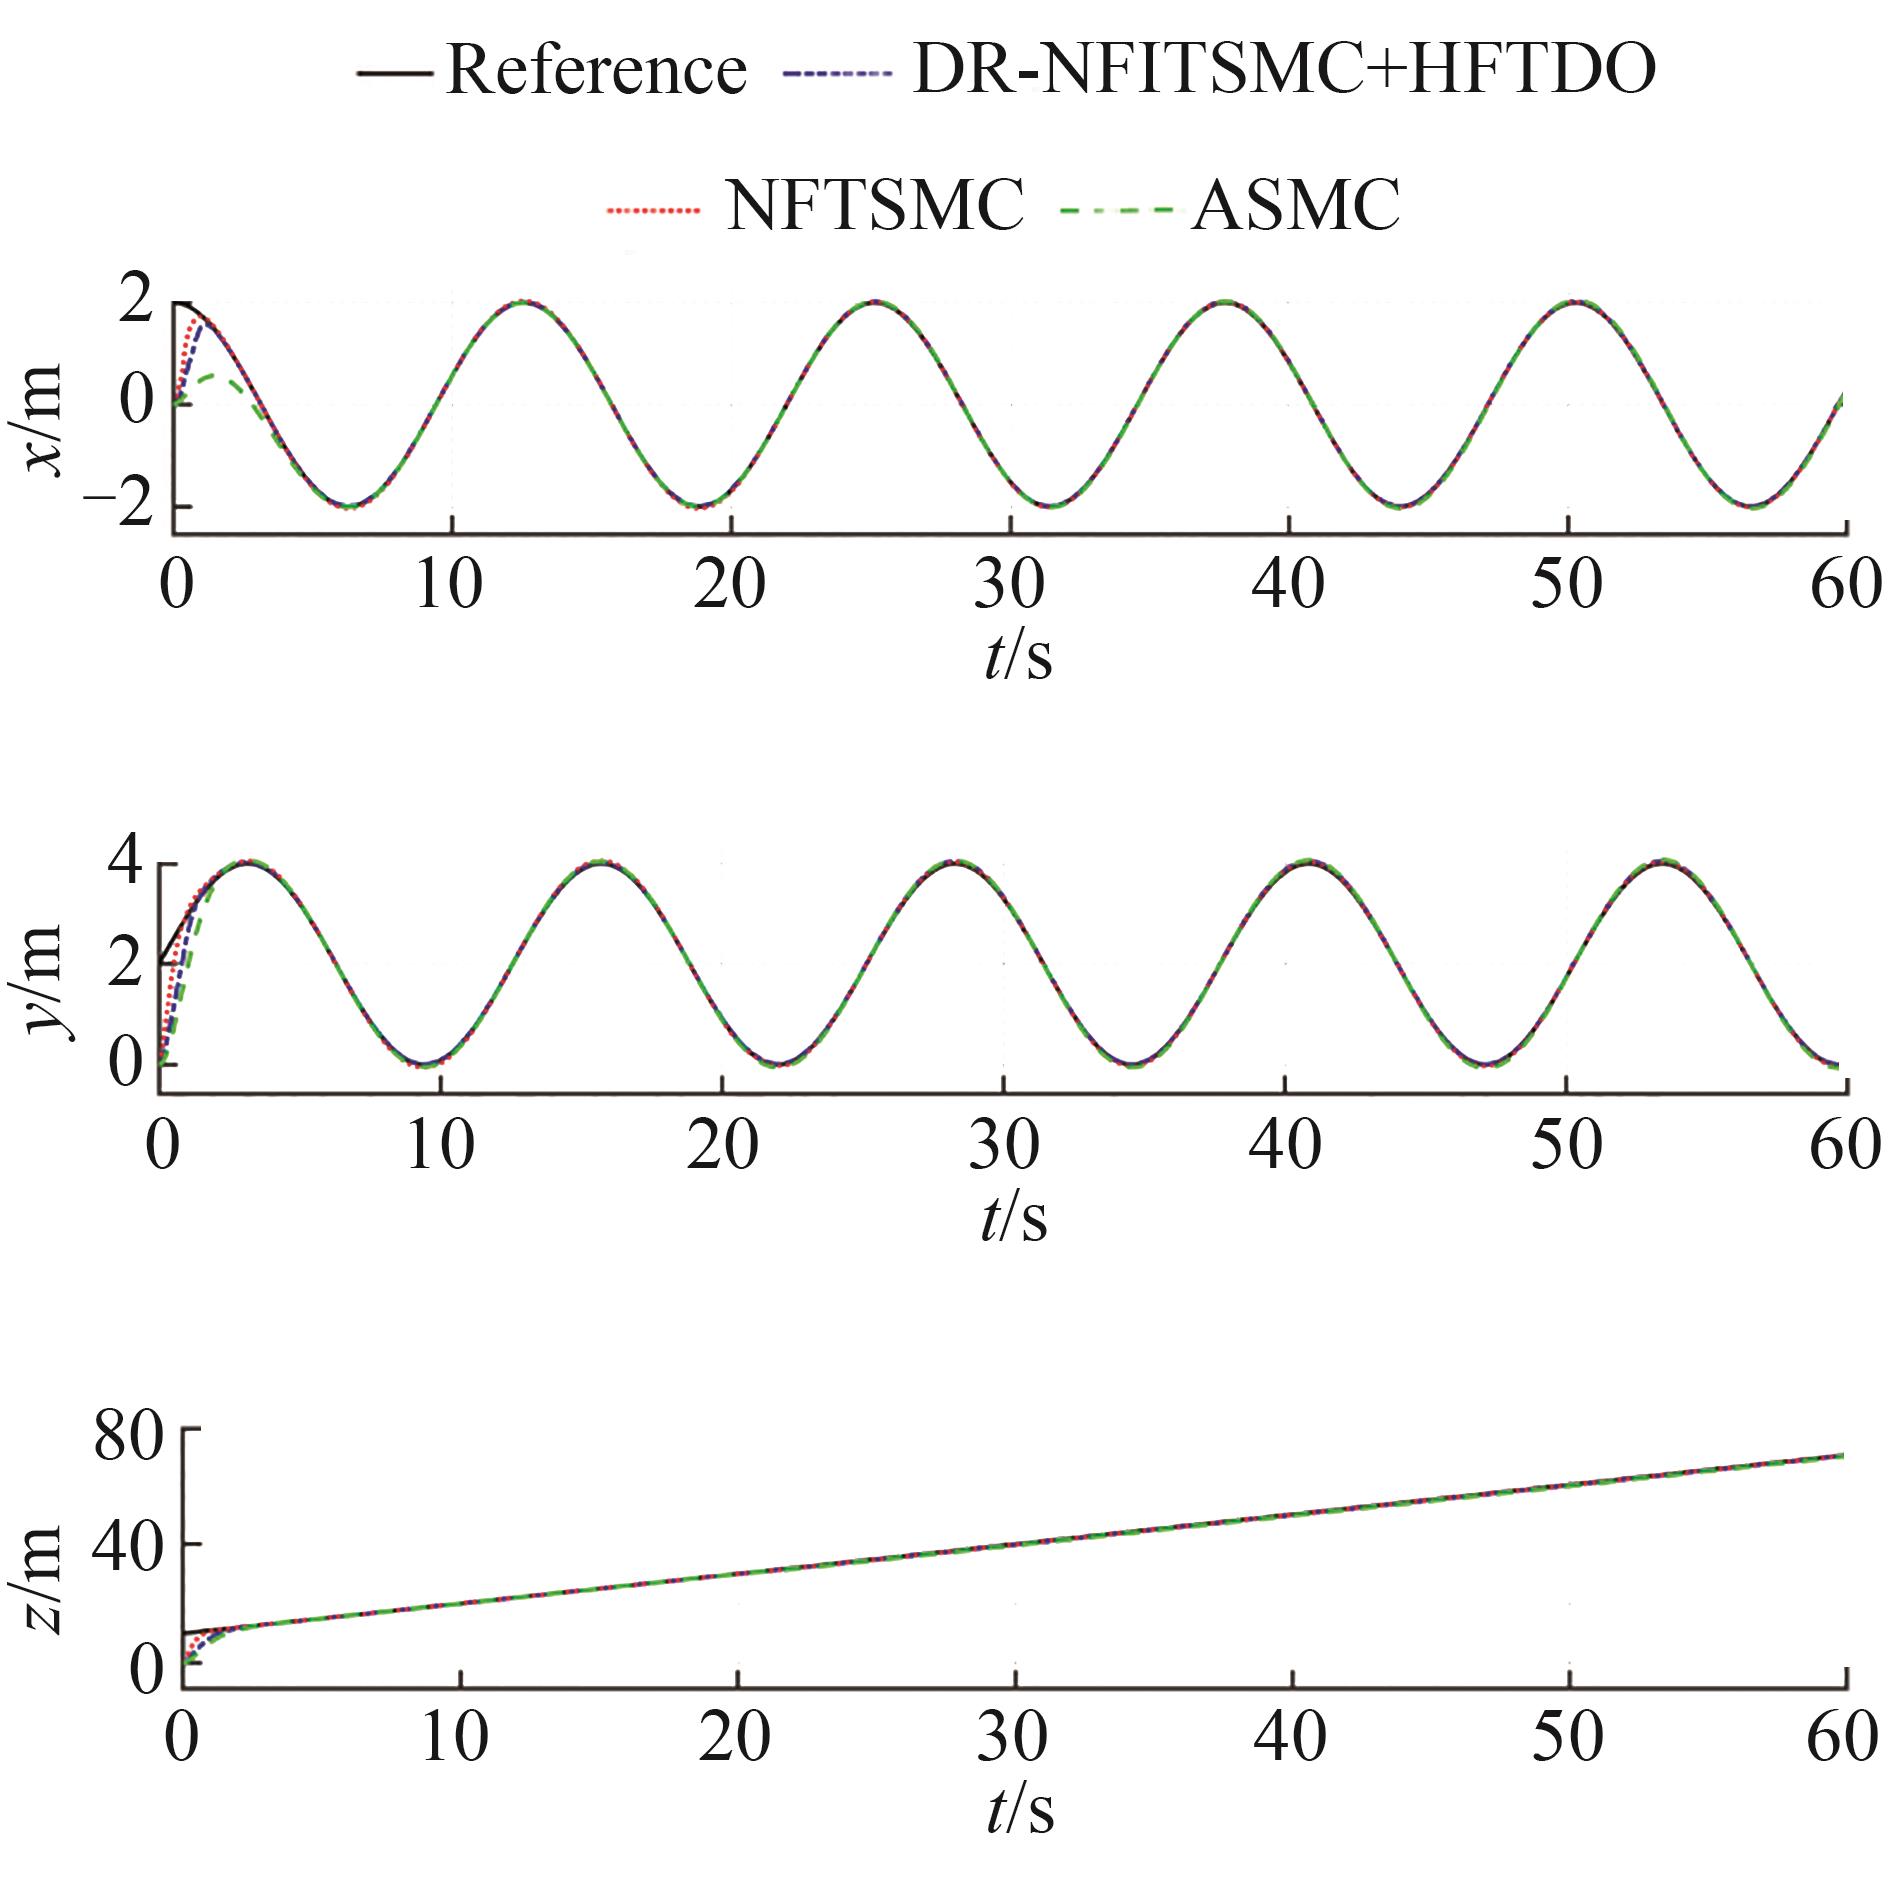
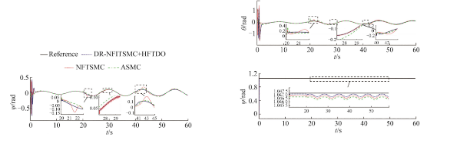
Fig. 5
Single-rotor fault experiment: attitude tracking
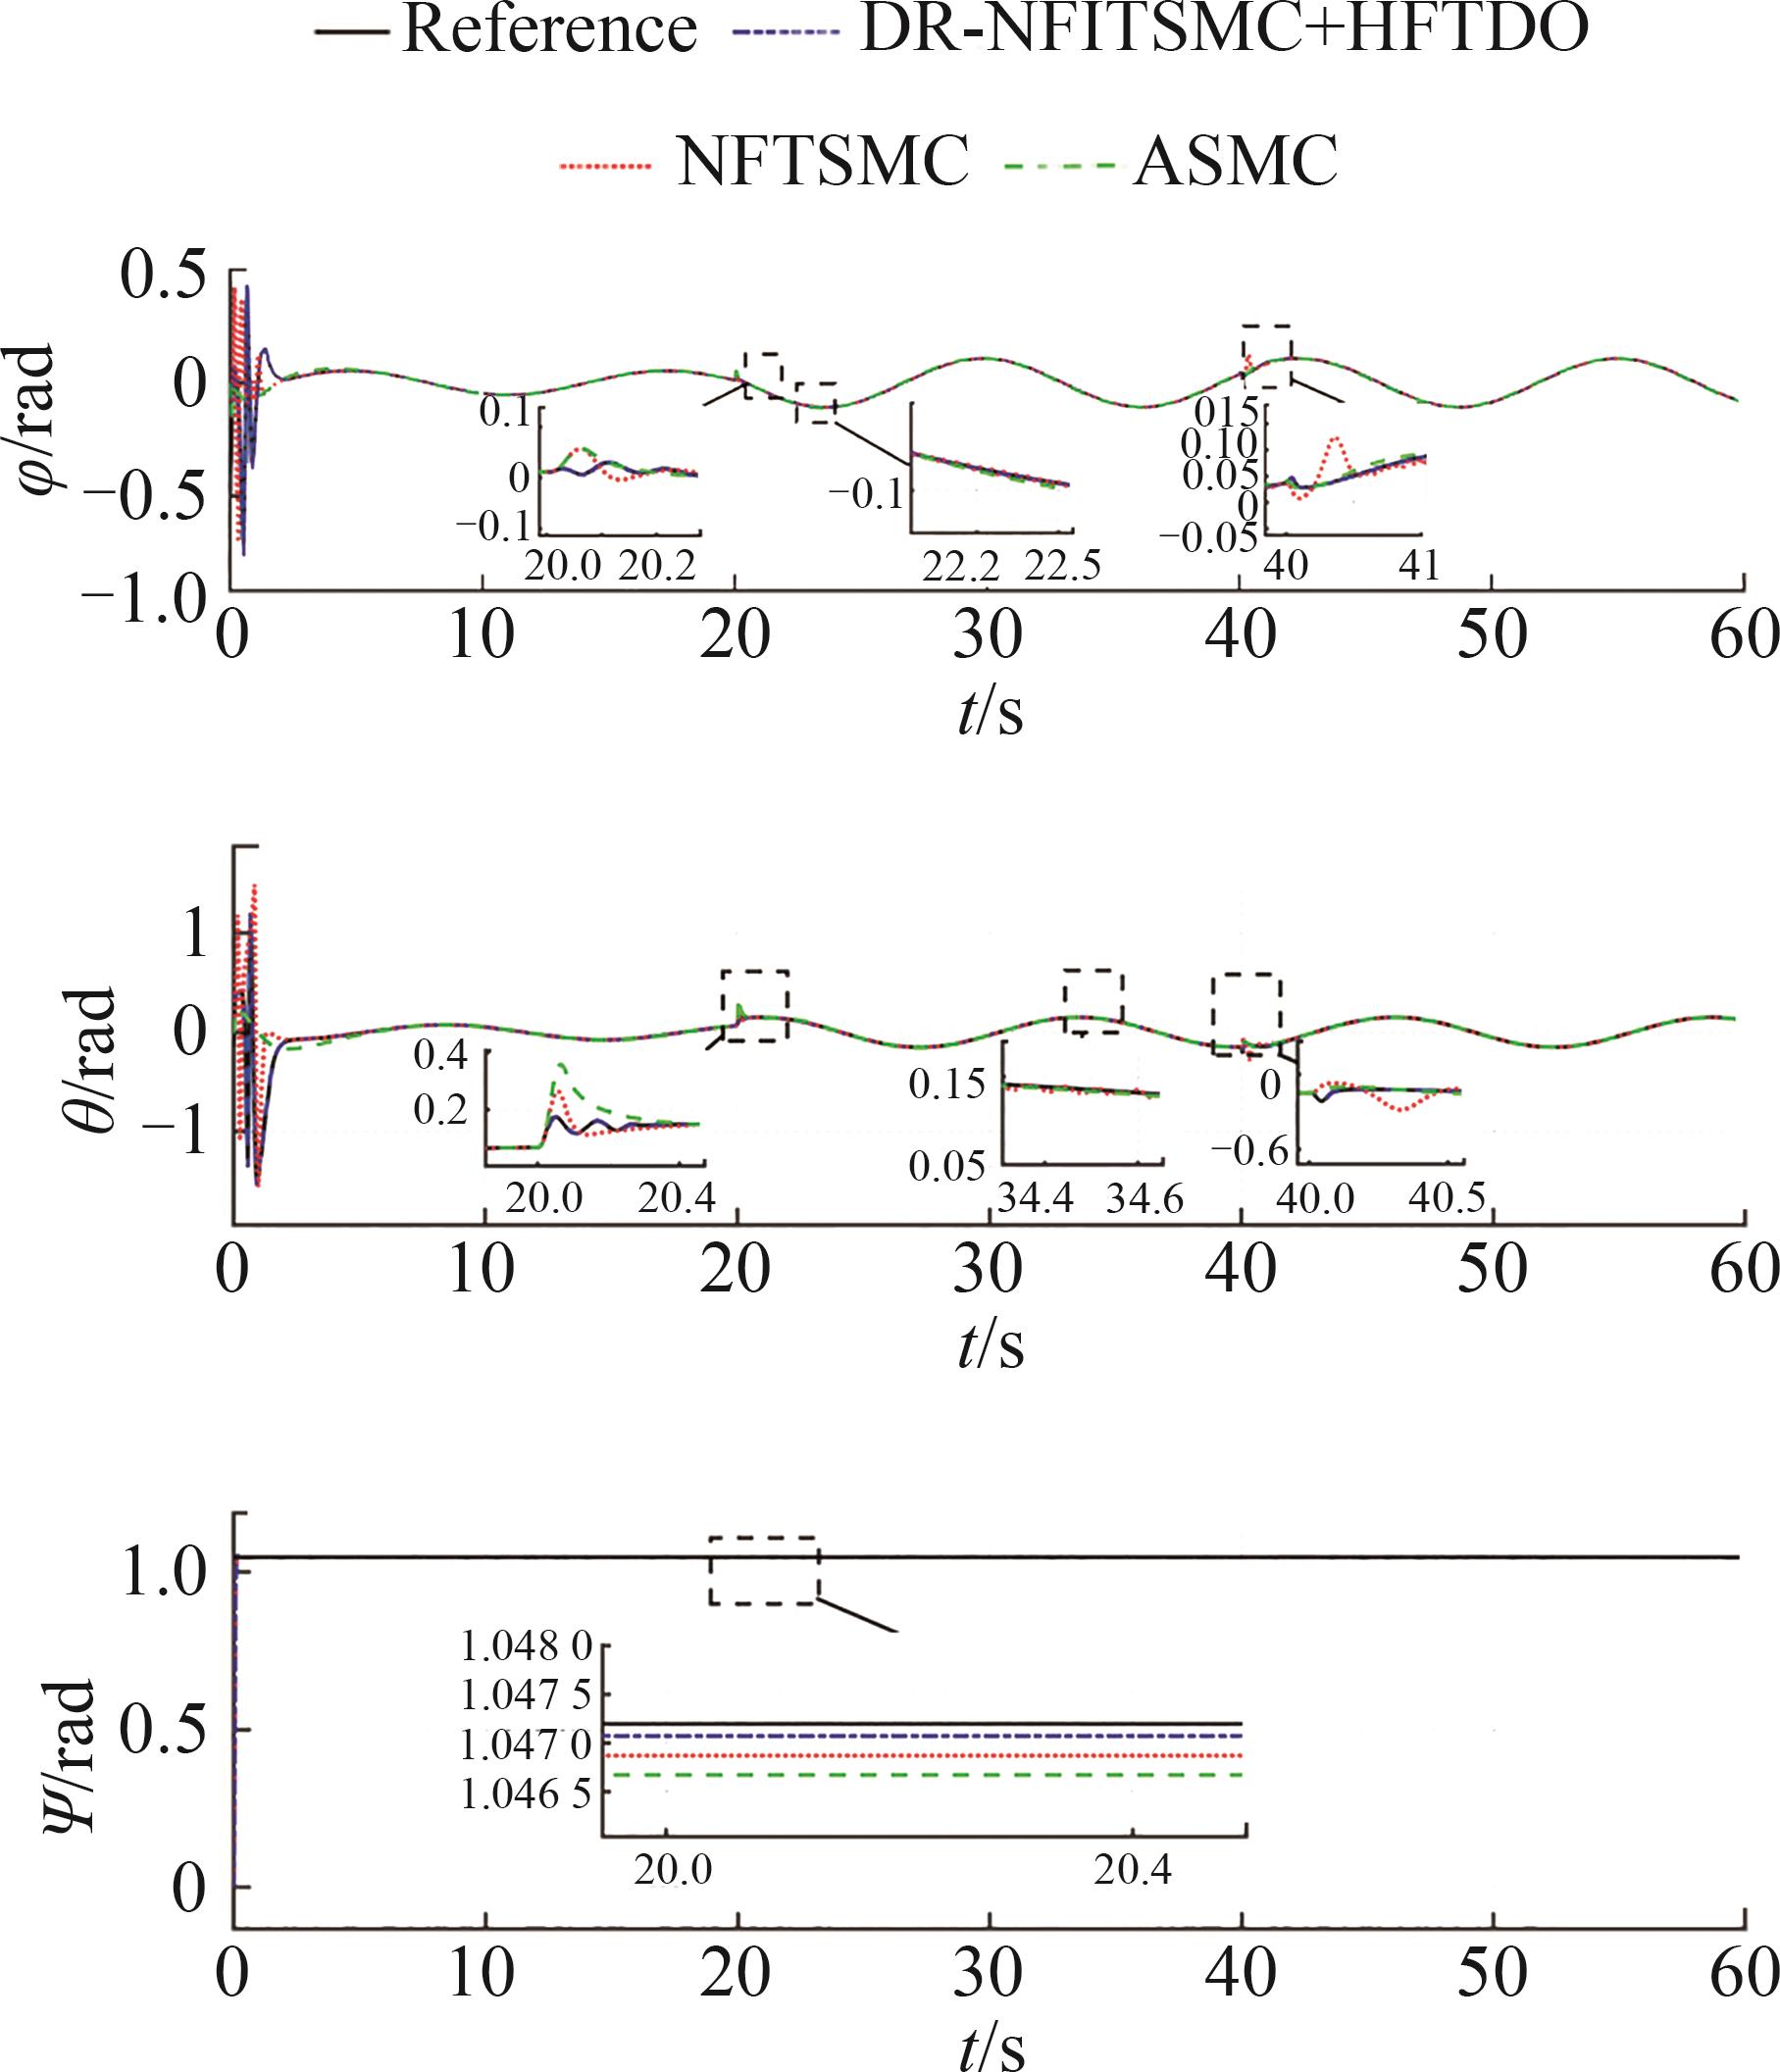
Fig. 6
Single-rotor fault experiment: position disturbance observation
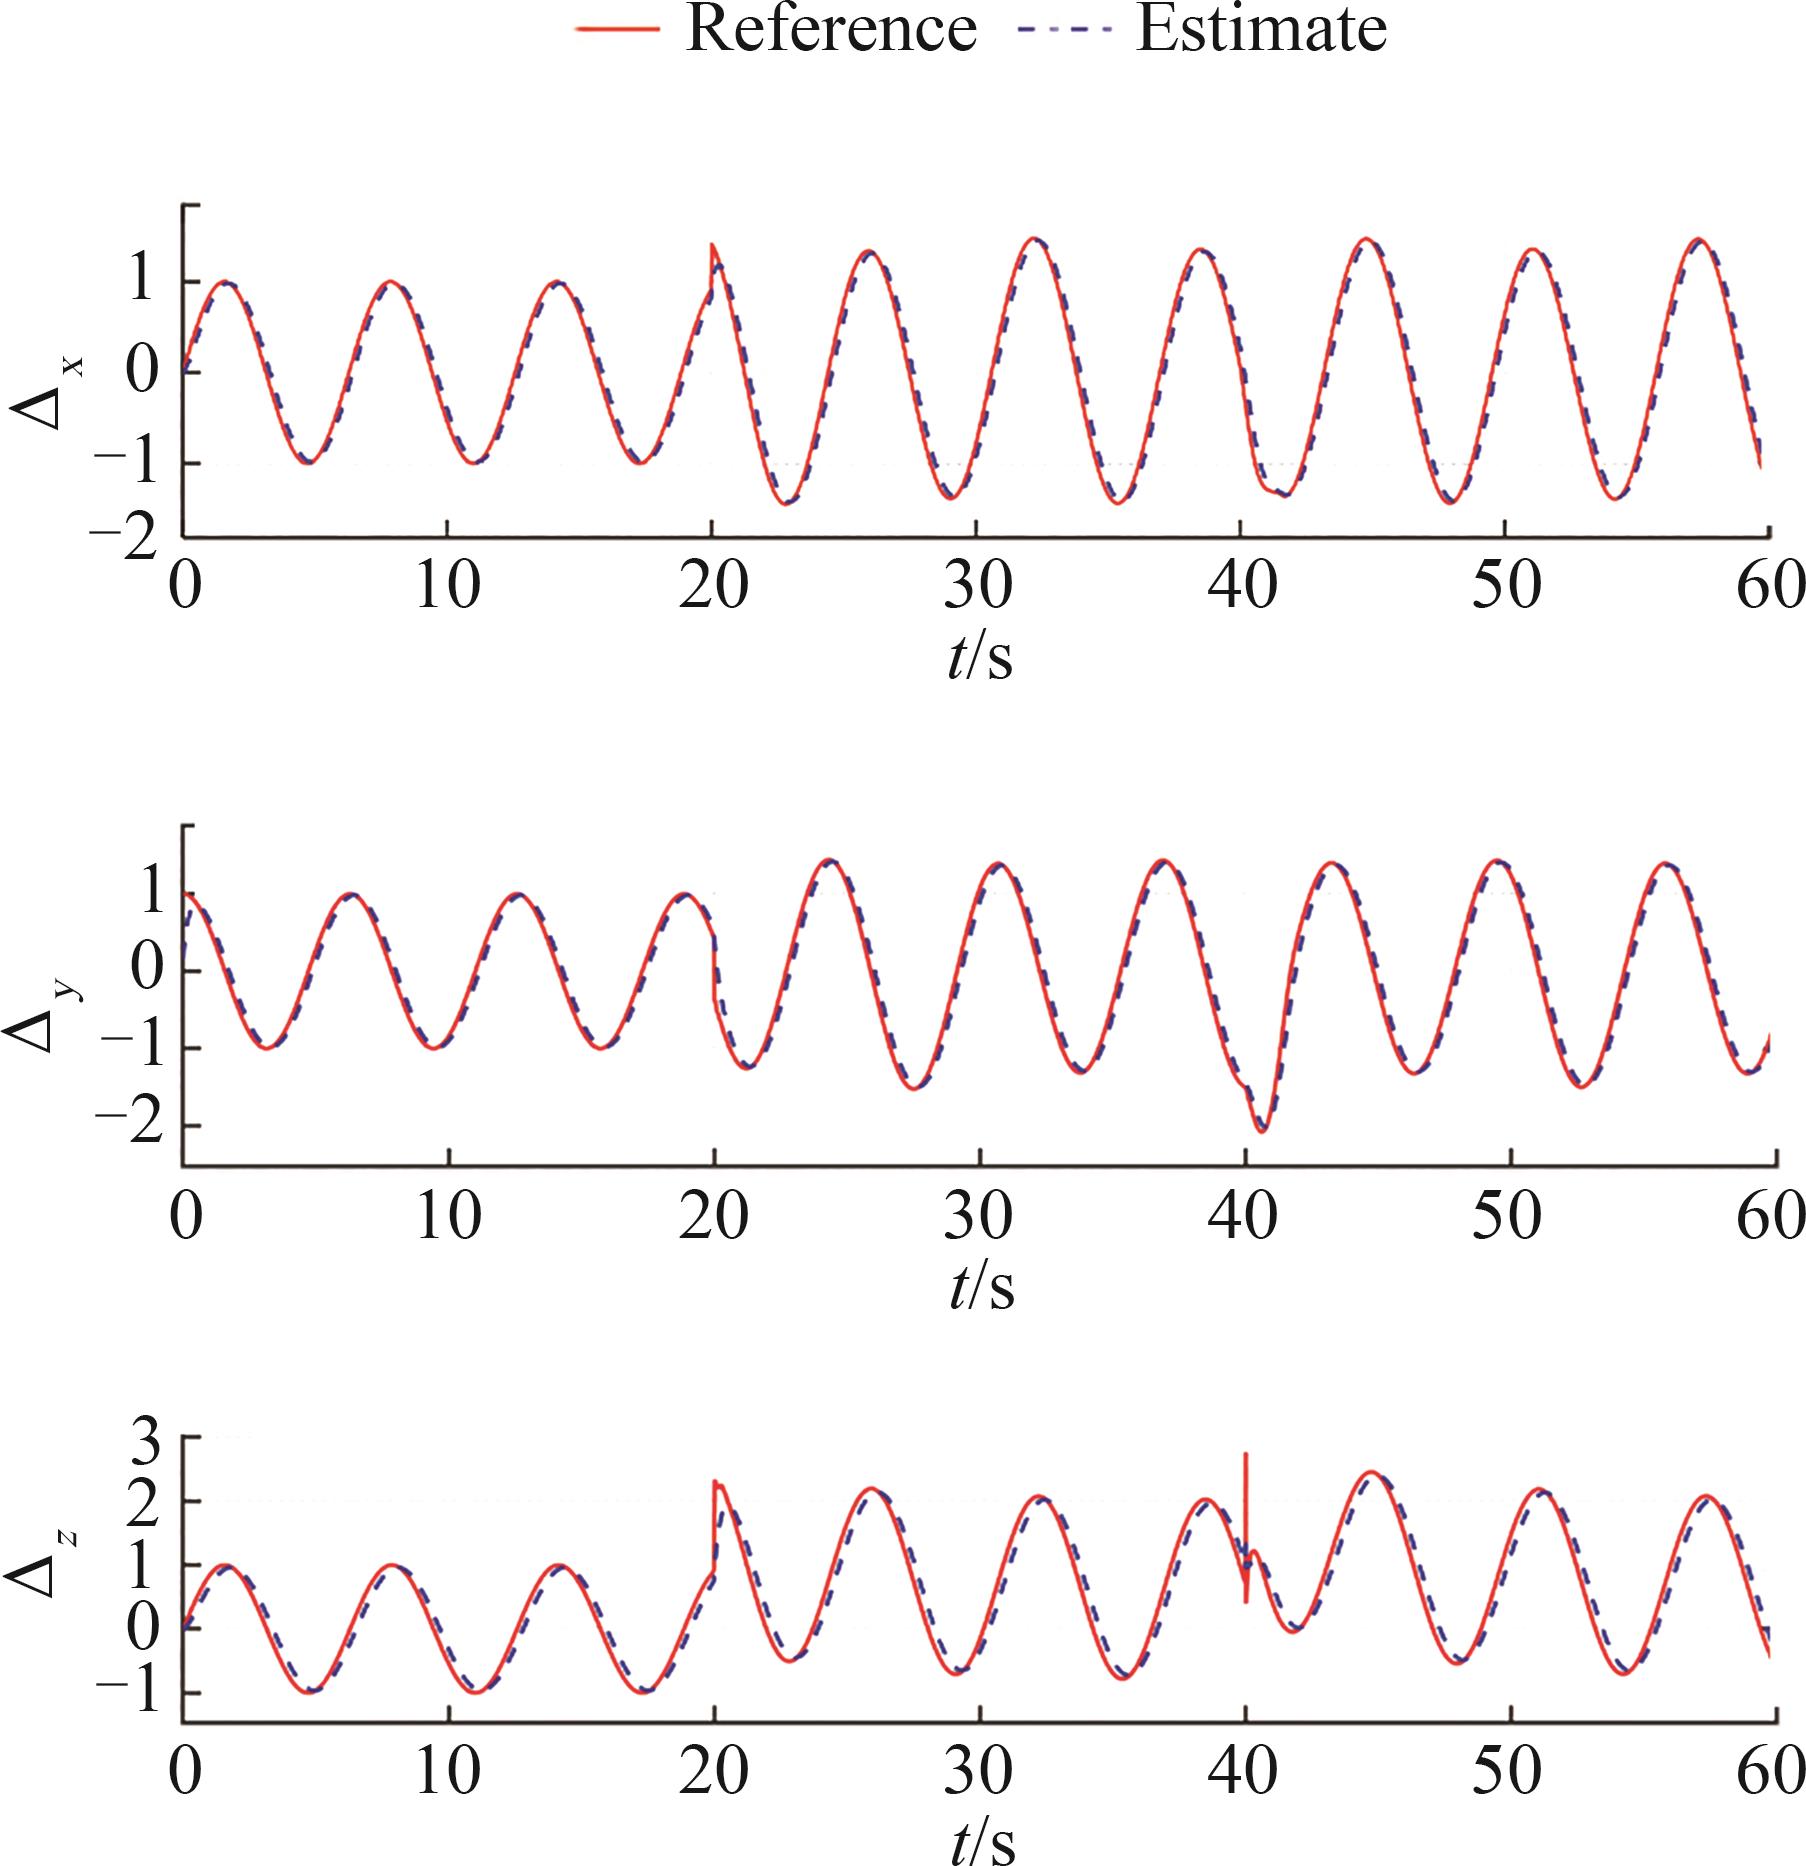
Fig. 7
Single-rotor fault experiment: attitude disturbance observation
Fig. 8
Opposite-side multi-rotor fault experiment: position tracking
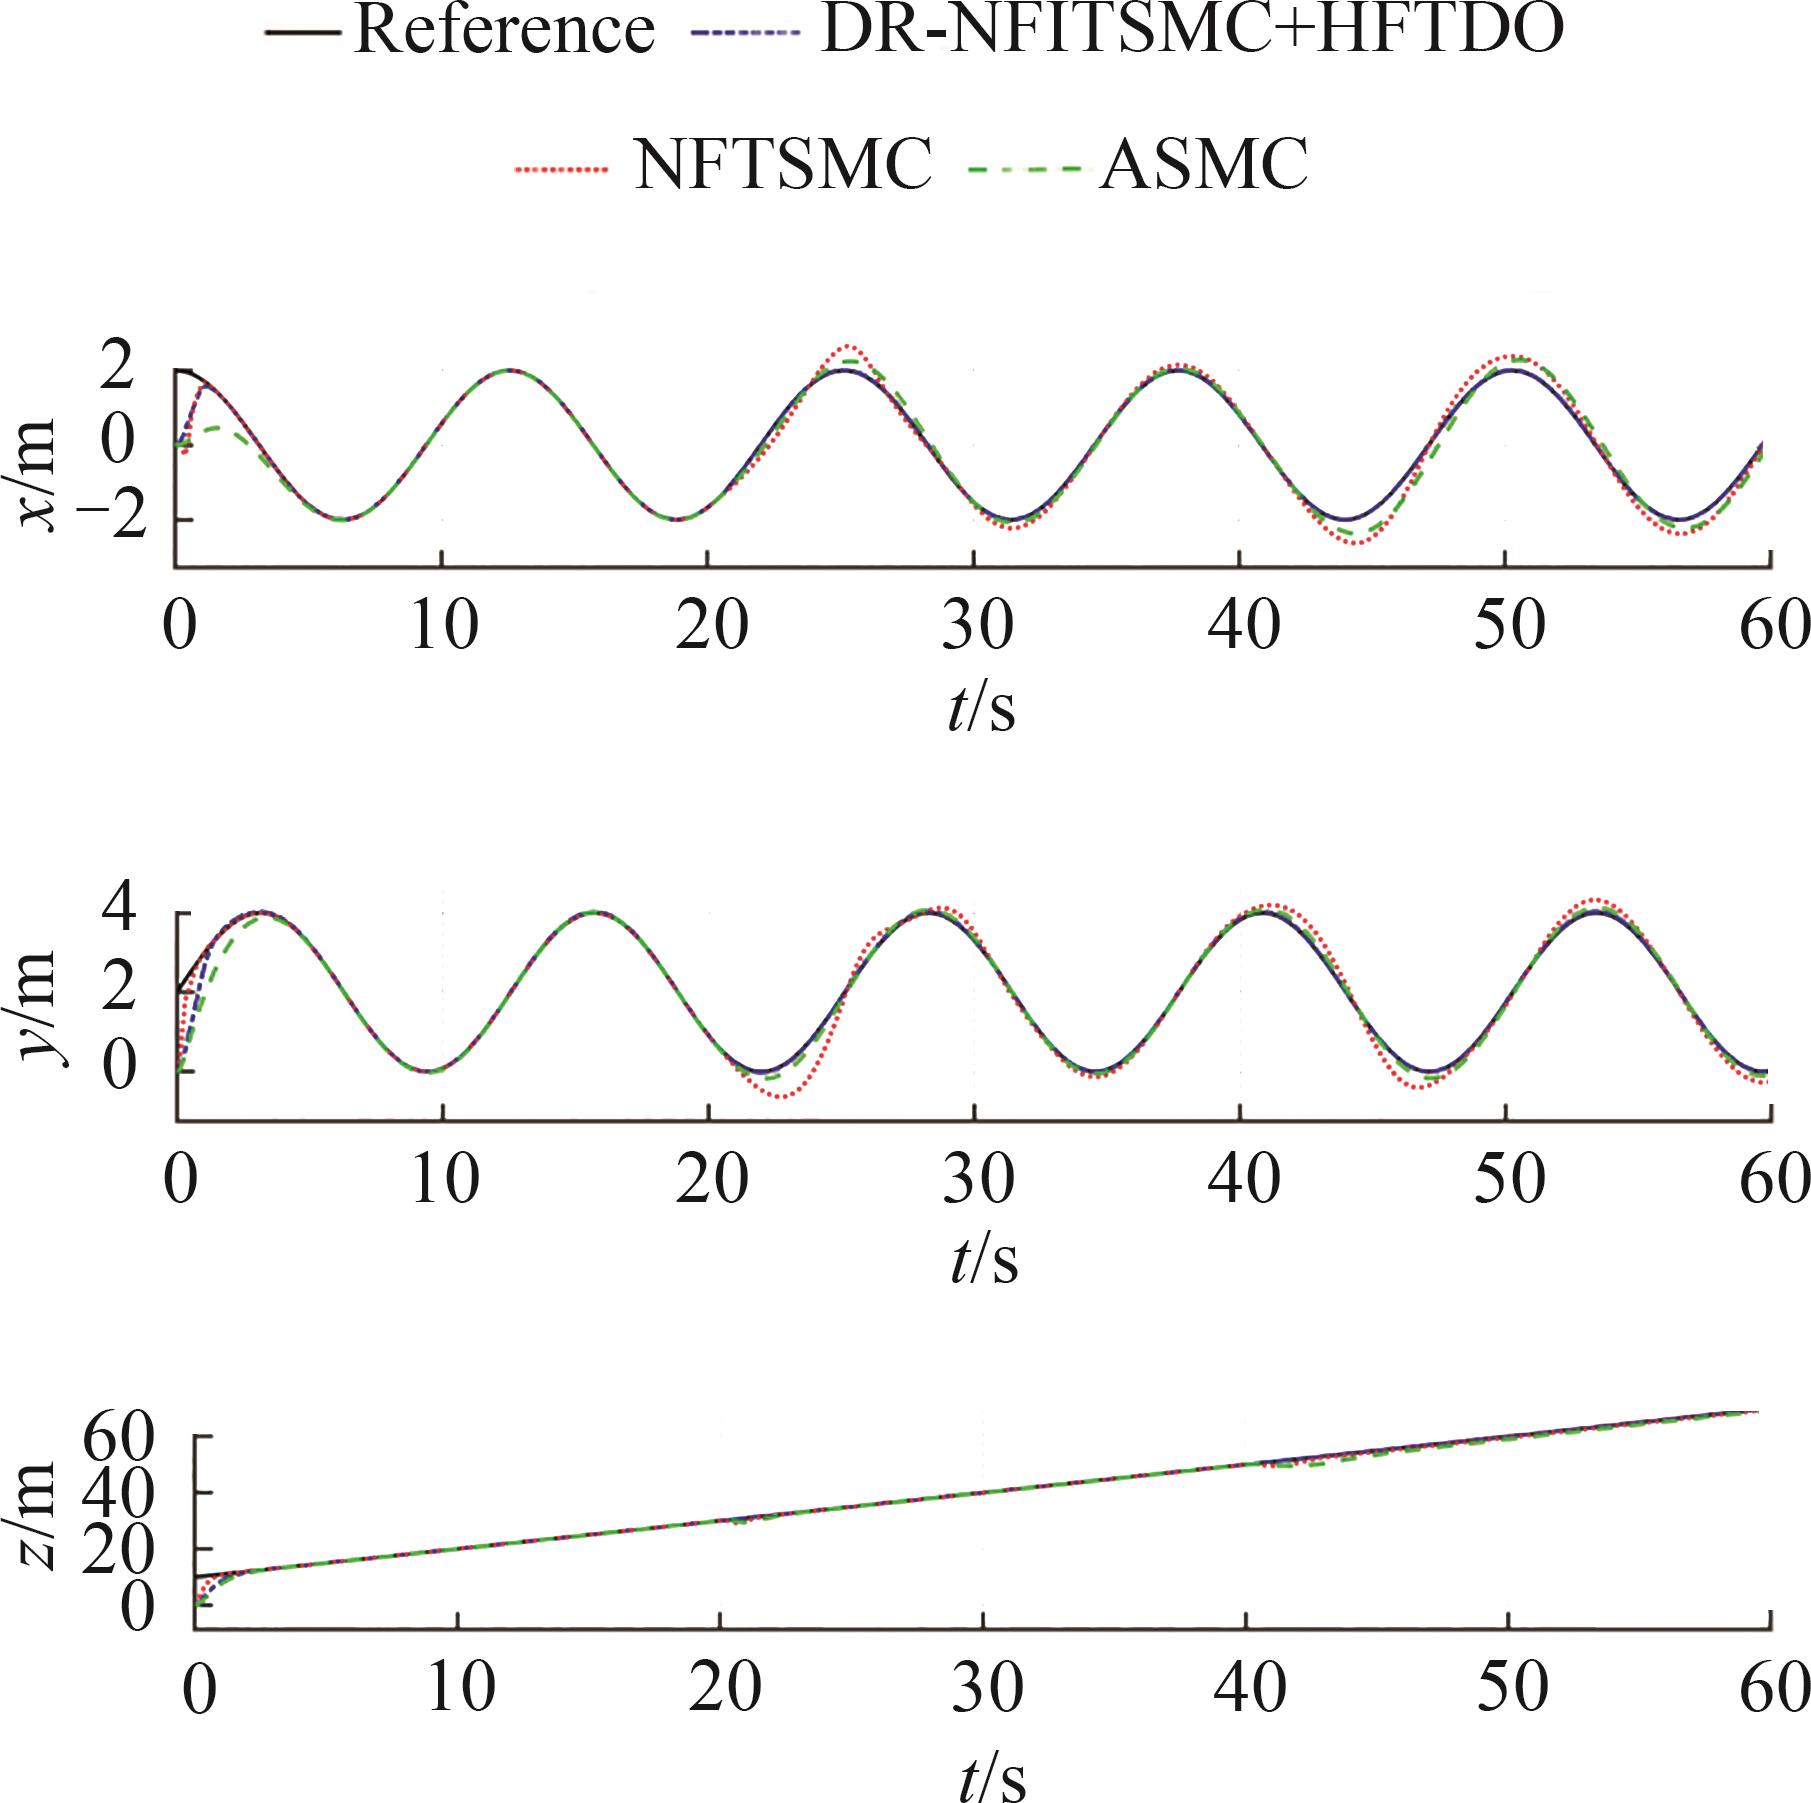
Fig. 9
Opposite-side multi-rotor fault experiment: position error
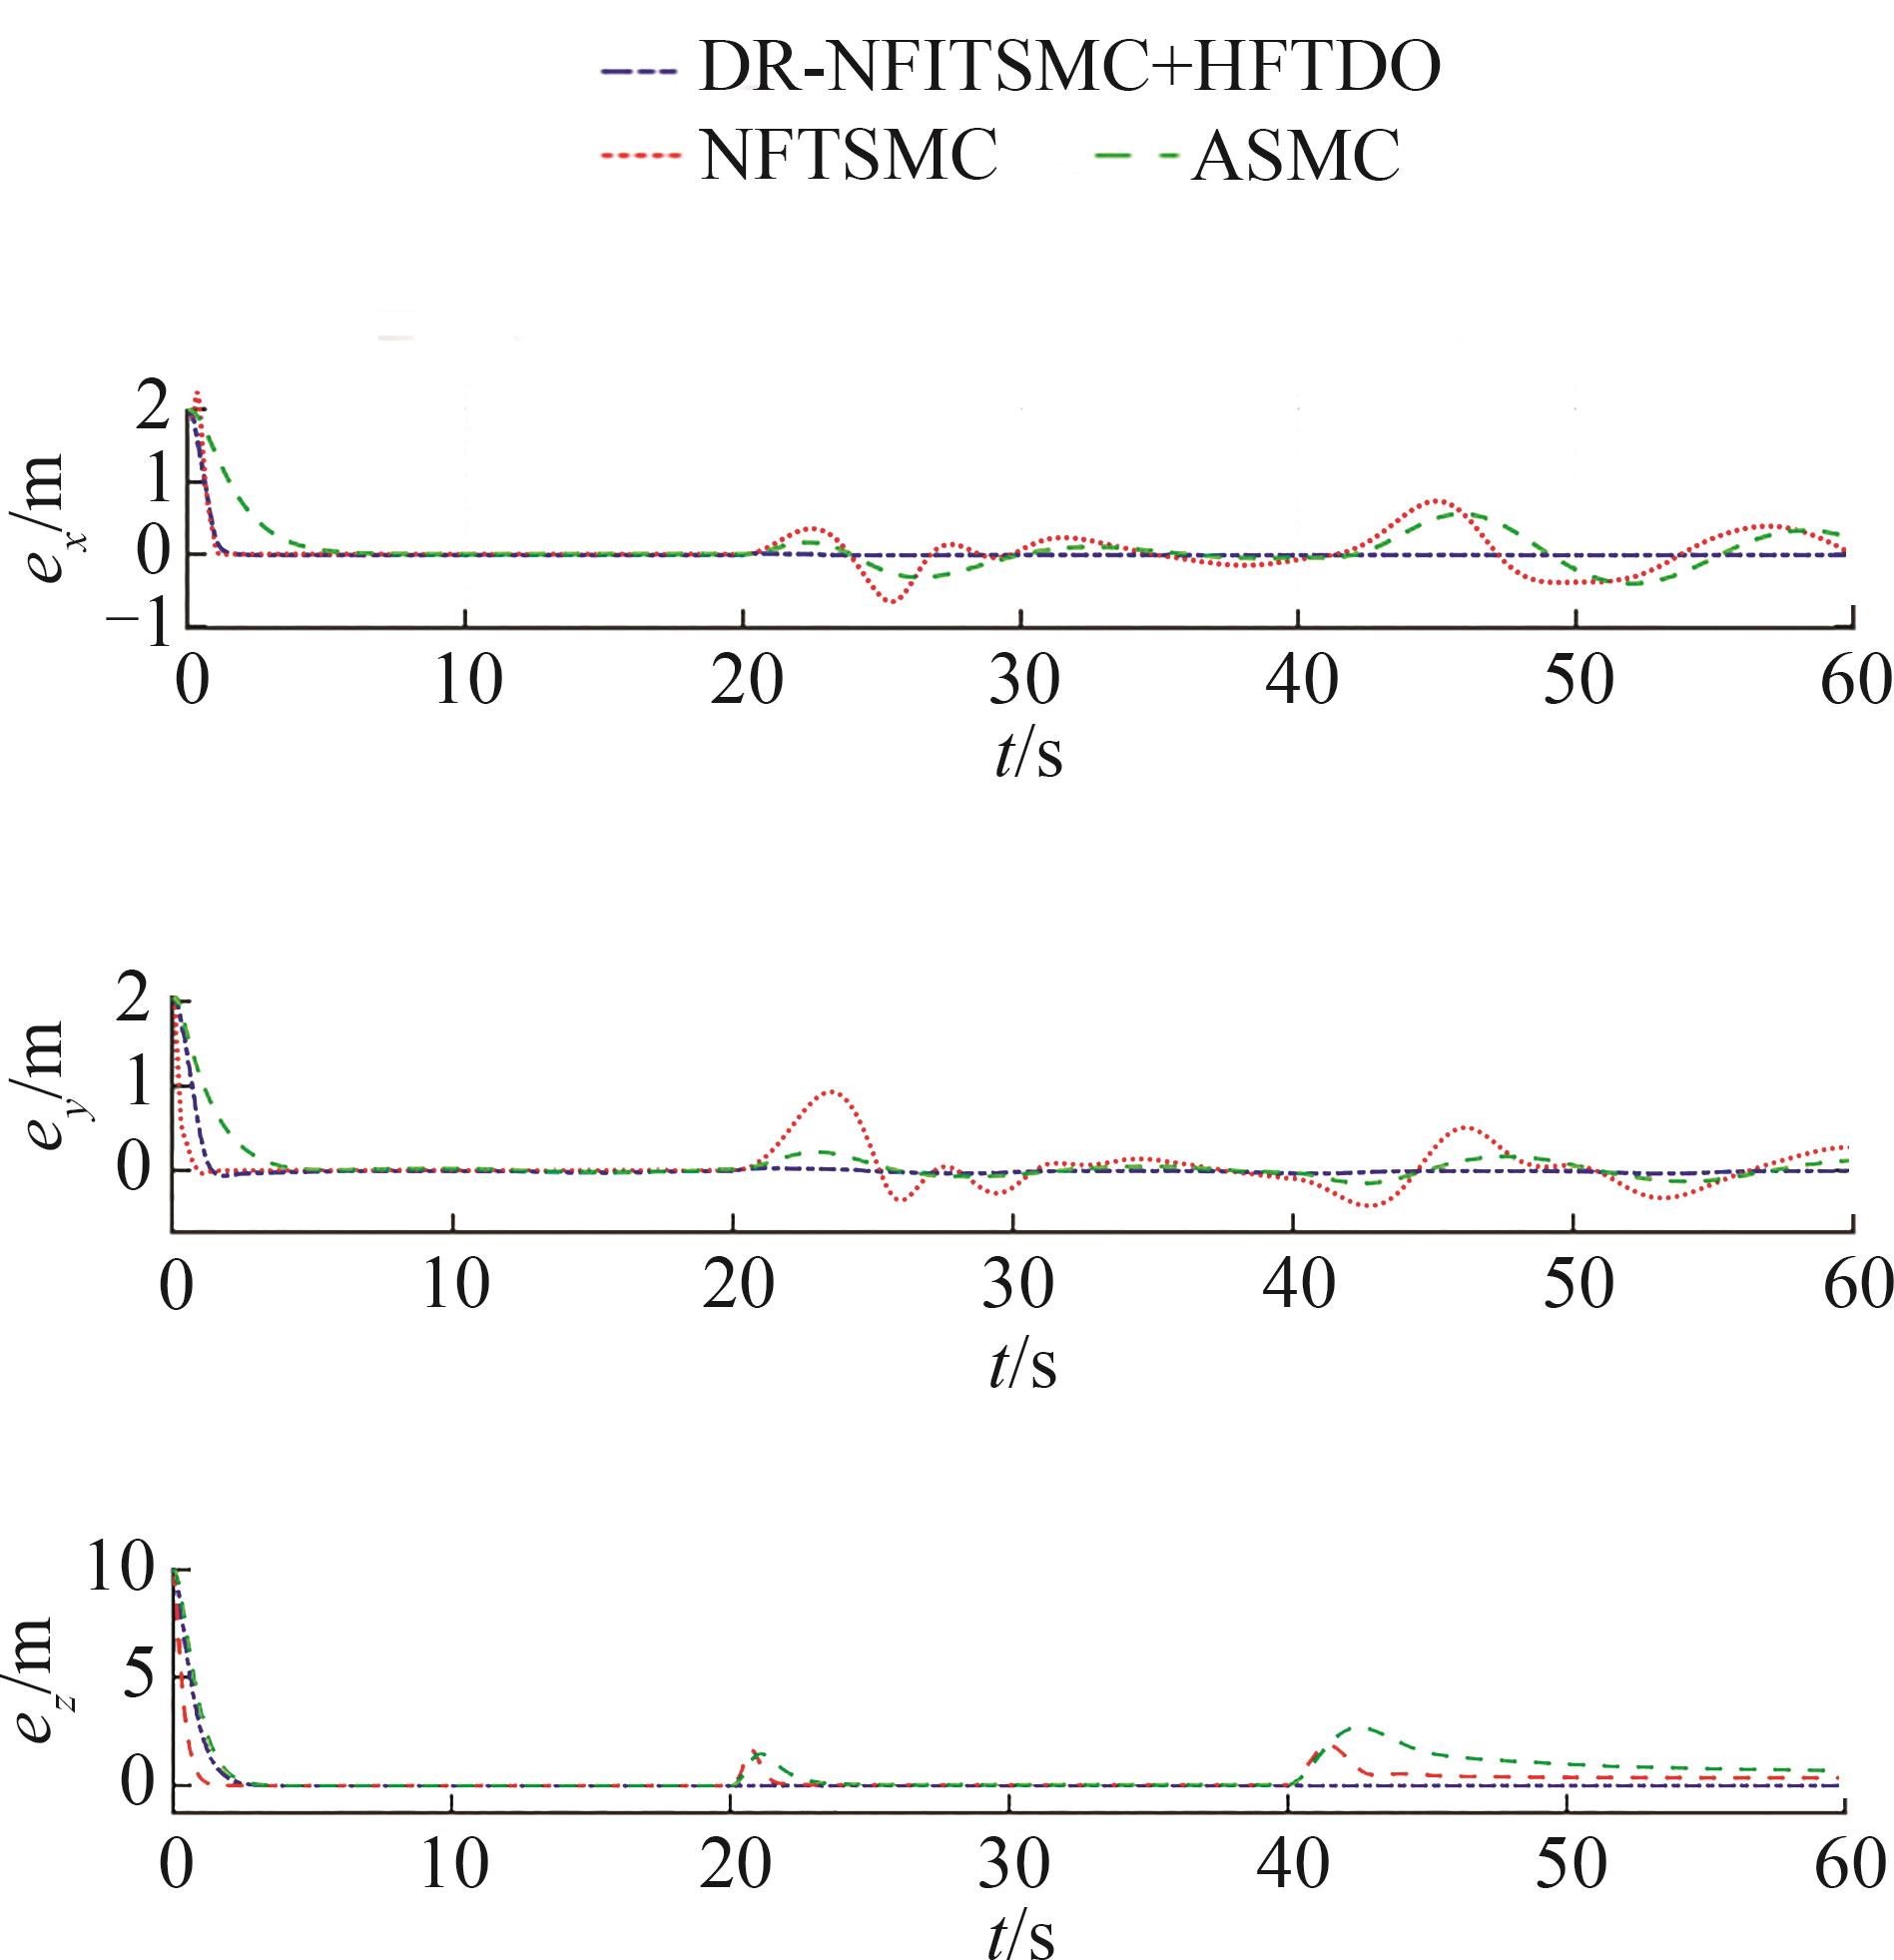
Fig. 10
Opposite-side multi-rotor fault experiment: attitude tracking
Fig. 11
Same-side multi-rotor fault experiment: position tracking
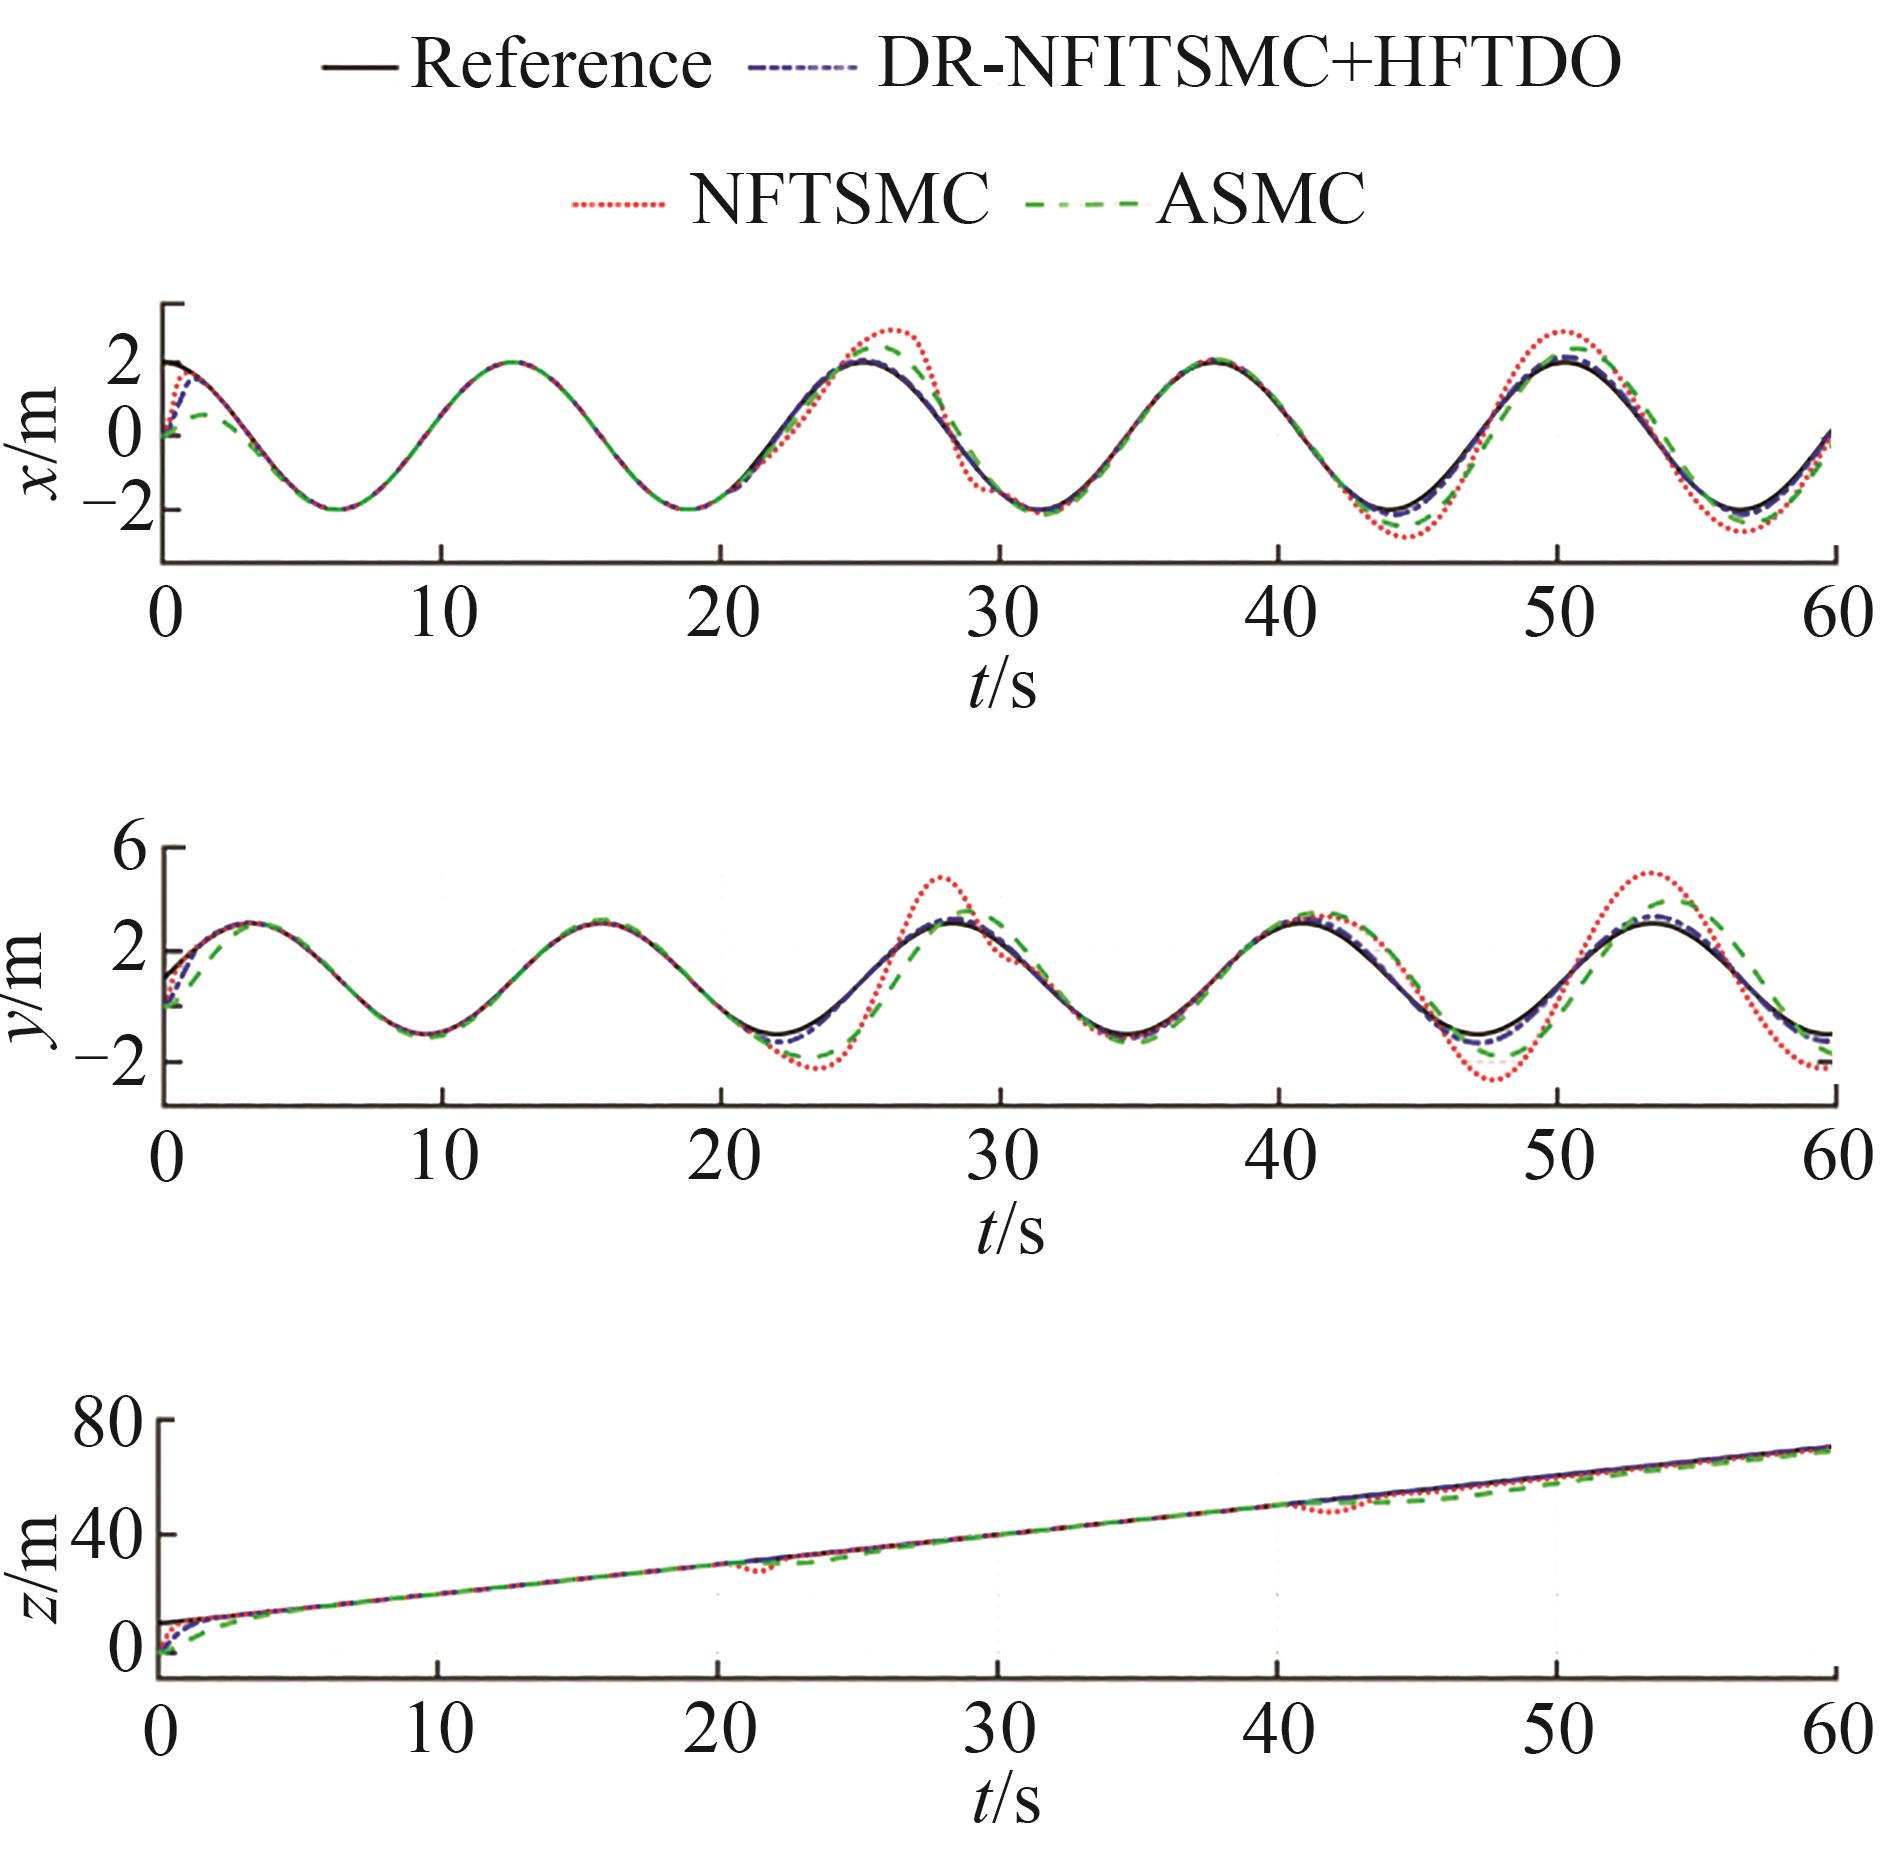
Fig. 12
Same-side multi-rotor fault experiment: position error
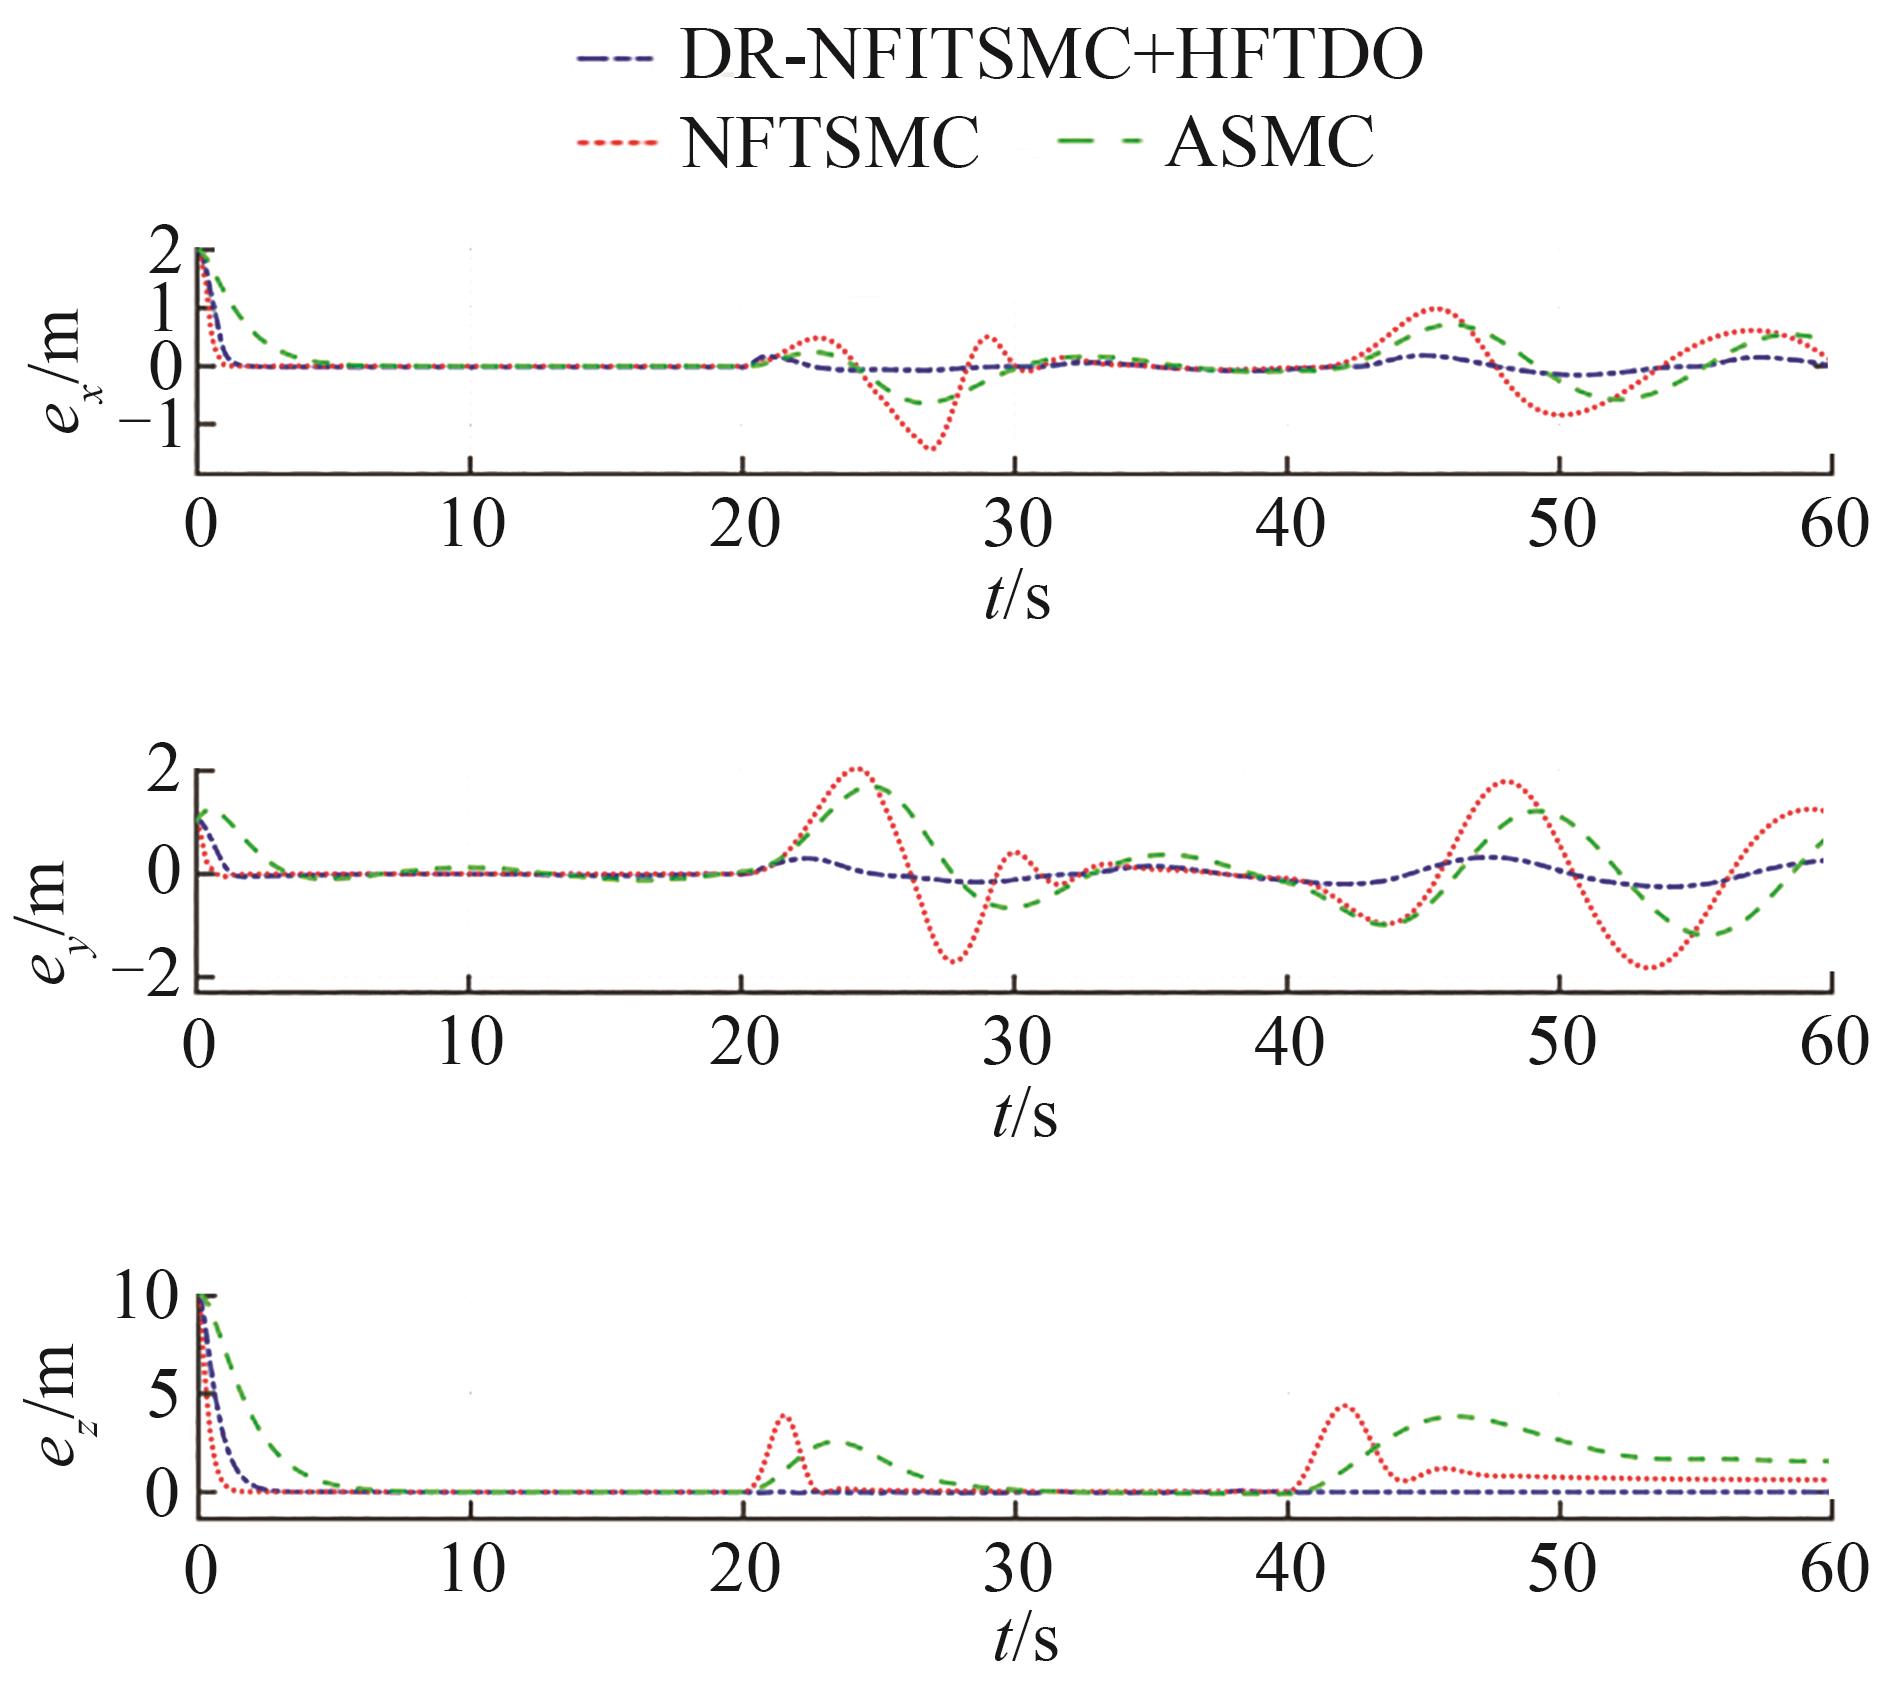
Fig. 13
Same-side multi-rotor fault experiment: attitude tracking
| [1] | 王芳, 白傑, 杨丽平, 等. 探索飞行汽车通勤新模式的城市空中交通发展分析[J]. 北京理工大学学报, 2023, 43(7): 665-675. |
| Wang Fang, Bai Jie, Yang Liping, et al. An Overview on Development of Urban Air Traffic with a New Mode of Flying Car Commuting[J]. Transactions of Beijing Institute of Technology, 2023, 43(7): 665-675. | |
| [2] | Kuantama Endrowednes, Tarca Ioan, Tarca Radu. Feedback Linearization LQR Control for Quadcopter Position Tracking[C]//2018 5th International Conference on Control, Decision and Information Technologies (CoDIT). Piscataway: IEEE, 2018: 204-209. |
| [3] | Swarnkar Swati, Parwana Hardik, Kothari Mangal, et al. Biplane-quadrotor Tail-sitter UAV: Flight Dynamics and Control[J]. Journal of Guidance, Control, and Dynamics, 2018, 41(5): 1049-1067. |
| [4] | Ahmed Bilal, Pota Hemanshu R, Garratt Matt. Flight Control of a Rotary Wing UAV Using Backstepping[J]. International Journal of Robust and Nonlinear Control, 2010, 20(6): 639-658. |
| [5] | Ximin Lü, Zhou Jinni, Gu Haowei, et al. Disturbance Observer Based Hovering Control of Quadrotor Tail-sitter VTOL UAVs Using H∞ Synthesis[J]. IEEE Robotics and Automation Letters, 2018, 3(4): 2910-2917. |
| [6] | 陈涛, 刘建璇, 王立忠, 等. 六轴机械臂非奇异快速积分终端滑模轨迹跟踪控制研究[J]. 系统仿真学报, 2025, 37(8): 2115-2123. |
| Chen Tao, Liu Jianxuan, Wang Lizhong, et al. Research on Non-singular Fast Integral Terminal Sliding Mode Trajectory Tracking Control of Six-axis Robotic Arm[J]. Journal of System Simulation, 2025, 37(8): 2115-2123. | |
| [7] | Boudjedir Hana, Bouhali Omar, Rizoug Nassim. Adaptive Neural Network Control Based on Neural Observer for Quadrotor Unmanned Aerial Vehicle[J]. Advanced Robotics, 2014, 28(17): 1151-1164. |
| [8] | Qu Shen, He Tianyi, Su Weihua. Mixed Model Predictive Control and Data-driven Control of a Tiltrotor eVTOL Aircraft[C]//AIAA SCITECH 2024 Forum. Reston: AIAA, 2024: AIAA 2024-0517. |
| [9] | 杜昊, 郭玉英, 黄志. 基于强化学习的无人机吊挂系统容错与抗摆控制研究[J/OL]. 控制工程. (2025-04-28) [2025-09-01]. . |
| Du Hao, Guo Yuying, Huang Zhi. Reinforcement Learning Based Fault Tolerance and Anti-swing Control for Quadrotor UAV with a Slung Load[J/OL]. Control Engineering of China. (2025-04-28) [2025-09-01]. . | |
| [10] | Freddi Alessandro, Lanzon Alexander, Longhi Sauro. A Feedback Linearization Approach to Fault Tolerance in Quadrotor Vehicles[J]. IFAC Proceedings Volumes, 2011, 44(1): 5413-5418. |
| [11] | Wang Xuerui, Sun Sihao, van Kampen Erik-Jan, et al. Quadrotor Fault Tolerant Incremental Sliding Mode Control Driven by Sliding Mode Disturbance Observers[J]. Aerospace Science and Technology, 2019, 87: 417-430. |
| [12] | Zeghlache Samir, Mekki Hemza, Bouguerra Abderrahmen, et al. Actuator Fault Tolerant Control Using Adaptive RBFNN Fuzzy Sliding Mode Controller for Coaxial Octorotor UAV[J]. ISA Transactions, 2018, 80: 267-278. |
| [13] | Li Cao, Pan Tianhong, Ding Shihong. Finite-time Fast Integral Terminal Sliding-mode Speed Control Method with Disturbance Observer for SPMSM[J]. IEEE Transactions on Power Electronics, 2025, 40(8): 10694-10704. |
| [14] | Jayakrishnan H J. Position and Attitude Control of a Quadrotor UAV Using Super Twisting Sliding Mode[J]. IFAC-PapersOnLine, 2016, 49(1): 284-289. |
| [15] | Antonio Gonzalez Rot, Hasan Agus, Manoonpong Poramate. Robust Actuator Fault Diagnosis Algorithm for Autonomous Hexacopter UAVs[J]. IFAC-PapersOnLine, 2020, 53(2): 682-687. |
| [16] | 陈涛, 陈建. 基于学习观测器的无人机故障弹性容错控制[J]. 航空学报, 2025, 46(11): 478-490. |
| Chen Tao, Chen Jian. Learning-observer-based Resilient Fault-tolerant Control for Quadrotor Unmanned Aerial Vehicles[J]. Acta Aeronautica et Astronautica Sinica, 2025, 46(11): 478-490. | |
| [17] | Xiang Senwei, Xie Huanan, Ye Minxiang, et al. Autonomous eVTOL: A Summary of Researches and Challenges[J]. Green Energy and Intelligent Transportation, 2024, 3(1): 100140. |
| [18] | Fu Yifang, Wang Ban, Zhao Huimin, et al. Adaptive Safety Attitude Control of a Hybrid VTOL UAV Under Transition Flight Subject to Multiple Faults and Uncertainties[J]. Aerospace Science and Technology, 2025, 163: 110284. |
| [19] | Jia Chao, Liu Xiaohua, Jia Fanlin, et al. Prescribed-time Nonsingular Sliding Mode Control Based on Neural Network for Trajectory Tracking of Nonlinear Systems[J]. Information Sciences, 2025, 701: 121850. |
| [20] | 张思洁, 吴怀宇, 郑秀娟. 具有执行器故障的四旋翼无人机有限时间容错控制[J]. 控制理论与应用, 2023, 40(7): 1270-1276. |
| Zhang Sijie, Wu Huaiyu, Zheng Xiujuan. Finite-time Fault Tolerant Control of Quadrotor UAV with Actuator Faults[J]. Control Theory & Applications, 2023, 40(7): 1270-1276. | |
| [21] | Gasga P, Bernal M, Gómez-Peñate S, et al. Actuator Multiplicative and Additive Simultaneous Faults Estimation Using a qLPV Proportional Integral Unknown Input Observer[J]. International Journal of Adaptive Control and Signal Processing, 2024, 38(8): 2930-2950. |
| [22] | 陈谋, 马浩翔, 雍可南, 等. 无人机安全飞行控制综述[J]. 机器人, 2023, 45(3): 345-366. |
| Chen Mou, Ma Haoxiang, Yong Kenan, et al. Safety Flight Control of UAV:A Survey[J]. Robot, 2023, 45(3): 345-366. | |
| [23] | Santos Davi, Saska Martin, Nascimento Tiago. A Generalized Thrust Estimation and Control Approach for Multirotors Micro Aerial Vehicles[J]. IEEE Robotics and Automation Letters, 2024, 9(10): 8889-8896. |
| [24] | Levant Arie. Higher-order Sliding Modes, Differentiation and Output-feedback Control[J]. International Journal of Control, 2003, 76(9/10): 924-941. |
| [25] | 苗永泽, 范兴纲, 李大伟, 等. 电动垂直起降飞行器电驱系统研究进展综述[J]. 航空学报, 2025, 46(22): 143-174. |
| Miao Yongze, Fan Xinggang, Li Dawei, et al. Research Advances in Electrical Propulsion Systems for Electric Vertical Take-off and Landing Aircrafts: A Comprehensive Review[J]. Acta Aeronautica et Astronautica Sinica, 2025, 46(22): 143-174. | |
| [26] | 张康, 汤新民, 顾俊伟. 基于风险意识的eVTOL自主避让[J]. 航空学报, 2026, 47(2): 222-235. |
| Zhang Kang, Tang Xinmin, Gu Junwei. Risk-aware Autonomous Avoidance for eVTOL[J]. Acta Aer, 2026, 47(2): 222-235. |
| [1] | Chen Tao, Liu Jianxuan, Wang Lizhong, Zou Xiangjun, Li Xiaojuan. Research on Non-singular Fast Integral Terminal Sliding Mode Trajectory Tracking Control of Six-axis Robotic Arm [J]. Journal of System Simulation, 2025, 37(8): 2115-2123. |
| [2] | Li Boning, Chen Ming, Qi Shuchang, Meng Haoran, Wang Lei. Attitude Control of Quadrotor UAV Based on Disturbance Observer and Command Filtering [J]. Journal of System Simulation, 2025, 37(11): 2793-2803. |
| [3] | Yafei Mei, Ying Liao, Kejie Gong, Xingyu Zheng. SE(3)-based Finite-time Fault-tolerant Control of Spacecraft Integrated Attitude-orbit [J]. Journal of System Simulation, 2023, 35(2): 277-285. |
| [4] | Zhao Jing, Wang Peng, Ding Xiaoqian, Jiang Guoping, Xu Fengyu, Sun Yanfei. Fault Tolerant Control and Simulation of Quadrotor Based on Adaptive Observer [J]. Journal of System Simulation, 2022, 34(1): 1-10. |
| [5] | Han Kaiwei, Wang Yan, Ji Zhicheng. Design and Simulation on a Novel Sliding Mode Control for Linear Induction Motor [J]. Journal of System Simulation, 2020, 32(11): 2146-2154. |
| [6] | Mi Gensuo, Liang Huaqi. Nonlinear Sliding Mode Control for Robotic Manipulator Based on Disturbance Observer [J]. Journal of System Simulation, 2019, 31(9): 1935-1941. |
| [7] | Hou Limin, Ren Yifu, Liu Hengfei, Lin Dong. Sliding Mode Auto Disturbance Rejection Control of PMSM without Speed Sensor [J]. Journal of System Simulation, 2019, 31(5): 963-970. |
| [8] | Liu Xiaocen, Wu Yunjie, Xu Peng. Attitude Control of Hypersonic Vehicle Considering Input Saturation [J]. Journal of System Simulation, 2019, 31(11): 2553-2561. |
| [9] | Yang Jianfeng, Jiang Hui, Zhou Tianqi. Control method of unified SVPWM for three-phase four-switch Fault-tolerant APF based on inductor current [J]. Journal of System Simulation, 2019, 31(10): 2103-2111. |
| [10] | LiYajie, Li Wei. Satisfactory Fault-tolerant Control of NNCS under Event-triggered Sparse Data Transmission [J]. Journal of System Simulation, 2018, 30(4): 1581-1593. |
| [11] | Liu Huibo, Liu Shanglei. Fuzzy Sliding Backstepping Mode Control for Flight Simulator Servo Based on Friction and Disturbance Compensation [J]. Journal of System Simulation, 2018, 30(3): 1195-1203. |
| [12] | Li Wei, Zhai Pengfei, Li Yajie. Co-design Between New Event-triggered Communication Scheme and Less Conservative Robust H∞ Fault-tolerant Control for Networked Control Systems [J]. Journal of System Simulation, 2017, 29(4): 740-751. |
| [13] | Li Wei, Yan Kun, Li Yajie. Co-design Between Robust H∞ Guaranteed Cost Fault-tolerant and Communication for NNCS Based on Event-triggered [J]. Journal of System Simulation, 2016, 28(5): 1140-1149. |
| [14] | Li Yunlong, Xia Jie, Shi Zifang. Diagnosis of Aircraft Control Surface Fault Based on Semi-physical Simulation [J]. Journal of System Simulation, 2015, 27(8): 1914-1921. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
 http://www.china-simulation.com

