Journal of System Simulation ›› 2026, Vol. 38 ›› Issue (9): 2464-2485.doi: 10.16182/j.issn1004731x.joss.25-1067
• Special Column : System Simulation for Autonomous Driving and Intelligent Transportation • Previous Articles
Li Jiwei1, Wang Runmin1,2, Zhu Yu1, Cheng Jingjun1,2, Zhao Xiangmo1,2
Received:2025-11-03
Revised:2026-01-06
Online:2026-09-30
Published:2026-10-02
Contact:
Wang Runmin
CLC Number:
Li Jiwei, Wang Runmin, Zhu Yu, Cheng Jingjun, Zhao Xiangmo. Review of Evaluation Metrics for the Credibility of Autonomous Driving Test Scenarios[J]. Journal of System Simulation, 2026, 38(9): 2464-2485.
Table 1
Value assignment of Fpc
| TTC/s | |
|---|---|
| 5~10 | 1 |
| 3~5 | 2 |
| 1~3 | 3 |
| <1 | 4 |
Table 2
Value assignment of Fbe
| 可能性 | |
|---|---|
| 极低 | 1 |
| 低 | 2 |
| 中 | 3 |
| 高 | 4 |
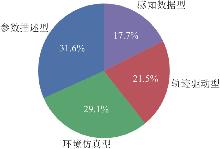
Fig. 1
Proportion of literature on each test scenario type in the past five years
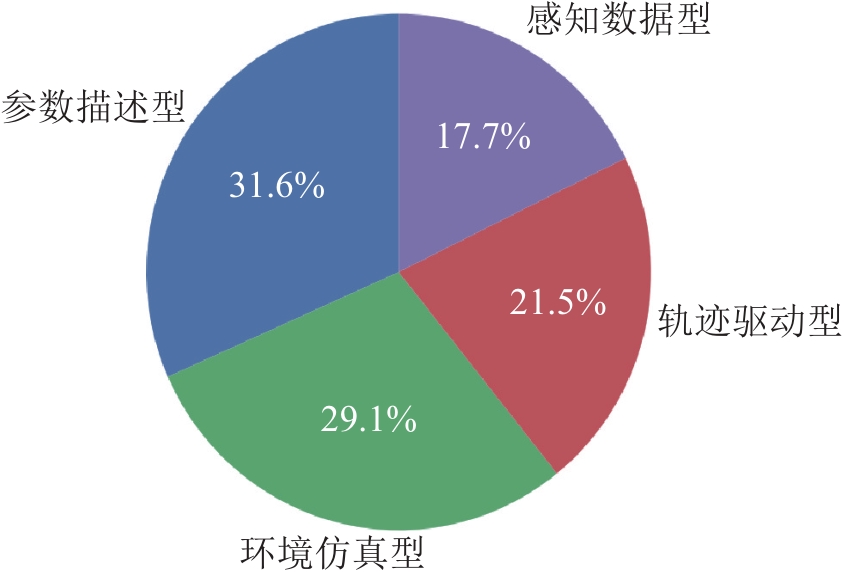
Fig. 2
Parameter-descriptive test scenarios
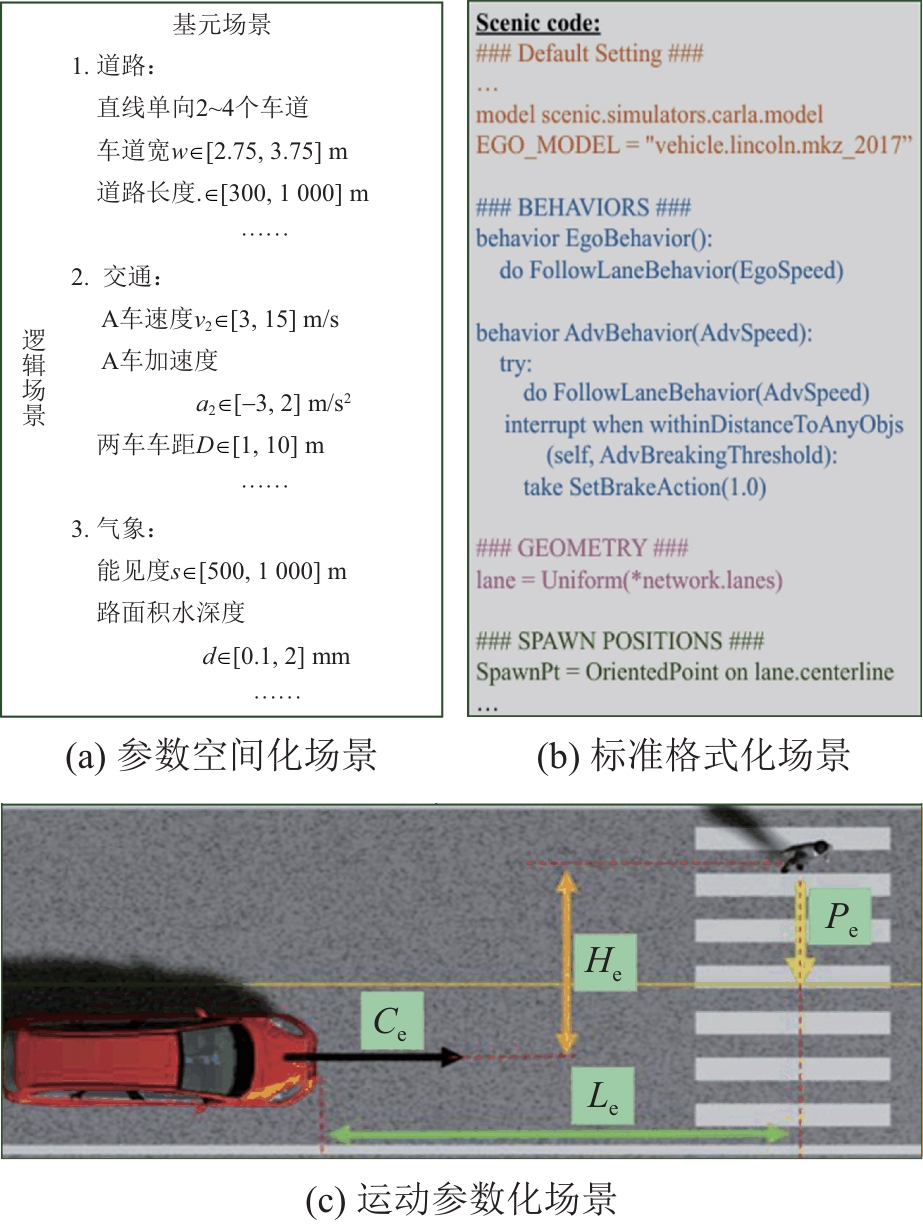
Fig. 3
Trajectory-driven test scenarios
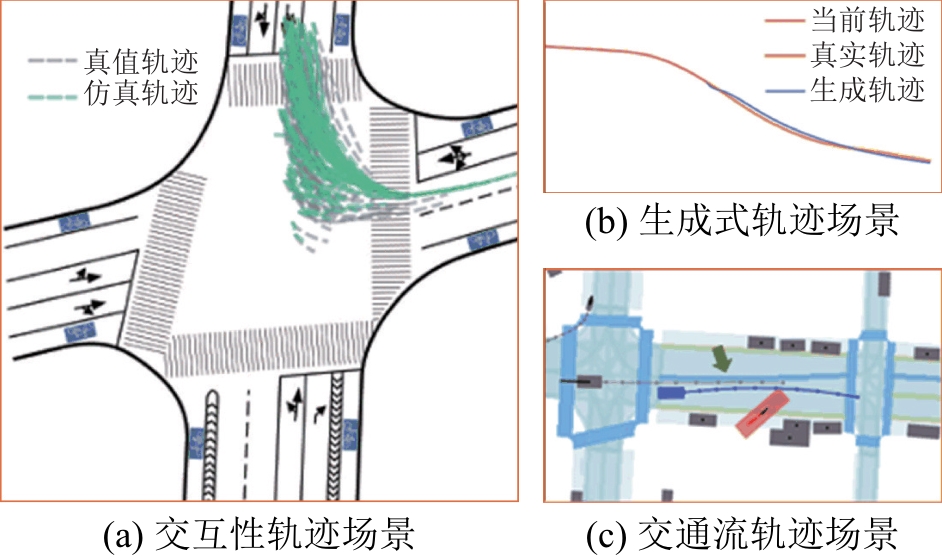
Fig. 4
Environment-simulation test scenarios
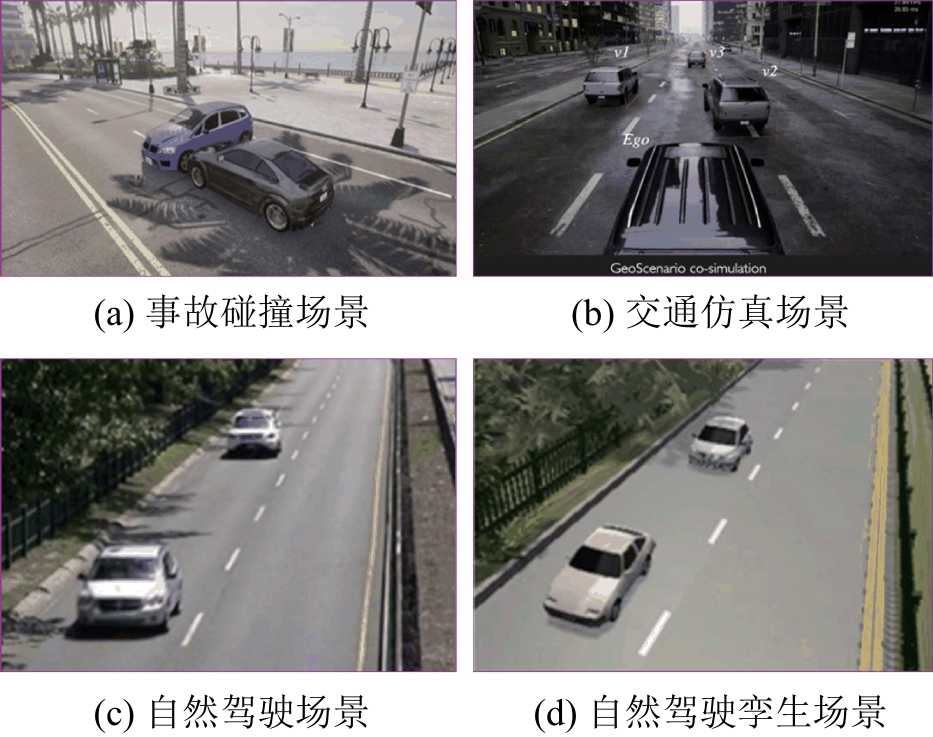
Fig. 5
Perception-data-driven test scenarios
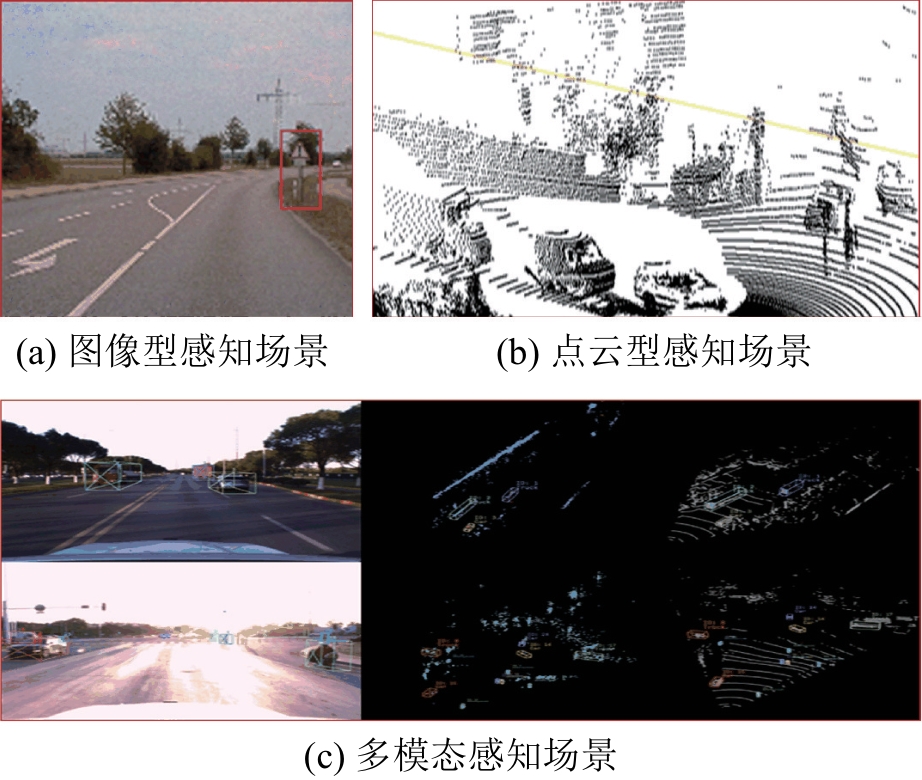
Table 3
Main evaluation metrics for parameter-descriptive scenarios
| 评价维度 | 指标类型 | 指标描述 | 典型文献 |
|---|---|---|---|
| 挑战性 | 统计特征 | 如仿真中危险行为的发生比例 | [ |
| 风险特征 | 由TTC等子指标组合而成的综合风险度量 | [ | |
| 真实性 | 数值误差 | 生成场景与真实场景的接近程度 | [ |
| 覆盖度 | 统计特征 | 生成场景在总体参数空间中的分布比例 | [ |
| 误差特征 | ADE、AOE等,通过误差体现生成场景的多样性 | [ | |
| 加速性 | 采样加速率 | 单位时间内可提取的有效场景数量 | [ |
| 生成加速率 | 往往综合考虑场景复杂度与生成速度 | [ | |
| 测试加速率 | 在有限资源下的有效测试次数或运行场景数量 | [ |
Table 4
Main evaluation metrics for trajectory-driven scenarios
| 评价维度 | 指标类型 | 指标描述 | 典型文献 |
|---|---|---|---|
| 挑战性 | 统计特征 | 统计系统在轨迹场景中发生碰撞或失效的次数与比例 | [ |
| 风险特征 | 综合车辆运行状态等指标,量化场景的实时风险水平 | [ | |
| 真实性 | 数值误差 | 如Hausdorff距离/RMSE /MAE衡量生成轨迹与真实轨迹在时间和空间序列上的整体误差 | [ |
| 分类一致性 | 利用时间序列分类模型区分生成与真实数据 | [ | |
| 覆盖度 | 统计特征 | 衡量生成轨迹在行为层面是否充分覆盖真实分布 | [ |
| 数值误差 | 如动态时间规整/轨迹交并比,衡量生成轨迹的扩散程度 | [ | |
| 拟人性 | 数值误差 | 如RMSE衡量生成轨迹与人类驾驶轨迹间的误差 | [ |
| 行为一致性 | 评估生成轨迹在表现上是否具备人类驾驶特征 | [ |
Table 5
Main evaluation metrics for environment-simulation scenarios
| 评价维度 | 指标类型 | 指标描述 | 典型文献 |
|---|---|---|---|
| 挑战性 | 统计特征 | 仿真中危险行为的发生比例 | [ |
| 风险特征 | 多场景要素组合而成的高综合性风险度量 | [ | |
| 真实性 | 数值误差 | 多样化场景构成要素与真实分布的差异 | [ |
| 覆盖度 | 实例覆盖度 | 对可观察到的仿真场景直接进行分类统计 | [ |
| 聚类覆盖度 | 对道路结构等多场景要素进行聚类 | [ | |
| 拟人性 | 行为一致性 | 直观评估仿真中交通参与者交互的合理性与自然性 | [ |
Table 6
Main evaluation metrics for perception-data-driven scenarios
| 评价维度 | 指标类型 | 指标描述 | 典型文献 |
|---|---|---|---|
| 挑战性 | 性能一致性 | 如mAP、准确率等评估感知系统表现 | [ |
| 模块敏感性 | 对比系统在不同场景要素组合下的检测表现 | [ | |
| 真实性 | 质量保真性 | 如PSNR、FADE等用于衡量生成数据质量 | [ |
| 统计特征 | 如信息熵、CD、EMD用于衡量生成数据的真实性 | [ | |
| 覆盖度 | 数值误差 | 比较感知系统在仿真数据与真实数据中性能差异 | [ |
| 统计特征 | 如类别分布、目标密度、场景要素组合数 | [ |
Table 7
Typical metrics for credibility evaluation of test scenarios
| 评价维度 | 指标类型 | 范例指标 | 典型计算公式 |
|---|---|---|---|
| 挑战性 | 性能一致性 | AP | |
| 模块敏感性 | 成功率变化 | ||
| 统计特征 | 碰撞率 | ||
| 风险特征 | 风险指数 | ||
| 真实性 | 分类一致性 | 一致性分数 | |
| 质量保真性 | SSIM | ||
| 统计特征 | EMD | ||
| 数值误差 | RMSE | ||
| 覆盖度 | 实例覆盖度 | 场景覆盖率 | |
| 聚类覆盖度 | 要素覆盖率 | ||
| 数值误差 | ADE | ||
| 统计特征 | 参数空间覆盖率 | ||
| 拟人性 | 数值误差 | RMSE | |
| 行为一致性 | 驾驶风格相似度 | ||
| 加速性 | 采样加速率 | 关键产出率 | |
| 生成加速率 | 生成速率 | ||
| 测试加速率 | 缺陷触发效率 |
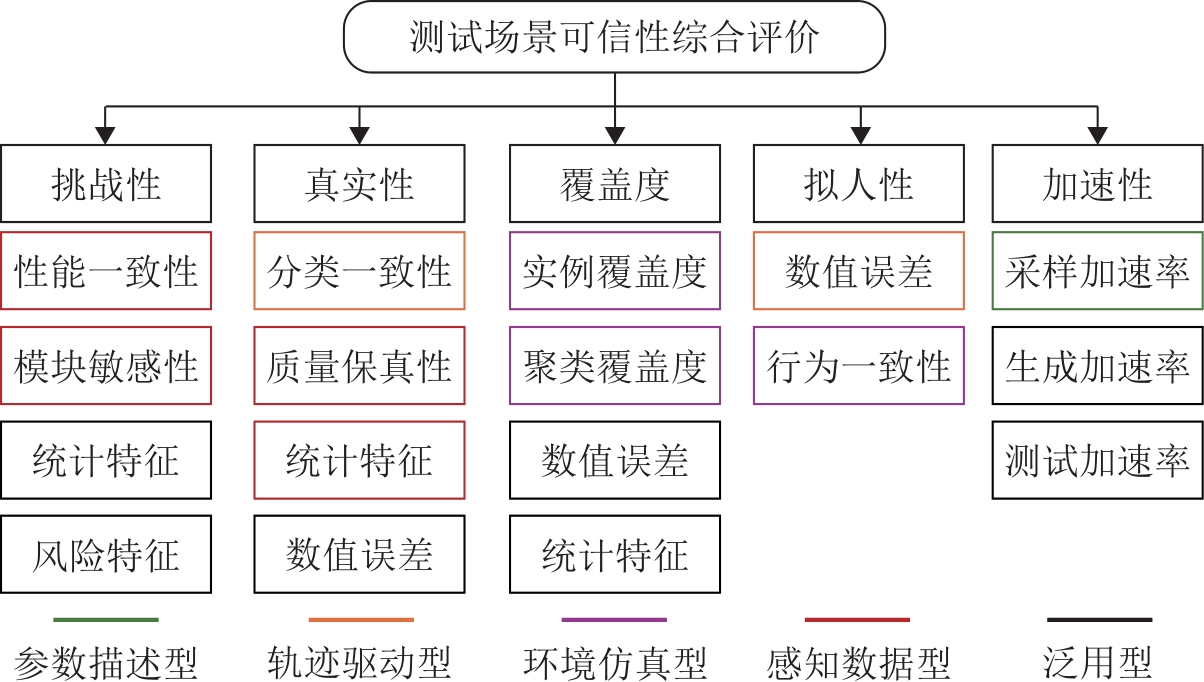
Fig. 6
Framework of the credibility evaluation metric system for test scenarios
| [1] | 朱冰, 张培兴, 赵健, 等. 基于场景的自动驾驶汽车虚拟测试研究进展[J]. 中国公路学报, 2019, 32(6): 1-19. |
| Zhu Bing, Zhang Peixing, Zhao Jian, et al. Review of Scenario-based Virtual Validation Methods for Automated Vehicles[J]. China Journal of Highway and Transport, 2019, 32(6): 1-19. | |
| [2] | Liu Mengfei, Ouyang Xinyu, Lu Ruikai, et al. An Evaluation Method for Automotive Technical and Comprehensive Performance[J]. Automotive Innovation, 2023, 6(2): 231-243. |
| [3] | Zhao Shulian, Duan Jianli, Wu Siyu, et al. Genetic Algorithm-based SOTIF Scenario Construction for Complex Traffic Flow[J]. Automotive Innovation, 2023, 6(4): 531-546. |
| [4] | 唐维军, 徐琨, 柳有权, 等. 自动驾驶汽车虚拟测试中的树木点云生成方法[J]. 计算机工程与应用, 2021, 57(11): 185-192. |
| Tang Weijun, Xu Kun, Liu Youquan, et al. Method for Generating Three-dimensional Point Cloud of Trees in Autonomous Vehicle Virtual Testing[J]. Computer Engineering and Applications, 2021, 57(11): 185-192. | |
| [5] | 李鹏辉, 董倩茹, 袁赫男, 等. 面向自动驾驶仿真测试的高覆盖切入场景库生成方法[J]. 中国公路学报, 2024, 37(7): 237-249. |
| Li Penghui, Dong Qianru, Yuan Henan, et al. High-coverage Cut-in Scenario Library Generation for Automated Driving Simulation Testing[J]. China Journal of Highway and Transport, 2024, 37(7): 237-249. | |
| [6] | 秦琴, 谷文军. Ball tree优化的自动驾驶仿真测试场景生成方法[J]. 计算机应用研究, 2023, 40(9): 2781-2784, 2791. |
| Qin Qin, Gu Wenjun. Ball Tree Optimized Automatic Driving Simulation Test Scenario Generation Method[J]. Application Research of Computers, 2023, 40(9): 2781-2784, 2791. | |
| [7] | 李昌文, 晏荣杰, 张健. AdvSce: 面向自动驾驶系统的安全关键场景生成工具[J]. 中国科学(信息科学), 2023, 53(4): 815-820. |
| Li Changwen, Yan Rongjie, Zhang Jian. AdvSce: Safety-critical Scenario Generation for Testing Autonomous Driving Systems[J]. Scientia Sinica(Informationis), 2023, 53(4): 815-820. | |
| [8] | Hu Qianjiang, Zhang Zhimin, Hu Wei. RangeLDM: Fast Realistic LiDAR Point Cloud Generation[C]//Computer Vision-ECCV 2024. Cham: Springer Nature Switzerland, 2025: 115-135. |
| [9] | 孙剑, 张赫, 赵晓聪, 等. 面向自动驾驶测试的交互场景策略建模与仿真[J]. 汽车工程, 2024, 46(11): 1962-1972. |
| Sun Jian, Zhang He, Zhao Xiaocong, et al. Interactive Scenarios Strategy Modeling and Simulation for Automated Driving Testing[J]. Automotive Engineering, 2024, 46(11): 1962-1972. | |
| [10] | Günaydın Batuhan, Sarp Kaya Yetkin, Tomruk Mert, et al. ISO 34505 Based Test Evaluation Methodology for ADAS/AD[C]//2025 IEEE Intelligent Vehicles Symposium (IV). [S.l.] : IEEE, 2025: 807-812. |
| [11] | 李江坤, 纵瑞雪, 邓伟文, 等. 基于有向图的城市交叉口场景相似性评价方法[J]. 汽车工程, 2025, 47(1): 23-34. |
| Li Jiangkun, Zong Ruixue, Deng Weiwen, et al. Directed Graph-based Method for Evaluating Similarity in Urban Intersection Scenarios[J]. Automotive Engineering, 2025, 47(1): 23-34. | |
| [12] | 朱冰, 张培兴, 赵健. 面向多维度逻辑场景的自动驾驶安全性聚类评价方法[J]. 汽车工程, 2020, 42(11): 1458-1463, 1505. |
| Zhu Bing, Zhang Peixing, Zhao Jian. Clustering Evaluation Method of Autonomous Driving Safety for Multi-dimensional Logical Scenario[J]. Automotive Engineering, 2020, 42(11): 1458-1463, 1505. | |
| [13] | 陈浩, 王红, 李维汉, 等. 基于行车安全场理论的预期功能安全场景风险评估[J]. 汽车工程, 2022, 44(11): 1636-1646. |
| Chen Hao, Wang Hong, Li Weihan, et al. Risk Assessment of Safety of the Intended Functionality Scenes Based on Driving Safety Field Theory[J]. Automotive Engineering, 2022, 44(11): 1636-1646. | |
| [14] | 王荣, 孙亚夫, 宋娟. 自动驾驶车辆道路测试场景评价方法与试验验证[J]. 汽车工程, 2021, 43(4): 620-628. |
| Wang Rong, Sun Yafu, Song Juan. Evaluation Method and Test Verification of Road Test Scenes for Autonomous Vehicles[J]. Automotive Engineering, 2021, 43(4): 620-628. | |
| [15] | 李平飞, 金思雨, 胡文浩, 等. 用于自动驾驶仿真测试的车-车事故场景复杂度评价[J]. 汽车安全与节能学报, 2022, 13(4): 697-704. |
| Li Pingfei, Jin Siyu, Hu Wenhao, et al. Complexity Evaluation of Vehicle-vehicle Accident Scenarios for Autonomous Driving Simulation Tests[J]. Journal of Automotive Safety and Energy, 2022, 13(4): 697-704. | |
| [16] | Gao Tianfang, Chen Liang, Zhang Xinghui, et al. Credibility Assessment for Digital Twins in Vehicle-in-the-loop Test Based on Information Entropy[J]. Sensors, 2025, 25(5): 1372. |
| [17] | Li Shiqi, Zhou Rui, Huang Helai. Multidimensional Evaluation of Autonomous Driving Test Scenarios Based on AHP-EWN-TOPSIS Models[J]. Automotive Innovation, 2025, 8(2): 237-251. |
| [18] | 周文帅, 朱宇, 赵祥模, 等. 面向高速公路车辆切入场景的自动驾驶测试用例生成方法[J]. 汽车技术, 2021(1): 11-18. |
| Zhou Wenshuai, Zhu Yu, Zhao Xiangmo, et al. Vehicle Cut-in Test Case Generation Methods for Testing of Autonomous Driving on Highway[J]. Automobile Technology, 2021(1): 11-18. | |
| [19] | 郭洪艳, 张家铭, 刘俊, 等. 面向智能汽车-行人交互的虚拟测试场景构建[J]. 吉林大学学报(工学版), 2024, 54(9): 2511-2519. |
| Guo Hongyan, Zhang Jiaming, Liu Jun, et al. Construction of Virtual Test Scenario for Intelligent Vehicle and Pedestrian Interaction[J]. Journal of Jilin University(Engineering and Technology Edition), 2024, 54(9): 2511-2519. | |
| [20] | Zhang Jiawei, Xu Chejian, Li Bo. ChatScene: Knowledge-enabled Safety-critical Scenario Generation for Autonomous Vehicles[C]//2024 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2024: 15459-15469. |
| [21] | 陈吉清, 舒孝雄, 兰凤崇, 等. 典型危险事故特征的自动驾驶测试场景构建[J]. 华南理工大学学报(自然科学版), 2021, 49(5): 1-8. |
| Chen Jiqing, Shu Xiaoxiong, Lan Fengchong, et al. Construction of Autonomous Vehicles Test Scenarios with Typical Dangerous Accident Characteristics[J]. Journal of South China University of Technology(Natural Science Edition), 2021, 49(5): 1-8. | |
| [22] | Huang Yan, Sun Jian, Tian Ye. A Bayesian Optimization Method for Finding the Worst-case Scenarios of Autonomous Vehicles[J]. IEEE Transactions on Intelligent Transportation Systems, 2025, 26(1): 529-543. |
| [23] | 朱冰, 范天昕, 赵健, 等. 自动驾驶拟人连续交互测试场景生成方法[J]. 汽车工程, 2024, 46(9): 1600-1607. |
| Zhu Bing, Fan Tianxin, Zhao Jian, et al. Generation Method for Anthropomorphic Continuous Interactive Test Scenarios of Automated Driving[J]. Automotive Engineering, 2024, 46(9): 1600-1607. | |
| [24] | Wang Jingkang, Pun Ava, Tu James, et al. AdvSim: Generating Safety-critical Scenarios for Self-driving Vehicles[C]//2021 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2021: 9904-9913. |
| [25] | Li Ye, Zeng Fanming, Han Chunyang, et al. Vehicle Lane-changing Scenario Generation Using Time-series Generative Adversarial Networks with an Adaptative Parameter Optimization Strategy[J]. Accident Analysis & Prevention, 2024, 205: 107667. |
| [26] | Hao Kunkun, Cui Wen, Luo Yonggang, et al. Adversarial Safety-critical Scenario Generation Using Naturalistic Human Driving Priors[J]. IEEE Transactions on Intelligent Vehicles, 2024, 9(9): 5392-5406. |
| [27] | Queiroz Rodrigo, Sharma Divit, Caldas Ricardo, et al. A Driver-vehicle Model for ADS Scenario-based Testing[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(8): 8641-8654. |
| [28] | Li Xuan, Teng Siyu, Liu Bingzi, et al. Retracted: Advanced Scenario Generation for Calibration and Verification of Autonomous Vehicles[J]. IEEE Transactions on Intelligent Vehicles, 2023, 8(5): 3211-3216. |
| [29] | Chen Baiming, Chen Xiang, Wu Qiong, et al. Adversarial Evaluation of Autonomous Vehicles in Lane-change Scenarios[J]. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(8): 10333-10342. |
| [30] | Deng Yao, Zheng Xi, Zhang Tianyi, et al. A Declarative Metamorphic Testing Framework for Autonomous Driving[J]. IEEE Transactions on Software Engineering, 2023, 49(4): 1964-1982. |
| [31] | Huang Tengchao, Song Shuang, Hu Huosheng, et al. A Hierarchical LiDAR Simulation Framework Incorporating Physical Attenuation Response in Autonomous Driving Scenarios[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(6): 6200-6211. |
| [32] | Zheng Lianqing, Ma Zhixiong, Zhu Xichan, et al. TJ4DRadSet: A 4D Radar Dataset for Autonomous Driving[C]//2022 IEEE 25th International Conference on Intelligent Transportation Systems (ITSC). Piscataway: IEEE Press, 2022: 493-498. |
| [33] | Choi J I, Tian Qing. Adversarial Attack and Defense of YOLO Detectors in Autonomous Driving Scenarios[C]//2022 IEEE Intelligent Vehicles Symposium (IV). Piscataway: IEEE, 2022: 1011-1017. |
| [34] | Li Zhuopeng, Li Lu, Zhu Jianke. READ: Large-Scale Neural Scene Rendering for Autonomous Driving[C]//Proceedings of the Thirty-seventh AAAI Conference on Artificial Intelligence and Thirty-fifth Conference on Innovative Applications of Artificial Intelligence and Thirteenth Symposium on Educational Advances in Artificial Intelligence. Palo Alto: AAAI Press, 2023: 1522-1529. |
| [35] | Mao Jiageng, Niu Minzhe, Jiang ChenHan, et al. One Million Scenes for Autonomous Driving: ONCE Dataset[C]//Proceedings of the Neural Information Processing Systems Track on Datasets and Benchmarks. Red Hook: Curran Associates Inc., 2021: 1-13. |
| [36] | 李文礼, 李中峰, 李超, 等. 匝道合流交通场景下自动驾驶汽车安全性测试评价方法[J]. 汽车工程学报, 2024, 14(3): 354-362. |
| Li Wenli, Li Zhongfeng, Li Chao, et al. Research on Safety Testing and Evaluation Methods for Autonomous Vehicles in Ramp Merging Traffic Scenarios[J]. Chinese Journal of Automotive Engineering, 2024, 14(3): 354-362. | |
| [37] | 邢星宇, 吴旭阳, 刘力豪, 等. 基于目标优化的自动驾驶决策规划系统自动化测试方法[J]. 同济大学学报(自然科学版), 2021, 49(8): 1162-1169. |
| Xing Xingyu, Wu Xuyang, Liu Lihao, et al. Automatic Testing Method Based on Optimization Algorithms for the Decision and Planning System of Autonomous Vehicles[J]. Journal of Tongji University(Natural Science), 2021, 49(8): 1162-1169. | |
| [38] | 朱冰, 范天昕, 赵健, 等. 基于危险边界搜索的自动驾驶系统加速测试方法[J]. 吉林大学学报(工学版), 2023, 53(3): 704-712. |
| Zhu Bing, Fan Tianxin, Zhao Jian, et al. Accelerate Test Method of Automated Driving System Based on Hazardous Boundary Search[J]. Journal of Jilin University(Engineering and Technology Edition), 2023, 53(3): 704-712. | |
| [39] | 朱向雷, 吴志新, 张宇飞, 等. 基于场景降维及采样方法的场景库优化方法研究[J]. 汽车工程, 2023, 45(8): 1408-1416, 1427. |
| Zhu Xianglei, Wu Zhixin, Zhang Yufei, et al. Research on Scenario Library Optimization Method Based on Scenario Dimension Reduction and Sampling Method[J]. Automotive Engineering, 2023, 45(8): 1408-1416, 1427. | |
| [40] | Esenturk E, Wallace A G, Khastgir S, et al. Identification of Traffic Accident Patterns via Cluster Analysis and Test Scenario Development for Autonomous Vehicles[J]. IEEE Access, 2022, 10: 6660-6675. |
| [41] | Ge Jingwei, Zhang Jiawei, Zhang Yi, et al. Autonomous Vehicles Testing Considering Utility-based Operable Tasks[J]. Tsinghua Science and Technology, 2023, 28(5): 965-975. |
| [42] | Ghodsi Z, Hari S K S, Frosio I, et al. Generating and Characterizing Scenarios for Safety Testing of Autonomous Vehicles[C]//2021 IEEE Intelligent Vehicles Symposium (IV). Piscataway: IEEE, 2021: 157-164. |
| [43] | Zhou Rui, Liu Yuping, Zhang Kai, et al. Genetic Algorithm-based Challenging Scenarios Generation for Autonomous Vehicle Testing[J]. IEEE Journal of Radio Frequency Identification, 2022, 6: 928-933. |
| [44] | Zhu Bing, Zhang Peixing, Zhao Jian, et al. Hazardous Scenario Enhanced Generation for Automated Vehicle Testing Based on Optimization Searching Method[J]. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(7): 7321-7331. |
| [45] | Ge Jingwei, Zhang Jiawei, Chang Cheng, et al. Dynamic Testing for Autonomous Vehicles Using Random Quasi Monte Carlo[J]. IEEE Transactions on Intelligent Vehicles, 2024, 9(3): 4480-4492. |
| [46] | Jiang Zhengmin, Pan Wenbo, Liu Jia, et al. Efficient and Unbiased Safety Test for Autonomous Driving Systems[J]. IEEE Transactions on Intelligent Vehicles, 2023, 8(5): 3336-3348. |
| [47] | 任立海, 夏环, 蒋成约, 等. 基于交通事故数据的自动紧急制动系统测试场景构建[J]. 科学技术与工程, 2022, 22(24): 10737-10747. |
| Ren Lihai, Xia Huan, Jiang Chengyue, et al. Construction of Autonomous Emergency Braking System Test Scenarios Based on Traffic Accident Data[J]. Science Technology and Engineering, 2022, 22(24): 10737-10747. | |
| [48] | 舒红, 王志洋, 李石, 等. 无信号灯十字路口自动驾驶汽车直行关键场景构建[J]. 中国公路学报, 2022, 35(7): 328-338. |
| Shu Hong, Wang Zhiyang, Li Shi, et al. Construction of Critical Scenarios for Automated Vehicle Moving Straight at Intersection Without Traffic Lights[J]. China Journal of Highway and Transport, 2022, 35(7): 328-338. | |
| [49] | 谭正平, 车瑶栎, 肖凌云, 等. 面向自动驾驶的典型汽车与行人事故冲突场景研究[J]. 安全与环境学报, 2021, 21(4): 1573-1582. |
| Tan Zhengping, Che Yaoli, Xiao Lingyun, et al. Trace Analysis for the Typical Pre-crash Scenario Between Car Vehicle and Pedestrian Caused by the Automatic Driving[J]. Journal of Safety and Environment, 2021, 21(4): 1573-1582. | |
| [50] | Alnaser A J, Sargolzaei A, Akbaş M I. Autonomous Vehicles Scenario Testing Framework and Model of Computation: On Generation and Coverage[J]. IEEE Access, 2021, 9: 60617-60628. |
| [51] | Klischat Moritz, Althoff Matthias. Falsifying Motion Plans of Autonomous Vehicles with Abstractly Specified Traffic Scenarios[J]. IEEE Transactions on Intelligent Vehicles, 2023, 8(2): 1717-1730. |
| [52] | Machida Takashi, Shitaoka Kazuya. Test Coverage Index for ADAS/ADS Assessment Based on Various Real-world Information Points[J]. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(2): 1443-1455. |
| [53] | Zhang Xizhe, Khastgir S, Tiele Justin-Kiyoshi, et al. ODD and Behavior Based Scenario Generation for Automated Driving Systems[J]. IEEE Access, 2024, 12: 10652-10663. |
| [54] | 马依宁, 姜为, 吴靖宇, 等. 基于不同风格行驶模型的自动驾驶仿真测试自演绎场景研究[J]. 中国公路学报, 2023, 36(2): 216-228. |
| Ma Yining, Jiang Wei, Wu Jingyu, et al. Self-evolution Scenarios for Simulation Tests of Autonomous Vehicles Based on Different Models of Driving Styles[J]. China Journal of Highway and Transport, 2023, 36(2): 216-228. | |
| [55] | Li Xuan, Liu Enlu, Shen Tianyu, et al. ChatGPT-based Scenario Engineer: A New Framework on Scenario Generation for Trajectory Prediction[J]. IEEE Transactions on Intelligent Vehicles, 2024, 9(3): 4422-4431. |
| [56] | Xie Yuting, Guo Xianda, Wang Cong, et al. AdvDiffuser: Generating Adversarial Safety-critical Driving Scenarios via Guided Diffusion[C]//2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Piscataway: IEEE, 2024: 9983-9989. |
| [57] | Zhou Rui, Lin Ziqian, Zhang Guoqing, et al. Evaluating Autonomous Vehicle Safety Performance Through Analysis of Pre-crash Trajectories of Powered Two-wheelers[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(10): 13560-13572. |
| [58] | 李文礼, 李超, 张祎楠, 等. 面向自动驾驶测试场景生成的博弈神经网络算法[J]. 计算机工程与应用, 2024, 60(22): 335-346. |
| Li Wenli, Li Chao, Zhang Yinan, et al. Game Neural Network Algorithm for Generating Autonomous Driving Test Scenarios[J]. Computer Engineering and Applications, 2024, 60(22): 335-346. | |
| [59] | 赵祥模, 赵玉钰, 景首才, 等. 面向自动驾驶测试的危险变道场景泛化生成[J]. 自动化学报, 2023, 49(10): 2211-2223. |
| Zhao Xiangmo, Zhao Yuyu, Jing Shoucai, et al. Generalization Generation of Hazardous Lane-changing Scenarios for Automated Vehicle Testing[J]. Acta Automatica Sinica, 2023, 49(10): 2211-2223. | |
| [60] | Jing Shoucai, Zhao Yuyu, Zhao Xiangmo, et al. An Efficient High-risk Lane-changing Scenario Edge Cases Generation Method for Autonomous Vehicle Safety Testing[J]. IEEE Transactions on Intelligent Vehicles, 2025, 10(1): 459-471. |
| [61] | 朱宇, 徐志刚, 赵祥模, 等. 基于TsGAN的自动驾驶汽车高速公路变道切入测试场景自动生成算法[J]. 华南理工大学学报(自然科学版), 2024, 52(8): 76-88. |
| Zhu Yu, Xu Zhigang, Zhao Xiangmo, et al. TsGAN-based Automatic Generation Algorithm of Lane-change Cut-in Test Scenarios on Expressways for Autonomous Vehicles[J]. Journal of South China University of Technology(Natural Science Edition), 2024, 52(8): 76-88. | |
| [62] | Ge Jingwei, Zhang Jiawei, Chang Cheng, et al. Task-driven Controllable Scenario Generation Framework Based on AOG[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(6): 6186-6199. |
| [63] | Li Ao, Chen Shitao, Sun Liting, et al. SceGene: Bio-inspired Traffic Scenario Generation for Autonomous Driving Testing[J]. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(9): 14859-14874. |
| [64] | Yang Lan, Yuan Jiaqi, Zhao Xiangmo, et al. SceGAN: A Method for Generating Autonomous Vehicle Cut-in Scenarios on Highways Based on Deep Learning[J]. Journal of Intelligent and Connected Vehicles, 2023, 6(4): 264-274. |
| [65] | 陈曦, 赵津, 石晴, 等. 自动驾驶自动紧急制动关键场景测试案例提取研究[J]. 科学技术与工程, 2023, 23(34): 14660-14667. |
| Chen Xi, Zhao Jin, Shi Qing, et al. Test Cases Extraction for Autonomous Driving Autonomous Emergency Braking System Critical Scenarios[J]. Science Technology and Engineering, 2023, 23(34): 14660-14667. | |
| [66] | 李江坤, 邓伟文, 任秉韬, 等. 基于场景动力学和强化学习的自动驾驶边缘测试场景生成方法[J]. 汽车工程, 2022, 44(7): 976-986. |
| Li Jiangkun, Deng Weiwen, Ren Bingtao, et al. Automatic Driving Edge Scene Generation Method Based on Scene Dynamics and Reinforcement Learning[J]. Automotive Engineering, 2022, 44(7): 976-986. | |
| [67] | 石帅坤, 赵丹, 马明月, 等. 高速公路拥堵工况下自动驾驶车辆切入场景测试集构建与安全性评估[J]. 汽车技术, 2024(4): 7-14. |
| Shi Shuaikun, Zhao Dan, Ma Mingyue, et al. Construction Test Set and Risk Assessment of Cut-in Scenarios for Autonomous Vehicles Under Highway Congestion Conditions[J]. Automobile Technology, 2024(4): 7-14. | |
| [68] | 曾杰, 廖伟, 丁雪聪, 等. 基于预碰撞区域的切入场景自动化识别算法研究[J]. 西南大学学报(自然科学版), 2022, 44(3): 20-28. |
| Zeng Jie, Liao Wei, Ding Xuecong, et al. Research on Detection Algorithm for Automatic Identification of Cut-in Scene Based on Pre-crash Area[J]. Journal of Southwest University(Natural Science), 2022, 44(3): 20-28. | |
| [69] | 赵尧华, 陈延展, 郑亮, 等. 面向自动驾驶安全测试的碰撞场景构建与仿真分析[J]. 中国安全科学学报, 2024, 34(7): 211-218. |
| Zhao Yaohua, Chen Yanzhan, Zheng Liang, et al. Collision Scenario Construction and Simulation Analysis for Autonomous Driving Safety Testing[J]. China Safety Science Journal, 2024, 34(7): 211-218. | |
| [70] | Birchler Christian, Khatiri Sajad, Bosshard Bill, et al. Machine Learning-based Test Selection for Simulation-based Testing of Self-driving cars Software[J]. Empirical Software Engineering, 2023, 28(3): 71. |
| [71] | Duan Jianyu, Wang Zhen, Jing Xiaopu. Digital Twin Test Method with LTE-V2X for Autonomous Vehicle Safety Test[J]. IEEE Internet of Things Journal, 2024, 11(18): 30161-30171. |
| [72] | Feng Shuo, Yan Xintao, Sun Haowei, et al. Intelligent Driving Intelligence Test for Autonomous Vehicles with Naturalistic and Adversarial Environment[J]. Nature Communications, 2021, 12(1): 748. |
| [73] | Huai Yuqi, Almanee S, Chen Yuntianyi, et al. scenoRITA: Generating Diverse, Fully Mutable, Test Scenarios for Autonomous Vehicle Planning[J]. IEEE Transactions on Software Engineering, 2023, 49(10): 4656-4676. |
| [74] | Wei Zhiyuan, Huang Helai, Zhang Guoqing, et al. Interactive Critical Scenario Generation for Autonomous Vehicles Testing Based on In-depth Crash Data Using Reinforcement Learning[J]. IEEE Transactions on Intelligent Vehicles, 2025, 10(3): 1471-1482. |
| [75] | Zhou Yuan, Sun Yang, Tang Yun, et al. Specification-based Autonomous Driving System Testing[J]. IEEE Transactions on Software Engineering, 2023, 49(6): 3391-3410. |
| [76] | Zhu Yu, Wang Jian, Guo Xinyu, et al. Functional Testing Scenario Library Generation Framework for Connected and Automated Vehicles[J]. IEEE Transactions on Intelligent Transportation Systems, 2023, 24(9): 9712-9724. |
| [77] | Nesti Federico, Rossolini Giulio, Nair Saasha, et al. Evaluating the Robustness of Semantic Segmentation for Autonomous Driving Against Real-world Adversarial Patch Attacks[C]//2022 IEEE/CVF Winter Conference on Applications of Computer Vision (WACV). Piscataway: IEEE, 2022: 2826-2835. |
| [78] | Tian Haoxiang, Jiang Yan, Wu Guoquan, et al. MOSAT: Finding Safety Violations of Autonomous Driving Systems Using Multi-objective Genetic Algorithm[C]//Proceedings of the 30th ACM Joint European Software Engineering Conference and Symposium on the Foundations of Software Engineering. New York: ACM, 2022: 94-106. |
| [79] | Zhou Junjie, Wang Lin, Wang Xiaofan. Online Adaptive Generation of Critical Boundary Scenarios for Evaluation of Autonomous Vehicles[J]. IEEE Transactions on Intelligent Transportation Systems, 2023, 24(6): 6372-6388. |
| [80] | Hou Zhonglin, Wang Shouwei, Liu Hong, et al. Twin Scenarios Establishment for Autonomous Vehicle Digital Twin Empowered SOTIF Assessment[J]. IEEE Transactions on Intelligent Vehicles, 2024, 9(1): 1965-1976. |
| [81] | 吴昊, 王浩, 苏醒, 等. 自动驾驶系统中视觉感知模块的安全测试[J]. 计算机研究与发展, 2022, 59(5): 1133-1147. |
| Wu Hao, Wang Hao, Su Xing, et al. Security Testing of Visual Perception Module in Autonomous Driving System[J]. Journal of Computer Research and Development, 2022, 59(5): 1133-1147. | |
| [82] | 黄楷博, 邓伟文, 王莹, 等. 车载雷达关键场景的数据采集与标记方法[J]. 汽车工程, 2024, 46(12): 2257-2266. |
| Huang Kaibo, Deng Weiwen, Wang Ying, et al. Data Collection and Annotation Method for Radar on Some Key Scenarios[J]. Automotive Engineering, 2024, 46(12): 2257-2266. | |
| [83] | Singh Gurkirt, Akrigg S, Manuele Di Maio, et al. ROAD: The Road Event Awareness Dataset for Autonomous Driving[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2023, 45(1): 1036-1054. |
| [84] | Zhang Chi, Ma Xiaoning, Xu Liheng, et al. Worst Perception Scenario Search via Recurrent Neural Controller and K-reciprocal Re-ranking[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(6): 5612-5626. |
| [85] | Jiang Zhengmin, Liu Jia, Sun Peng, et al. Generation of Risky Scenarios for Testing Automated Driving Visual Perception Based on Causal Analysis[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(11): 15991-16004. |
| [86] | 董兆龙, 黄鹤, 李战一, 等. 自动驾驶样本库中多模态雨天场景融合构建方法[J]. 汽车工程, 2025, 47(2): 211-221. |
| Dong Zhaolong, Huang He, Li Zhanyi, et al. Construction Method for Multimodal Rainy Scene Fusion in Autonomous Driving Sample Library[J]. Automotive Engineering, 2025, 47(2): 211-221. |
| [1] | Zuo Zhen, Zhang Dong, Wang Zhi, Li Zhongxin. Exploration of Online-offline Integrated Practical Teaching Path Driven by Digital-intelligent Simulation [J]. Journal of System Simulation, 2026, 38(6): 1519-1527. |
| [2] | Jiang Yanji, Xiao Xingyi, Dong Hao, Yu Miao, Huang Jinshan, Liu Daqian, Fei Bowen. Detection Method for 3D Lanes Based on Graph Relationship Optimization Integrating Point and Lane Features [J]. Journal of System Simulation, 2026, 38(5): 1303-1319. |
| [3] | Wei Juhui, Zhang Xinyong, Wang Jiongqi, Zhou Xuanying, He Zhangming. Space-ground Integrated Collaborative Positioning Algorithm and Simulation for Trajectory Enhancement [J]. Journal of System Simulation, 2026, 38(4): 916-931. |
| [4] | Jiang Yanji, Zhang Yingyang, Dong Hao, Zhang Xiaoguang, Wang Meihui. Lane Detection in Dark Light Based on Instance Association [J]. Journal of System Simulation, 2025, 37(9): 2188-2199. |
| [5] | Wang Zili, Gao Yuntian, Yang Dezhen, Liu Yeyang, Ren Yi. Reliability Simulation Testing and Verification Technologies for Intelligent Systems: Frontiers, Progress, and Challenges [J]. Journal of System Simulation, 2025, 37(7): 1583-1606. |
| [6] | Wu Jianping, Li Guanzhou, Zhao Shuai, Huang Ling. Intelligent Transition of Automotive Industry Driven by Autonomous Driving Simulation Testing Technology [J]. Journal of System Simulation, 2025, 37(7): 1649-1664. |
| [7] | Wang Bingheng, Liu Tingrui, Yang Fan, Zhang Huan, Li Wei, Ma Ping, Yang Ming. Research on Requirements and Methods for Intelligent Assessment of Simulation Credibility [J]. Journal of System Simulation, 2025, 37(7): 1710-1722. |
| [8] | Li Shijie, Li Jialin, Liu Jialun, Xu Chengqi, Dong Zhilin. Research on Scenario-driven Virtual Simulation Test Method for Autonomous Escort Function of Habor Tugs [J]. Journal of System Simulation, 2025, 37(6): 1366-1375. |
| [9] | Gu Qiming, Chen Jiazhi, Cao Guoyan, Zhou Chenchu, Yu Dengxiu, Hu Haifeng. Research on a Credibility Information Management Method of Simulation Modeling [J]. Journal of System Simulation, 2025, 37(5): 1314-1328. |
| [10] | Ji Peng, Zhao Jinpeng, Jiang Limin. Design and Function Analysis of New Steering System for Autonomous Vehicle [J]. Journal of System Simulation, 2025, 37(1): 211-219. |
| [11] | Li Feixing, Xing Lining, Zhou Yu. Adversarial Simulation Testing Algorithm for SVM Based on Multi-objective Evolutionary Optimization [J]. Journal of System Simulation, 2024, 36(9): 2016-2031. |
| [12] | Wang Gaihua, Li Kehong, Long Qian, Yao Jingxuan, Zhu Bolun, Zhou Zhengshu, Pan Xuran. Object Detection of Lightweight Transformer Based on Knowledge Distillation [J]. Journal of System Simulation, 2024, 36(11): 2517-2527. |
| [13] | Lu Bin, Wang Minghan, Sun Yang, Yang Zhenyu. Global-local Fusion for Efficient 3D Object Detection [J]. Journal of System Simulation, 2024, 36(11): 2616-2630. |
| [14] | Li Jinwen, Wang Peng, Pan Youmei, Hui Xinyao. Adaptive Recognition Method of Capability Boundary Parameters for Unmanned Autonomous Systems [J]. Journal of System Simulation, 2024, 36(10): 2359-2370. |
| [15] | Su Tong, Wang Ying, Deng Qiyang, Li Zhaobin. Improved Foggy Pedestrian and Vehicle Detection Algorithm Based on YOLOv5 [J]. Journal of System Simulation, 2024, 36(10): 2413-2422. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
 http://www.china-simulation.com

