Journal of System Simulation ›› 2026, Vol. 38 ›› Issue (9): 2559-2573.doi: 10.16182/j.issn1004731x.joss.26-0061
• Papers • Previous Articles Next Articles
Li Tan1,2, Wu Congying1, Li Shenghua1, Chen Nanjiang1,2, Song Weining3,4, Gao Fangfang1,4, Wang Qi2,4, Lin Yanwen2,4, Yin Runmin2,4
Received:2026-01-20
Revised:2026-04-27
Online:2026-09-30
Published:2026-10-09
Contact:
Chen Nanjiang
CLC Number:
Li Tan, Wu Congying, Li Shenghua, Chen Nanjiang, Song Weining, Gao Fangfang, Wang Qi, Lin Yanwen, Yin Runmin. ACT Action Chunk Adaptive Optimization Method for Chemistry-oriented Robots[J]. Journal of System Simulation, 2026, 38(9): 2559-2573.
Fig. 1
ACT framework
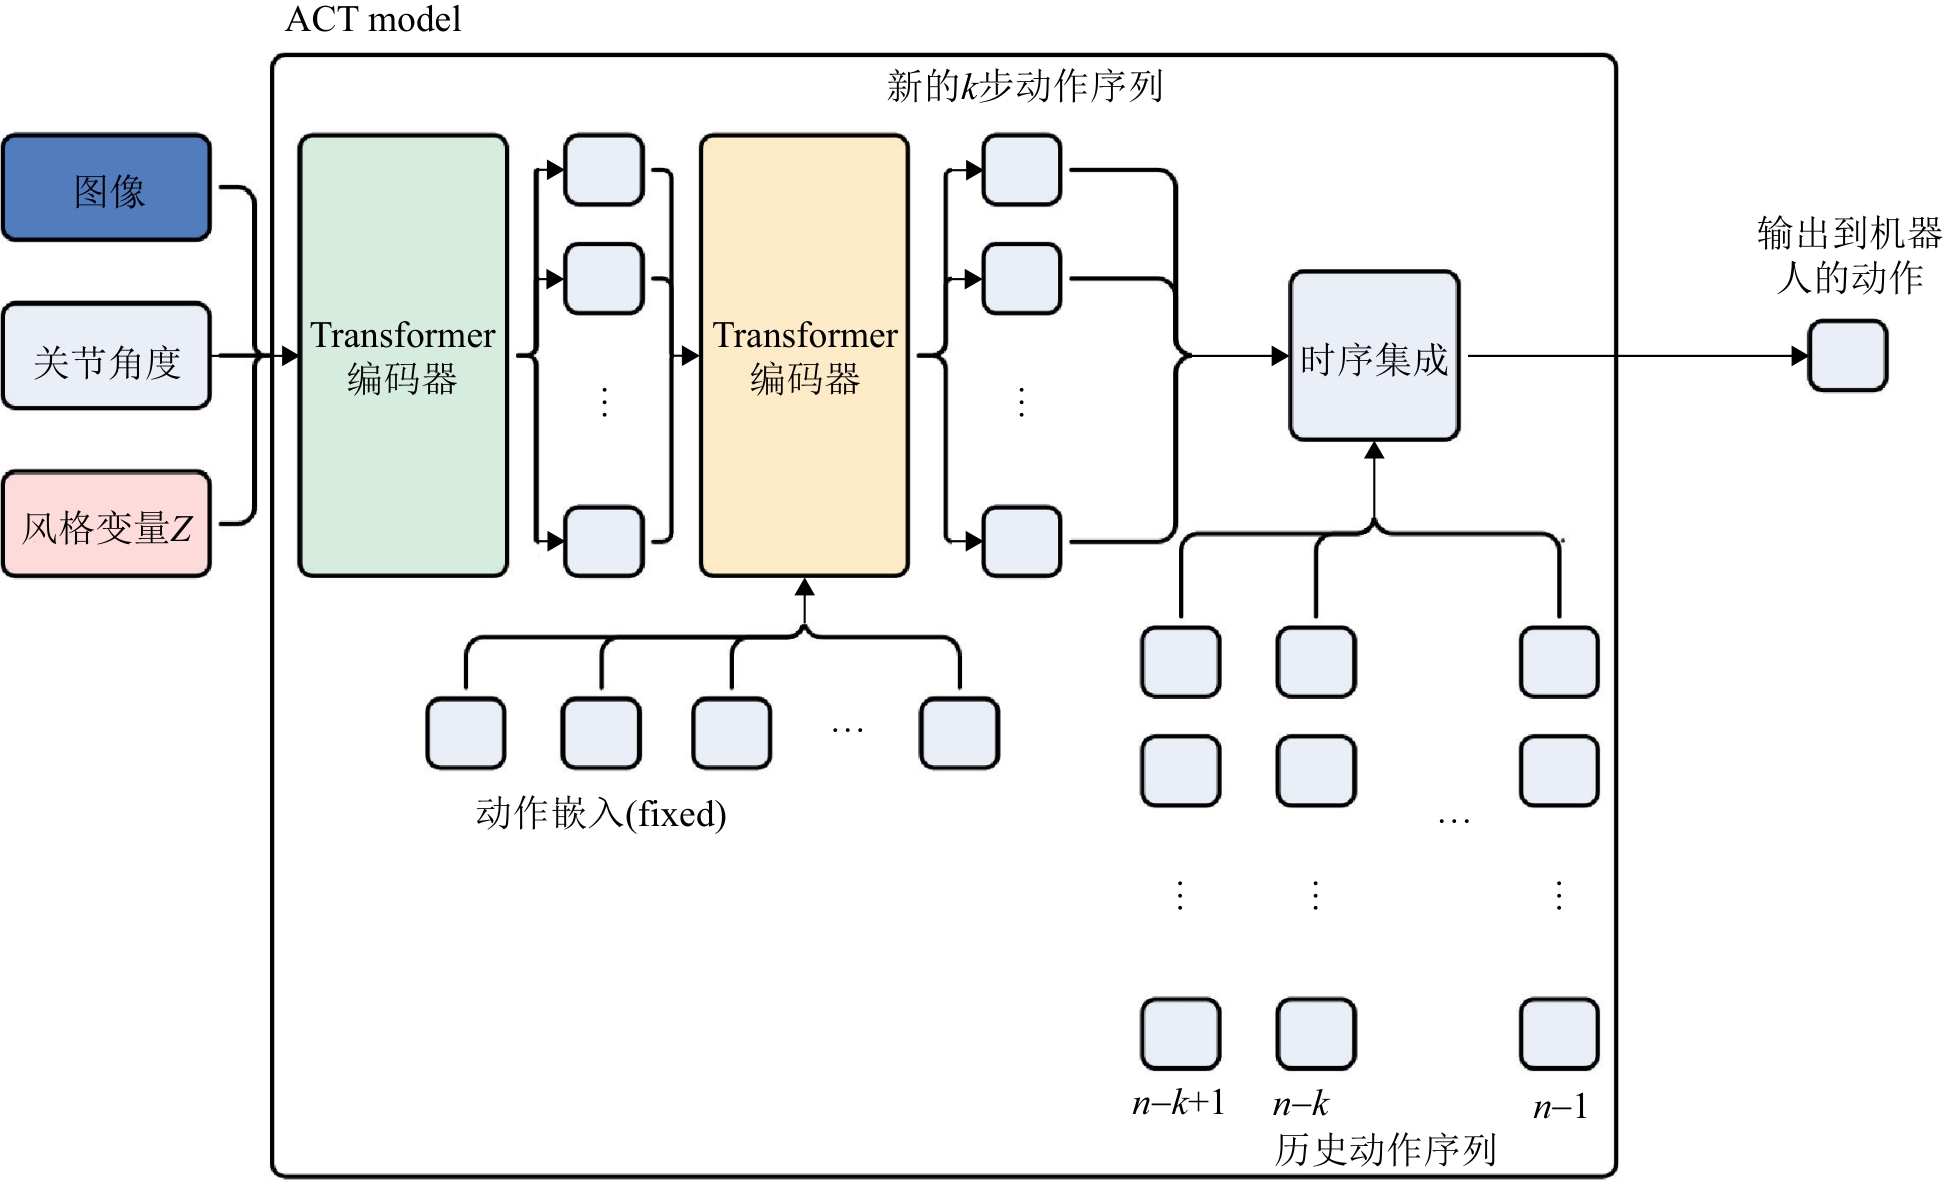
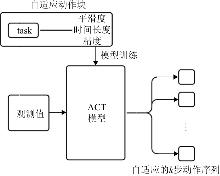
Fig. 2
Improvements to ACS-ACT
Table 1
Autocorrelation coefficient
| 时间长度/帧 | 自相关系数 |
|---|---|
| 585 | 71.51 |
| 769 | 75.67 |
| 865 | 75.92 |
| 1 073 | 80.61 |
| 1 275 | 88.86 |
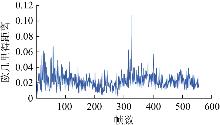
Fig. 3
Euclidean distance
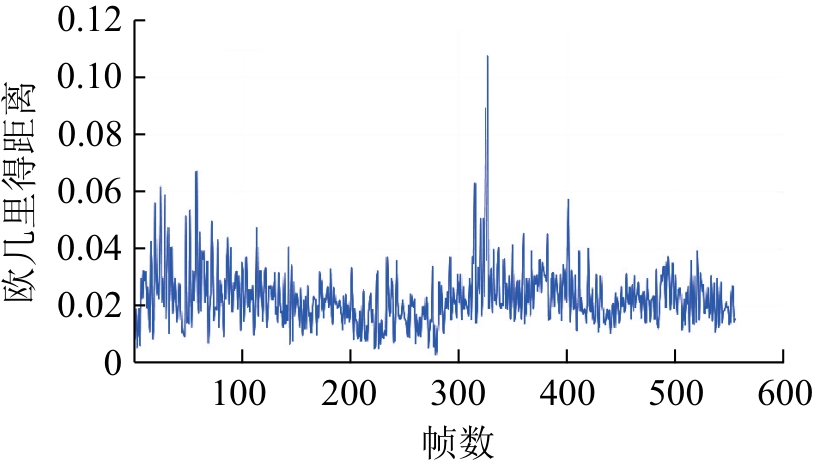
Fig. 4
Teleoperation simulation test
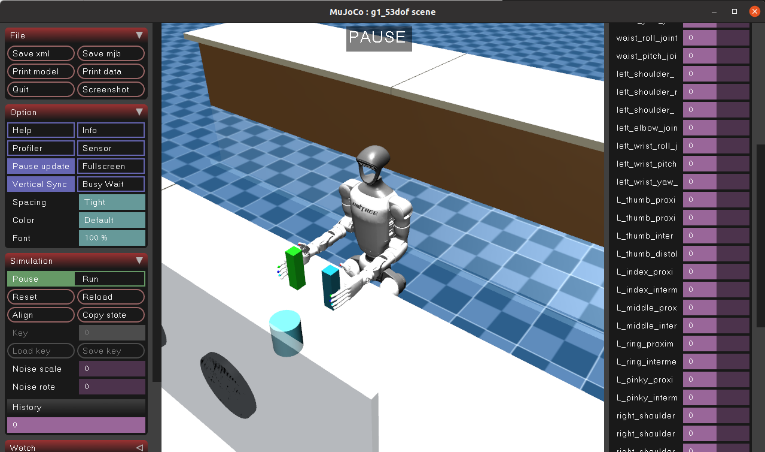
Table 2
Hardware parameters
| 机器人类型 | 末端执行 机构 | 自由度 | 相机 分辨率 | 相机 数量 |
|---|---|---|---|---|
| 单臂机器人 | 柔性夹爪 | 7 | 480×640 | 3 |
| 人形双臂 | 五指灵巧手 | 26 | 480×640 | 4 |
Fig. 5
Pipetting
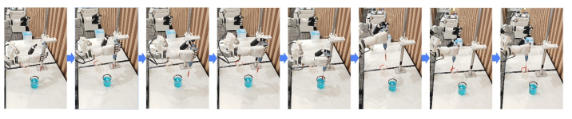
Fig. 6
Opening a volumetric flask
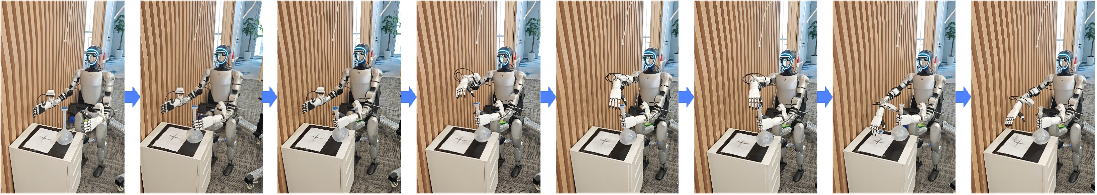
Fig. 7
Transferring reagent bottles
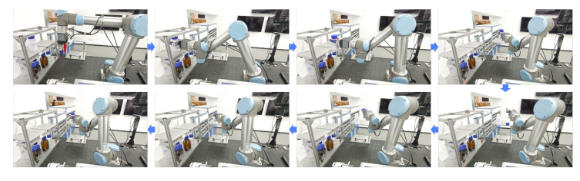
Fig. 8
Grasping and placing objects
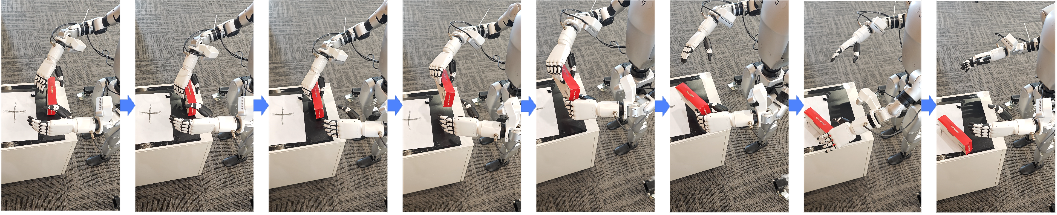
Table 3
Task feature quantification
| 任务 | 精度要求 | 平滑度特征 | 任务时长 | 块大小 |
|---|---|---|---|---|
| 物品抓取与放置 | 0.10 | 0.251 0 | 55 | 138 |
| 移液 | 0.67 | 1.331 5 | 32 | 64 |
| 打开容量瓶 | 0.20 | 0.458 1 | 25 | 57 |
| 转移试剂瓶 | 0.08 | 0.460 1 | 30 | 173 |
Table 4
Success rate comparison
| 任务 | 算法模型 | 总任务数 | 成功次数 | 成功率 |
|---|---|---|---|---|
| 物品抓取与放置 | ACS-ACT | 45 | 42 | 0.93 |
| ACT | 45 | 37 | 0.82 | |
| DP | 25 | 8 | 0.32 | |
| 移液 | ACS-ACT | 50 | 30 | 0.60 |
| ACT | 50 | 17 | 0.34 | |
| DP | 20 | 3 | 0.15 | |
| 打开容量瓶 | ACS-ACT | 50 | 44 | 0.88 |
| ACT | 50 | 33 | 0.66 | |
| 转移试剂瓶 | ACS-ACT | 60 | 59 | 0.98 |
| ACT | 60 | 52 | 0.87 |
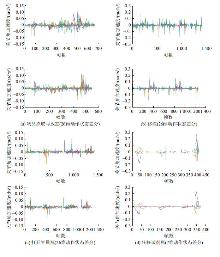
Fig. 9
Comparison of joint angle data before and after optimization
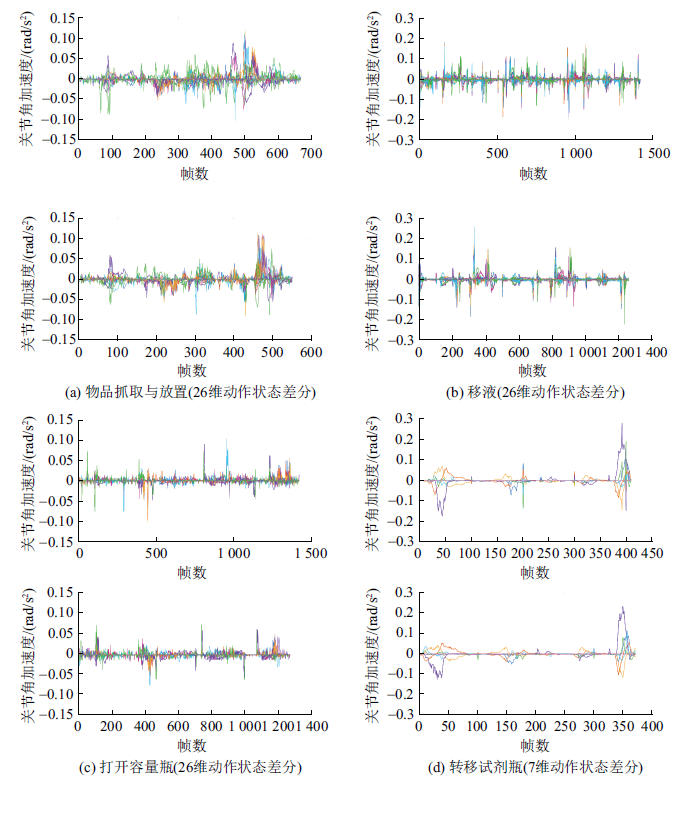
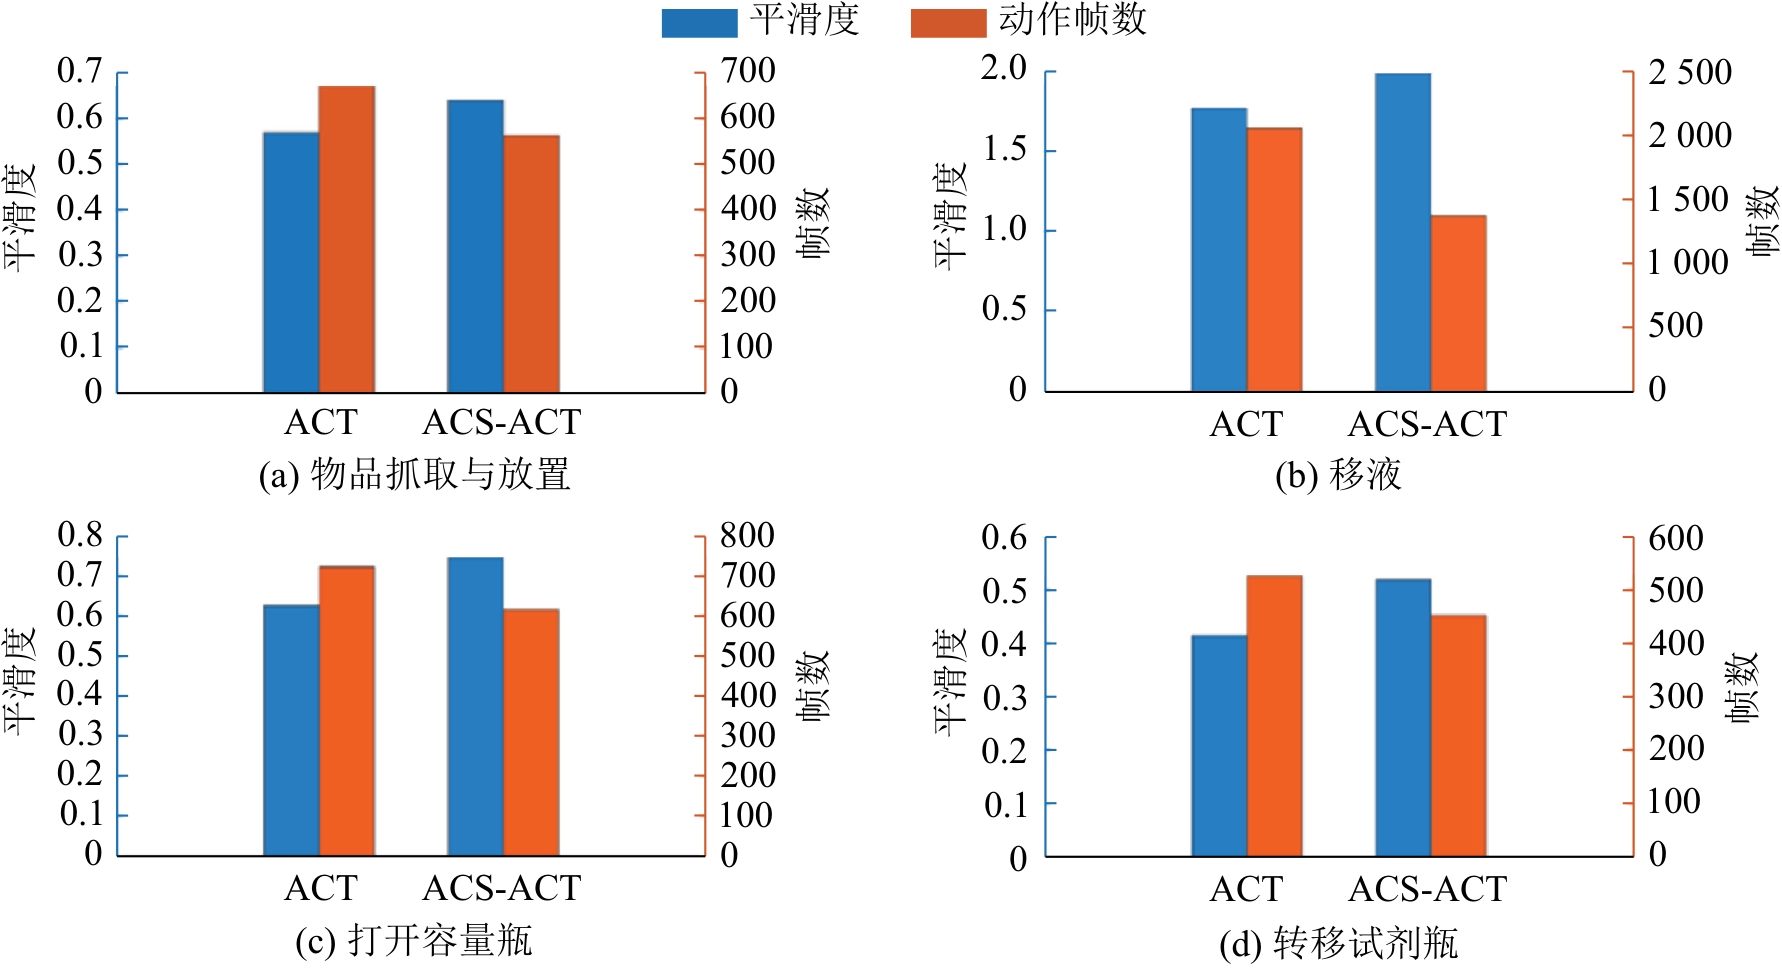
Fig. 10
Comparison of four experimental groups
| [1] | Yoshikawa Naruki, Skreta Marta, Darvish Kourosh, et al. Large Language Models for Chemistry Robotics[J]. Autonomous Robots, 2023, 47(8): 1057-1086. |
| [2] | Song Tao, Luo Man, Zhang Xiaolong, et al. A Multiagent-driven Robotic AI Chemist Enabling Autonomous Chemical Research on Demand[J]. Journal of the American Chemical Society, 2025, 147(15): 12534-12545. |
| [3] | 王可, 张辉, 曹意宏, 等. 面向医药生产的智能机器人及其关键技术研究综述[J]. 计算机集成制造系统, 2022, 28(7): 1981-1995. |
| Wang Ke, Zhang Hui, Cao Yihong, et al. Overview of Intelligent Robots and Key Technologies for Pharmaceutical Production[J]. Computer Integrated Manufacturing Systems, 2022, 28(7): 1981-1995. | |
| [4] | Zare Maryam, Kebria Parham M, Khosravi Abbas, et al. A Survey of Imitation Learning: Algorithms, Recent Developments, and Challenges[J]. IEEE Transactions on Cybernetics, 2024, 54(12): 7173-7186. |
| [5] | Zhang Tianhao, Mccarthy Z, Jow O, et al. Deep Imitation Learning for Complex Manipulation Tasks from Virtual Reality Teleoperation[C]//2018 IEEE International Conference on Robotics and Automation (ICRA). Piscataway: IEEE, 2018: 5628-5635. |
| [6] | Wang Chen, Fan Linxi, Sun Jiankai, et al. MimicPlay: Long-horizon Imitation Learning by Watching Human Play[EB/OL]. (2023-10-13) [2026-01-11]. . |
| [7] | Fu Zipeng, Zhao Qingqing, Wu Qi, et al. HumanPlus: Humanoid Shadowing and Imitation from Humans[EB/OL]. (2024-06-15) [2026-01-11]. . |
| [8] | He Tairan, Gao Jiawei, Xiao Wenli, et al. ASAP: Aligning Simulation and Real-world Physics for Learning Agile Humanoid Whole-body Skills[EB/OL]. (2025-04-26) [2026-01-11]. . |
| [9] | Lin Baihan. Behavioral Cloning and Imitation Learning[M]//Lin Baihan. Reinforcement Learning Methods in Speech and Language Technology. Cham: Springer Nature Switzerland, 2025: 63-67. |
| [10] | Xie Jun, Wang Zhicheng, Tan Jianwei, et al. Subconscious Robotic Imitation Learning[EB/OL]. (2024-12-29) [2026-01-11]. . |
| [11] | Li Zezeng, Chapin Alexandre, Xiang Enda, et al. Robotic Manipulation via Imitation Learning: Taxonomy, Evolution, Benchmark, and Challenges[EB/OL]. (2025-09-04) [2026-01-11]. . |
| [12] | Pomerleau D A. ALVINN: An Autonomous Land Vehicle in a Neural Network[C]//Advances in Neural Information Processing Systems. San Francisco: Morgan Kaufmann Publishers Inc., 1989: 305-313. |
| [13] | Foster D J, Block A, Misra D. Is Behavior Cloning All You Need? Understanding Horizon in Imitation Learning[C]//38th Conference on Neural Information Processing Systems (NeurIPS 2024). Red Hook: Curran Associates Inc., 2024: 120602-120666. |
| [14] | Zhao T Z, Kumar V, Levine S, et al. Learning Fine-grained Bimanual Manipulation with Low-Cost Hardware[EB/OL]. (2023-04-23) [2026-01-11]. . |
| [15] | Kim Heecheol, Ohmura Yoshiyuki, Kuniyoshi Yasuo. Robot Peels Banana with Goal-conditioned Dual-action Deep Imitation Learning[EB/OL]. (2022-03-18) [2026-01-11]. . |
| [16] | Paradis S, Hwang M, Thananjeyan B, et al. Intermittent Visual Servoing: Efficiently Learning Policies Robust to Instrument Changes for High-precision Surgical Manipulation[C]//2021 IEEE International Conference on Robotics and Automation (ICRA). Piscataway: IEEE, 2021: 7166-7173. |
| [17] | Zhao Haitao, Chen Wei, Huang Hao, et al. A Robotic Platform for the Synthesis of Colloidal Nanocrystals[J]. Nature Synthesis, 2023, 2(6): 505-514. |
| [18] | Jiang Ying, Fakhruldeen H, Pizzuto G, et al. Autonomous Biomimetic Solid Dispensing Using a Dual-arm Robotic Manipulator[J]. Digital Discovery, 2023, 2(6): 1733-1744. |
| [19] | Burger B, Maffettone P M, Gusev V V, et al. A Mobile Robotic Chemist[J]. Nature, 2020, 583(7815): 237-241. |
| [20] | Zhu Qing, Zhang Fei, Huang Yan, et al. An All-round AI-chemist with a Scientific Mind[J]. National Science Review, 2022, 9(10): nwac190. |
| [21] | Guo Taicheng, Chen Xiuying, Wang Yaqi, et al. Large Language Model Based Multi-agents: A Survey of Progress and Challenges[EB/OL]. (2024-04-19) [2026-01-11]. . |
| [22] | Pari J, Shafiullah N M, Arunachalam S P, et al. The Surprising Effectiveness of Representation Learning for Visual Imitation[EB/OL]. (2021-12-06) [2026-01-11]. . |
| [23] | Rahmatizadeh R, Abolghasemi P, Bölöni Ladislau, et al. Vision-based Multi-task Manipulation for Inexpensive Robots Using End-to-end Learning from Demonstration[C]//2018 IEEE International Conference on Robotics and Automation (ICRA). Piscataway: IEEE, 2018: 3758-3765. |
| [24] | Liang Wensheng, Xie Jun, Wang Zhicheng, et al. Constrained Behavior Cloning for Robotic Learning[EB/OL]. (2024-08-20) [2026-01-11]. . |
| [25] | 贾政轩, 林廷宇, 肖莹莹, 等. 基于强化学习的最优控制指令模仿生成方法[J]. 系统仿真学报, 2023, 35(11): 2410-2418. |
| Jia Zhengxuan, Lin Tingyu, Xiao Yingying, et al. Imitative Generation of Optimal Guidance Law Based on Reinforcement Learning[J]. Journal of System Simulation, 2023, 35(11): 2410-2418. | |
| [26] | 顾俊, 程文, 林子昂, 等. 智能驾驶汽车模仿学习技术研究综述[J]. 无人系统技术, 2025, 8(6): 100-113. |
| Gu Jun, Cheng Wen, Lin Ziang, et al. A Review of Imitation Learning Technology for Intelligent Driving Cars[J]. Unmanned Systems Technology, 2025, 8(6): 100-113. | |
| [27] | Zhang Tengteng, Mo Hongwei. Reinforcement Learning for Robot Research: A Comprehensive Review and Open Issues[J]. International Journal of Advanced Robotic Systems, 2021, 18(3): 17298814211007305. |
| [28] | Black K, Brown N, Driess D, et al. π0 : A Vision-language-action Flow Model for General Robot Control[EB/OL]. (2026-01-08) [2026-01-11]. . |
| [29] | Chi Cheng, Xu Zhenjia, Feng Siyuan, et al. Diffusion Policy: Visuomotor Policy Learning via Action Diffusion[J]. International Journal of Robotics Research, 2025, 44(10/11): 1684-1704. |
| [30] | Yanjie Ze, Zhang Gu, Zhang Kangning, et al. 3D Diffusion Policy: Generalizable Visuomotor Policy Learning via Simple 3D Representations[EB/OL]. (2024-09-27) [2026-01-11]. . |
| [31] | Intelligence P, Black K, Brown N, et al. π0 5: A Vision-language-action Model with Open-world Generalization[EB/OL]. (2026-01-08) [2026-01-11]. . |
| [32] | Kang Bingyi, Ma Xiao, Du Chao, et al. Efficient Diffusion Policies for Offline Reinforcement Learning[C]//Proceedings of the 37th International Conference on Neural Information Processing Systems. Red Hook: Curran Associates Inc., 2023: 67195-67212. |
| [33] | Janner M, Li Qiyang, Levine S. Offline Reinforcement Learning as One Big Sequence Modeling Problem[C]//Proceedings of the 35th International Conference on Neural Information Processing Systems. Red Hook: Curran Associates Inc., 2021: 1273-1286. |
| [34] | Chen Lili, Lu K, Rajeswaran A, et al. Decision Transformer: Reinforcement Learning via Sequence Modeling[C]//Proceedings of the 35th International Conference on Neural Information Processing Systems. Red Hook: Curran Associates Inc., 2021: 15084-15097. |
| [35] | Reed Scott, Zolna Konrad, Parisotto Emilio, et al. A Generalist Agent[EB/OL]. (2022-11-11) [2026-01-11]. . |
| [36] | Buamanee Thanpimon, Kobayashi Masato, Uranishi Yuki, et al. Bi-ACT: Bilateral Control-based Imitation Learning via Action Chunking with Transformer[C]//2024 IEEE International Conference on Advanced Intelligent Mechatronics (AIM). Piscataway: IEEE, 2024: 410-415. |
| [37] | Lee A, Chuang I, Chen Lingyuan, et al. InterACT: Inter-dependency Aware Action Chunking with Hierarchical Attention Transformers for Bimanual Manipulation[EB/OL]. (2024-10-16) [2026-01-11]. . |
| [38] | Liu Yuejiang, Hamid J I, Xie A, et al. Bidirectional Decoding: Improving Action Chunking via Guided Test-time Sampling[EB/OL]. (2025-04-25) [2026-01-11]. . |
| [39] | Zhang Xinyu, Liu Yuhan, Chang Haonan, et al. Autoregressive Action Sequence Learning for Robotic Manipulation[J]. IEEE Robotics and Automation Letters, 2025, 10(5): 4898-4905. |
| [40] | Chaudhary S, Ravindran B. Smooth Imitation Learning via Smooth Costs and Smooth Policies[C]//Proceedings of the 5th Joint International Conference on Data Science & Management of Data (9th ACM IKDD CODS and 27th COMAD). New York: ACM, 2022: 63-71. |
| [41] | Kim Heecheol, Ohmura Yoshiyuki, Kuniyoshi Yasuo. Gaze-based Dual Resolution Deep Imitation Learning for High-precision Dexterous Robot Manipulation[J]. IEEE Robotics and Automation Letters, 2021, 6(2): 1630-1637. |
| [42] | Oh Hanbit, Matsubara Takamitsu. Leveraging Demonstrator-perceived Precision for Safe Interactive Imitation Learning of Clearance-limited Tasks[J]. IEEE Robotics and Automation Letters, 2024, 9(4): 3387-3394. |
| [43] | Hu Yingbai, Abu-Dakka Fares J, Chen Fei, et al. Fusion Dynamical Systems with Machine Learning in Imitation Learning: A Comprehensive Overview[J]. Information Fusion, 2024, 108: 102379. |
| [44] | Qin Yuzhe, Yang Wei, Huang Binghao, et al. AnyTeleop: A General Vision-based Dexterous Robot Arm-hand Teleoperation System[EB/OL]. (2024-05-16) [2026-01-11]. . |
| [1] | Zhou Zicong, Zeng Junjie, Hu Yue, Zhu Zhengqiu, Yin Quanjun. Multi-agent Reinforcement Learning Method for Wargame Simulation Based on Suboptimal Demonstration Guidance [J]. Journal of System Simulation, 2026, 38(5): 1277-1289. |
| [2] | Sun Yifeng, Li Zhi, Wu Jiang, Wang Yubin. Research on Learnable Wargame Agent Driven by Battle Scheme [J]. Journal of System Simulation, 2024, 36(7): 1525-1535. |
| [3] | Wang Qiaochu, Ding Yan, Liang Chuanzhi, Zhang Haozheng, Huang Chen. Research on Scheduling Strategies Simulation for Building Air-conditioning Systems Based on Transfer Imitation Learning [J]. Journal of System Simulation, 2024, 36(12): 2884-2893. |
| [4] | Jia Zhengxuan, Lin Tingyu, Xiao Yingying, Shi Guoqiang, Wang Hao, Zeng Bi, Ou Yiming, Zhao Pengpeng. Imitative Generation of Optimal Guidance Law Based on Reinforcement Learning [J]. Journal of System Simulation, 2023, 35(11): 2410-2418. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
 http://www.china-simulation.com

