Journal of System Simulation ›› 2026, Vol. 38 ›› Issue (8): 2324-2337.doi: 10.16182/j.issn1004731x.joss.25-1012
• Papers • Previous Articles
Chen Shiyu1, Chen Xinmin2, Hu Xionglong2, Wang Heng2, Han Yepeng2, Chen Jiajie2
Received:2025-10-20
Revised:2025-11-28
Online:2026-08-28
Published:2026-08-31
Contact:
Chen Xinmin
CLC Number:
Chen Shiyu, Chen Xinmin, Hu Xionglong, Wang Heng, Han Yepeng, Chen Jiajie. Sensorless Control of PMSM Based on an Improved Super-twisting Sliding-mode Observer[J]. Journal of System Simulation, 2026, 38(8): 2324-2337.
Fig. 1
Block diagram of IAST-SMO control structure
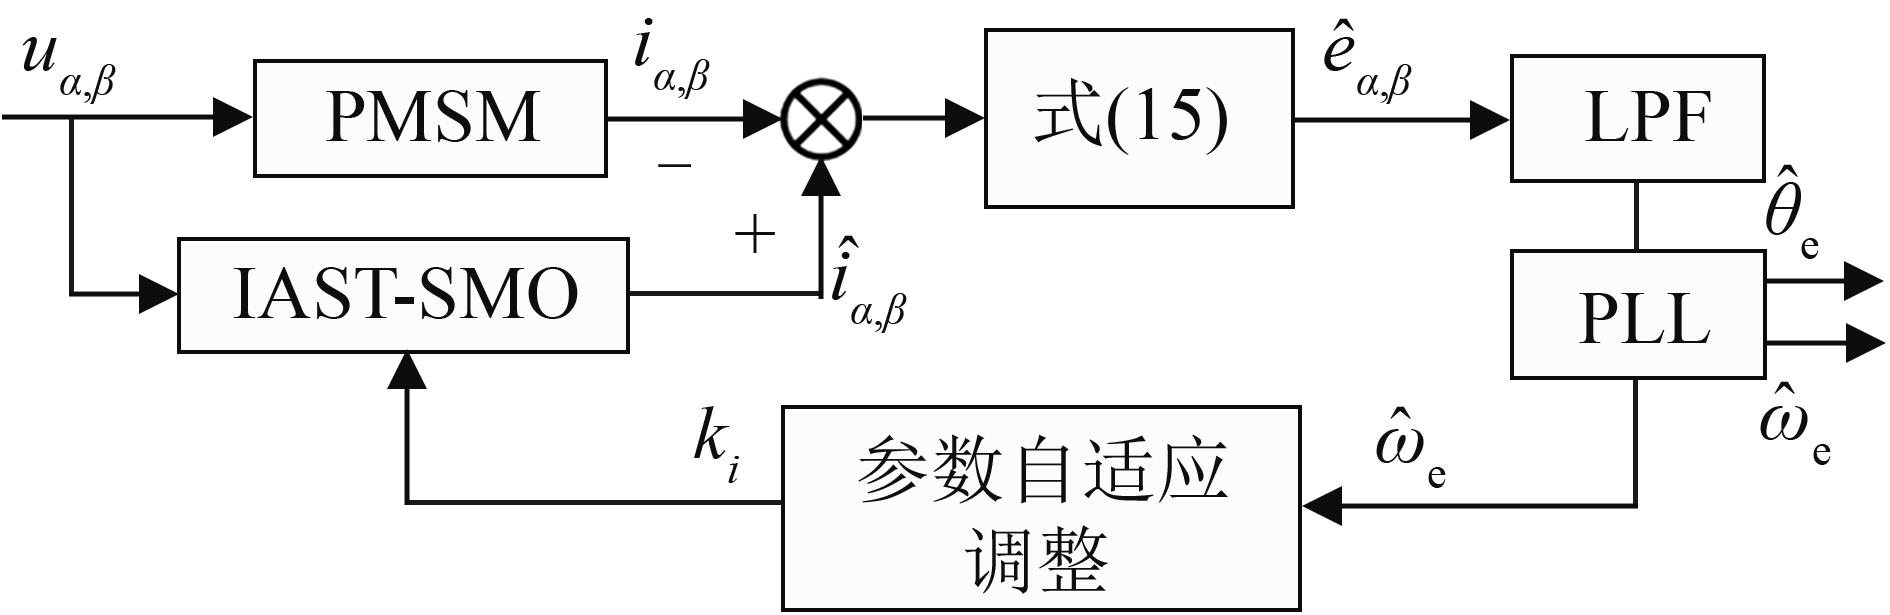
Fig. 2
Bode diagram of frequency-adaptive complex-coefficient filter
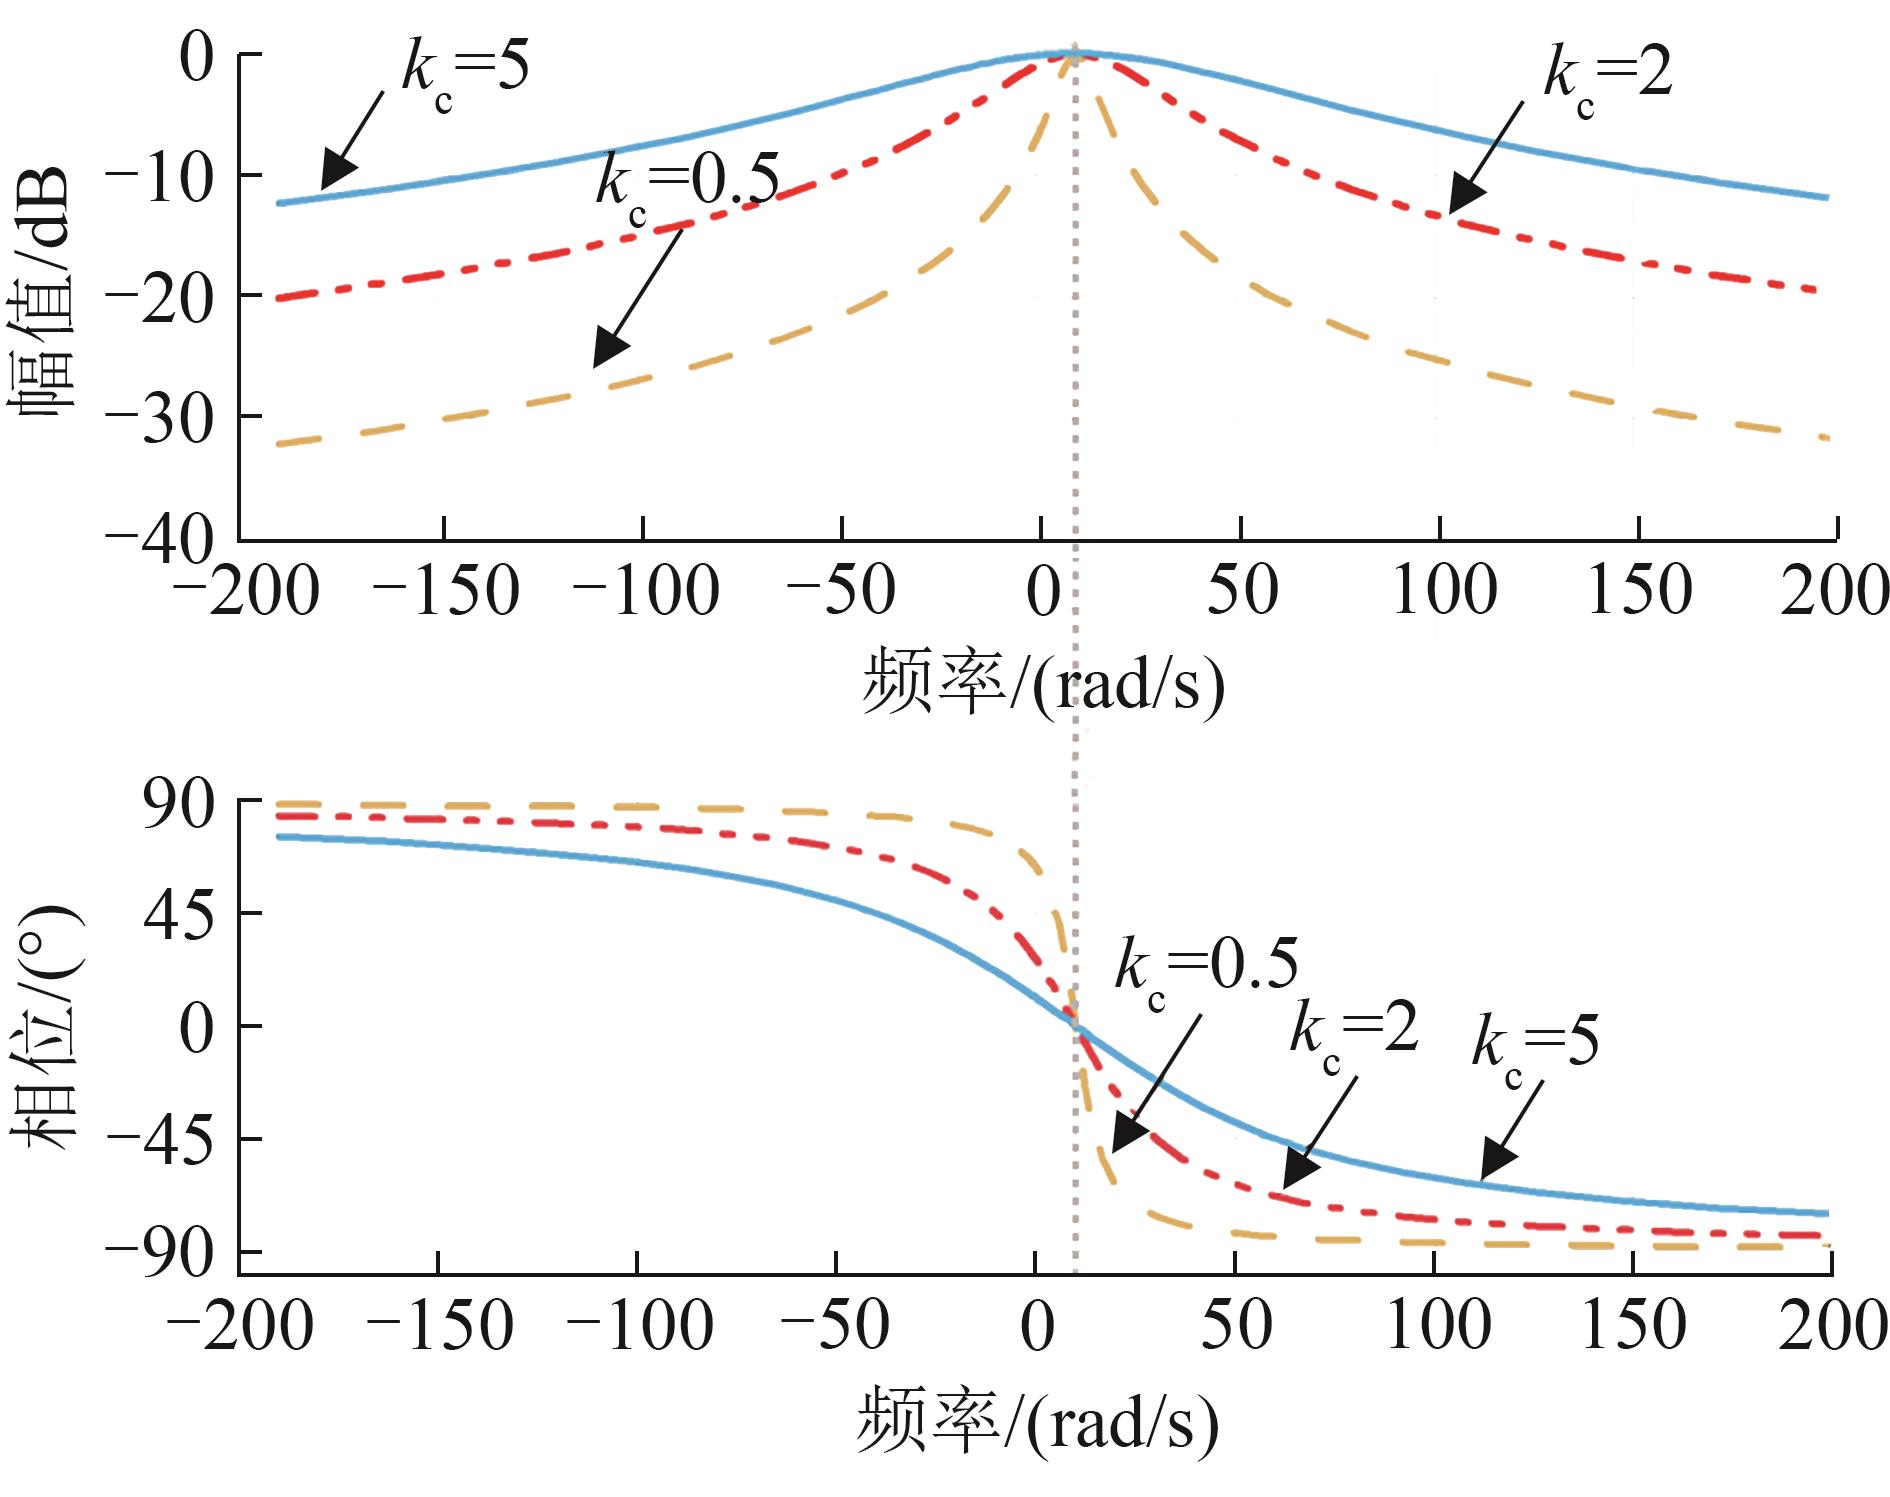
Fig. 3
Flowchart of variable-gain algorithm
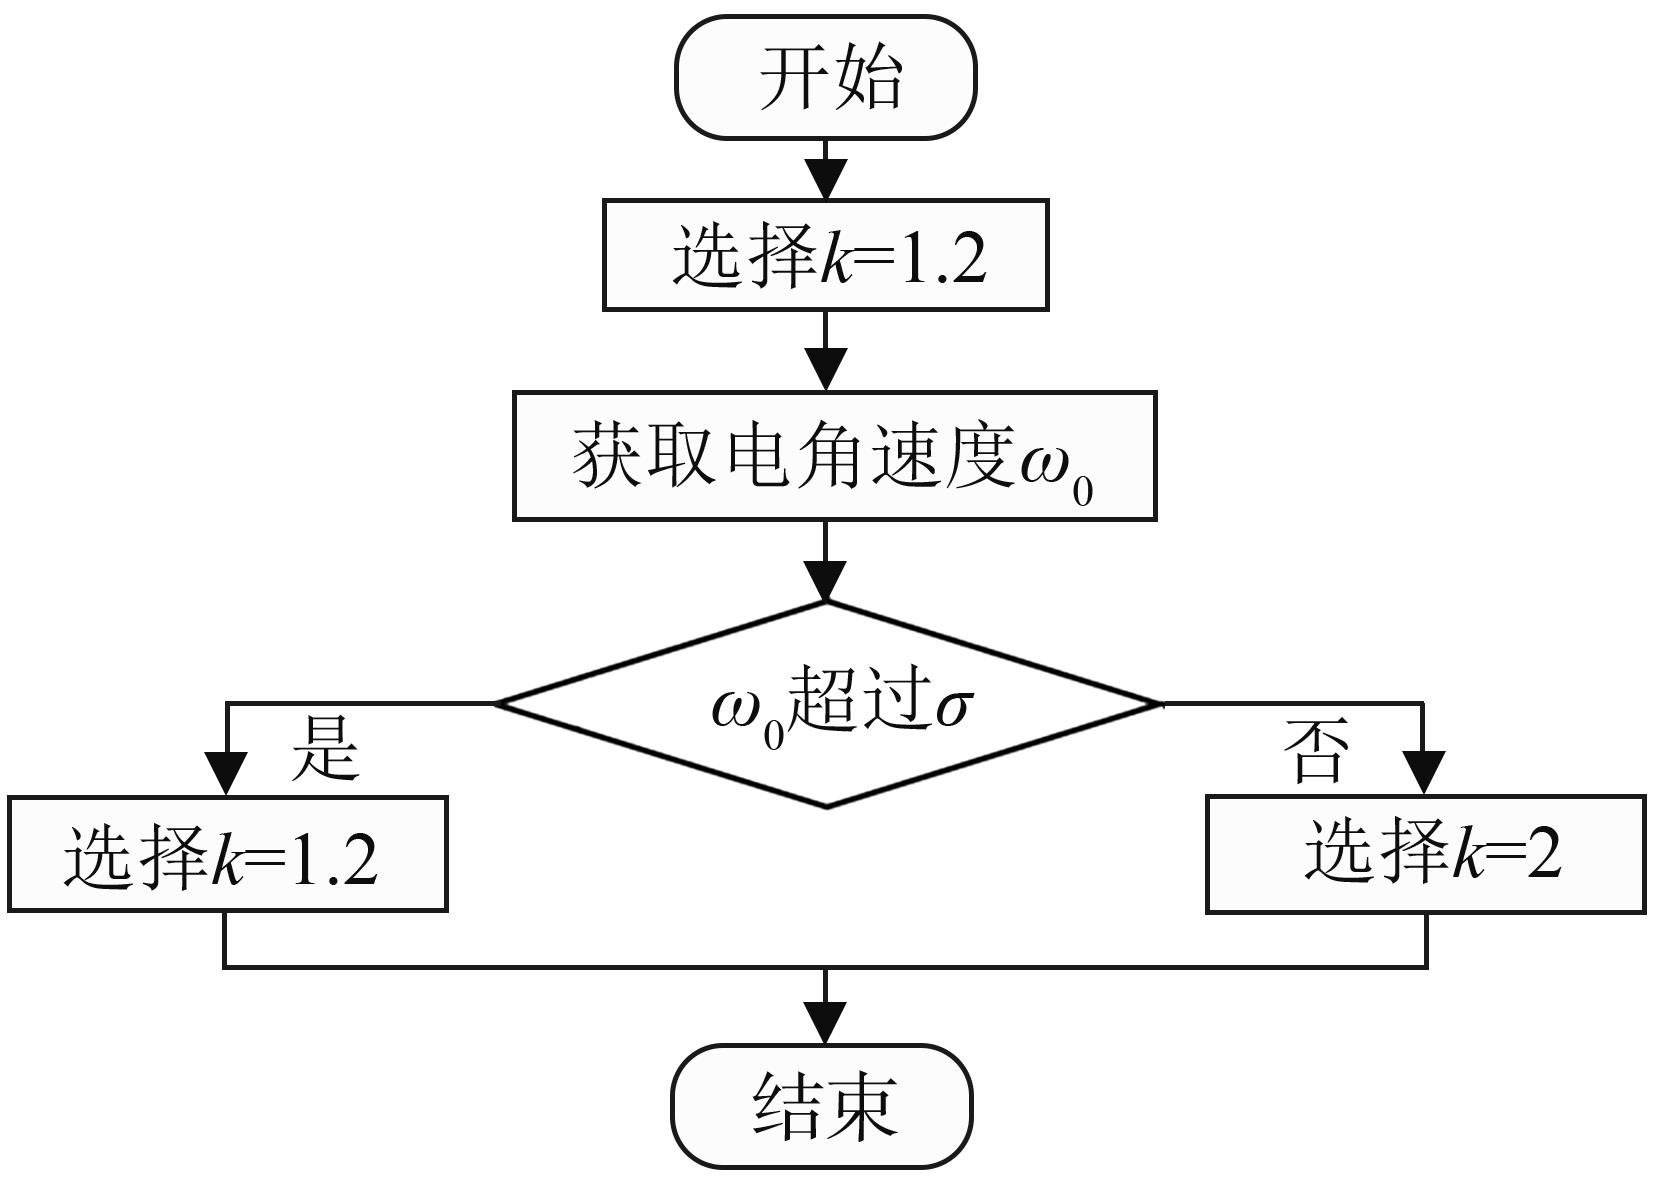
Fig. 4
Block diagram of VG-ACCF structure
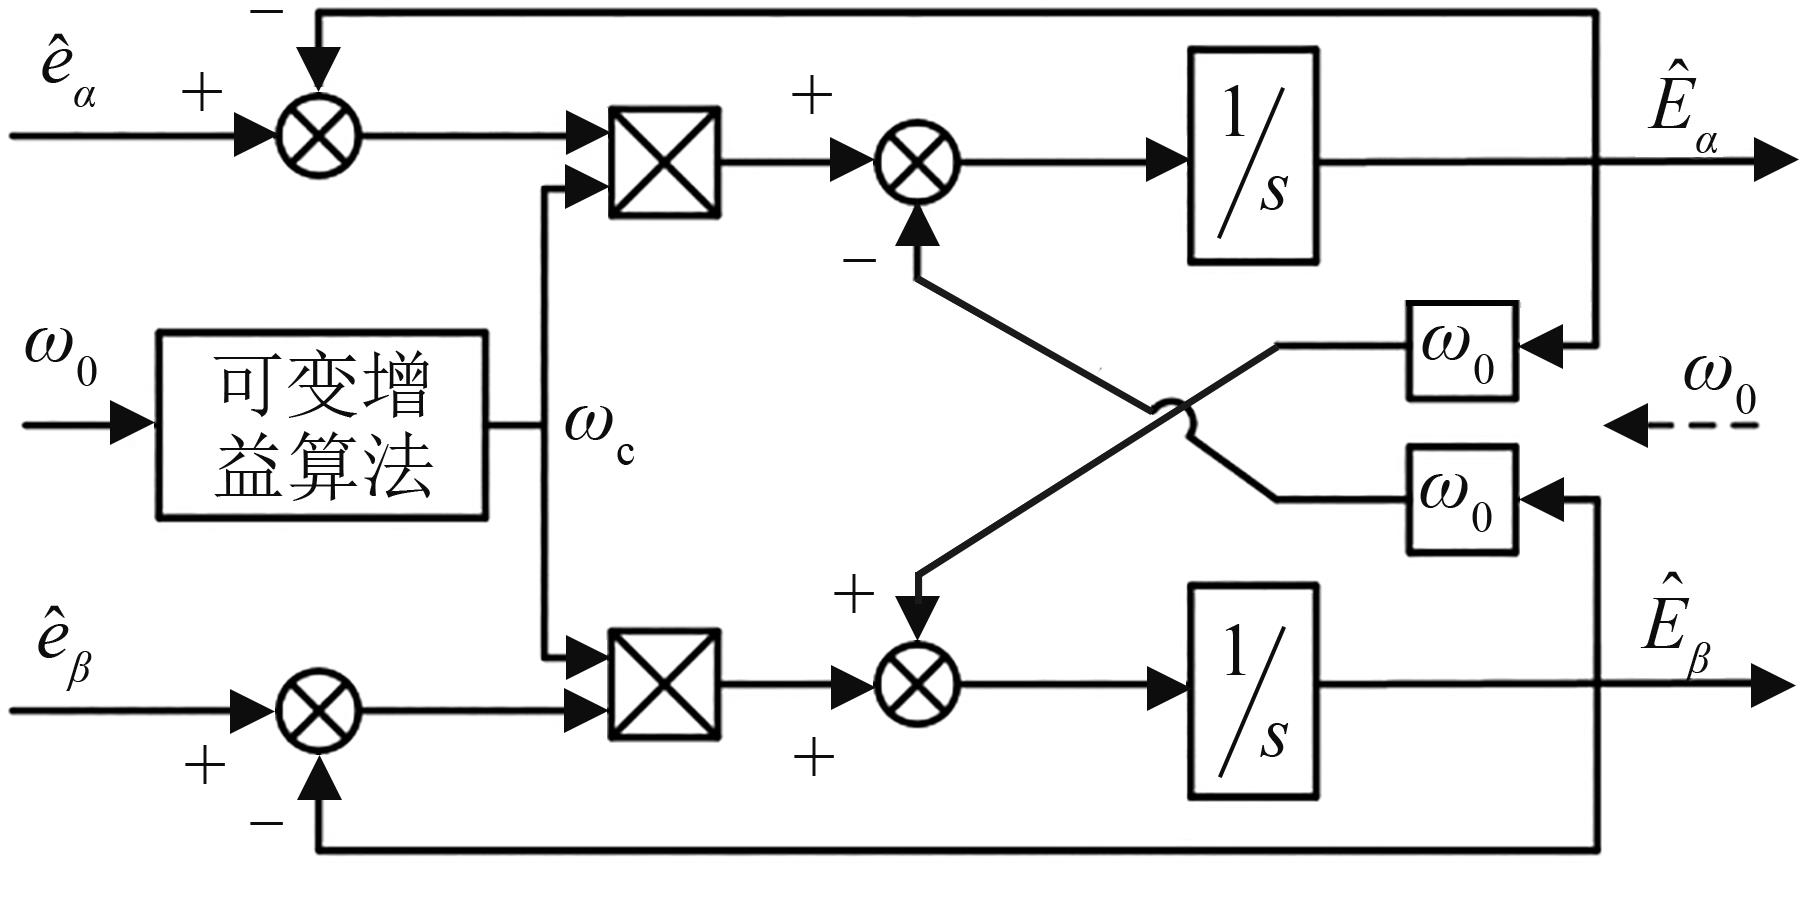
Fig. 5
Block diagram of PLL structure
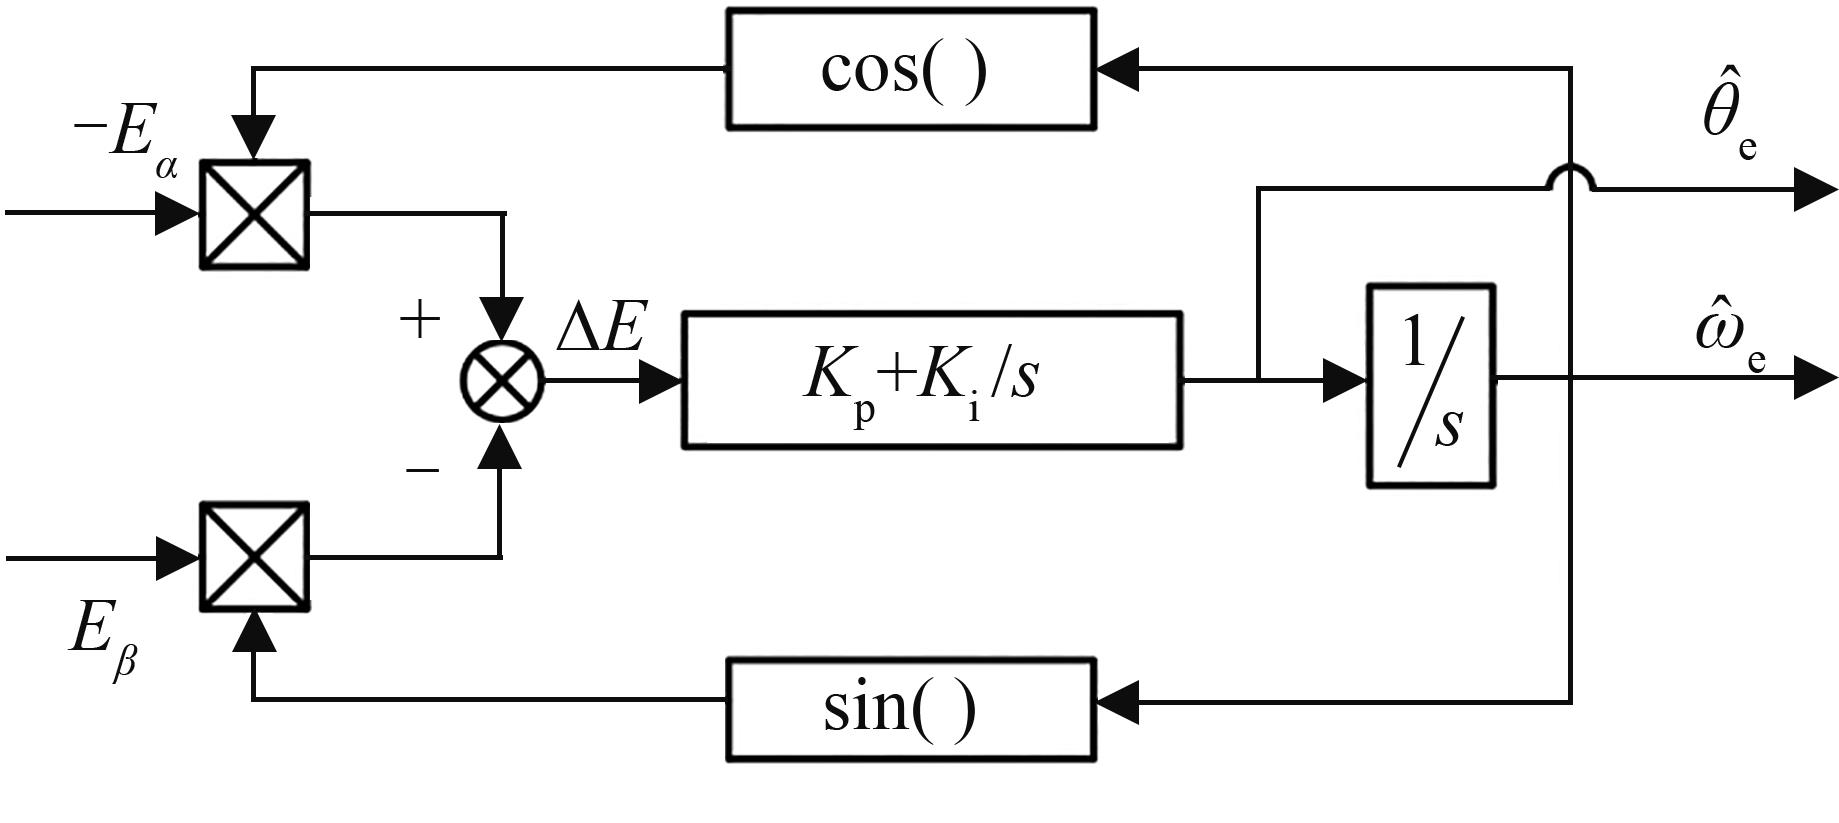
Fig. 6
Block diagram of rotor information extraction structure
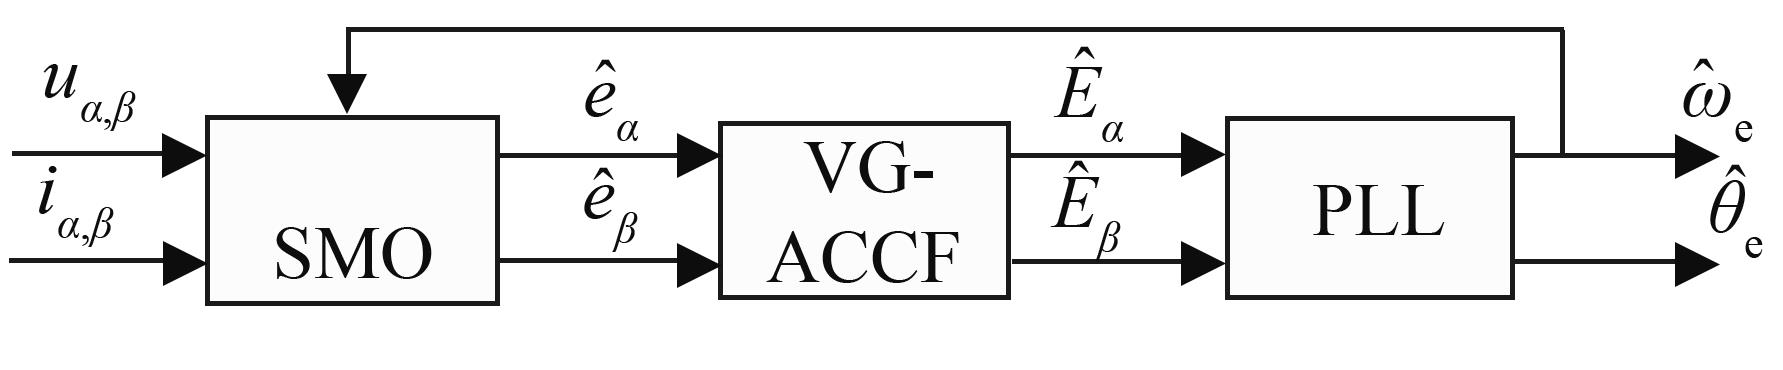
Fig. 7
Block diagram of PMSM control system
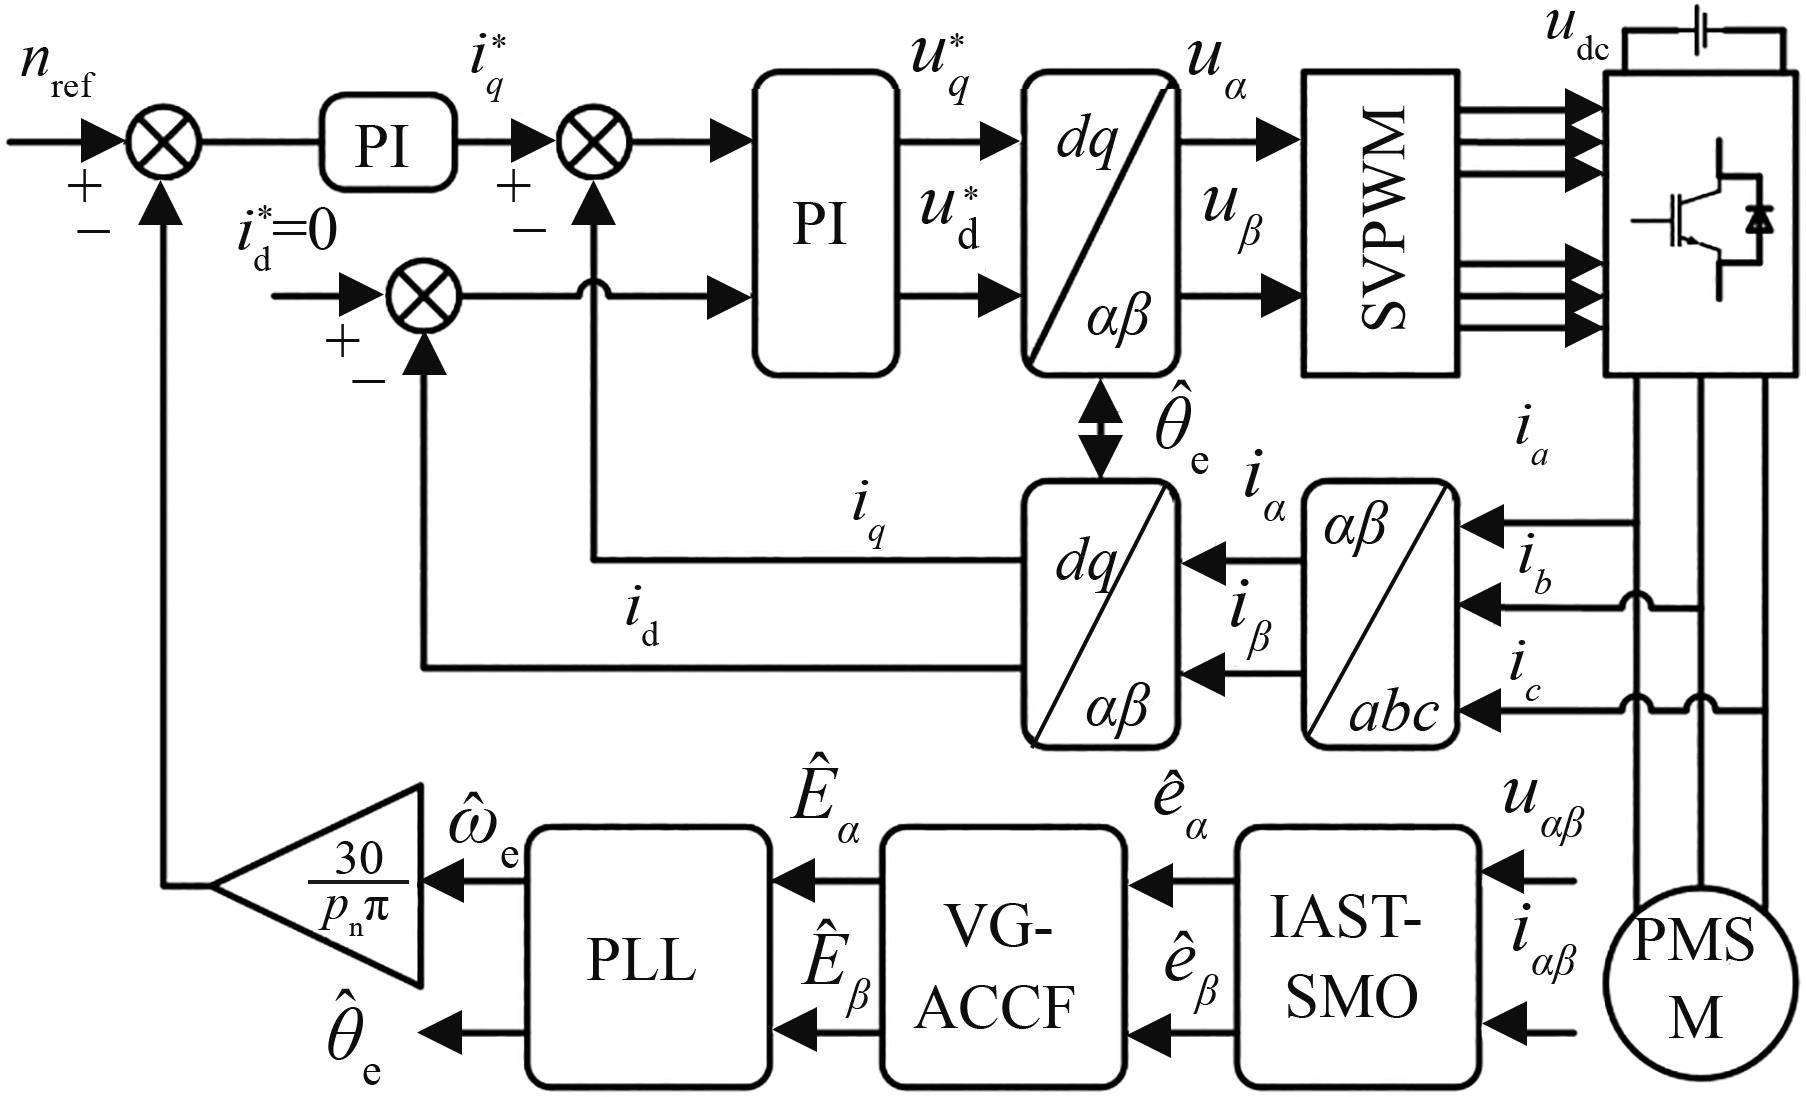
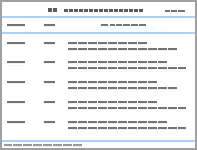
Table 1
Main parameters of PMSM
| 主要参数 | 数值 |
|---|---|
| 极对数 | 4 |
| 定子电阻 | 0.045 |
| 定子电感 | 0.235 |
| 磁链 | 0.048 517 |
| 转动惯量 | 0.003 4 |
| 阻尼系数 | 0 |
Table 2
Controller parameters
| 控制方式 | 参数 |
|---|---|
| STA-SMO | |
| IAST-SMO | |
| VG-ACCF | |
| PLL |
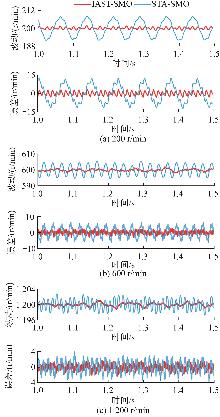
Fig. 8
Comparison of rotor speeds before filtering
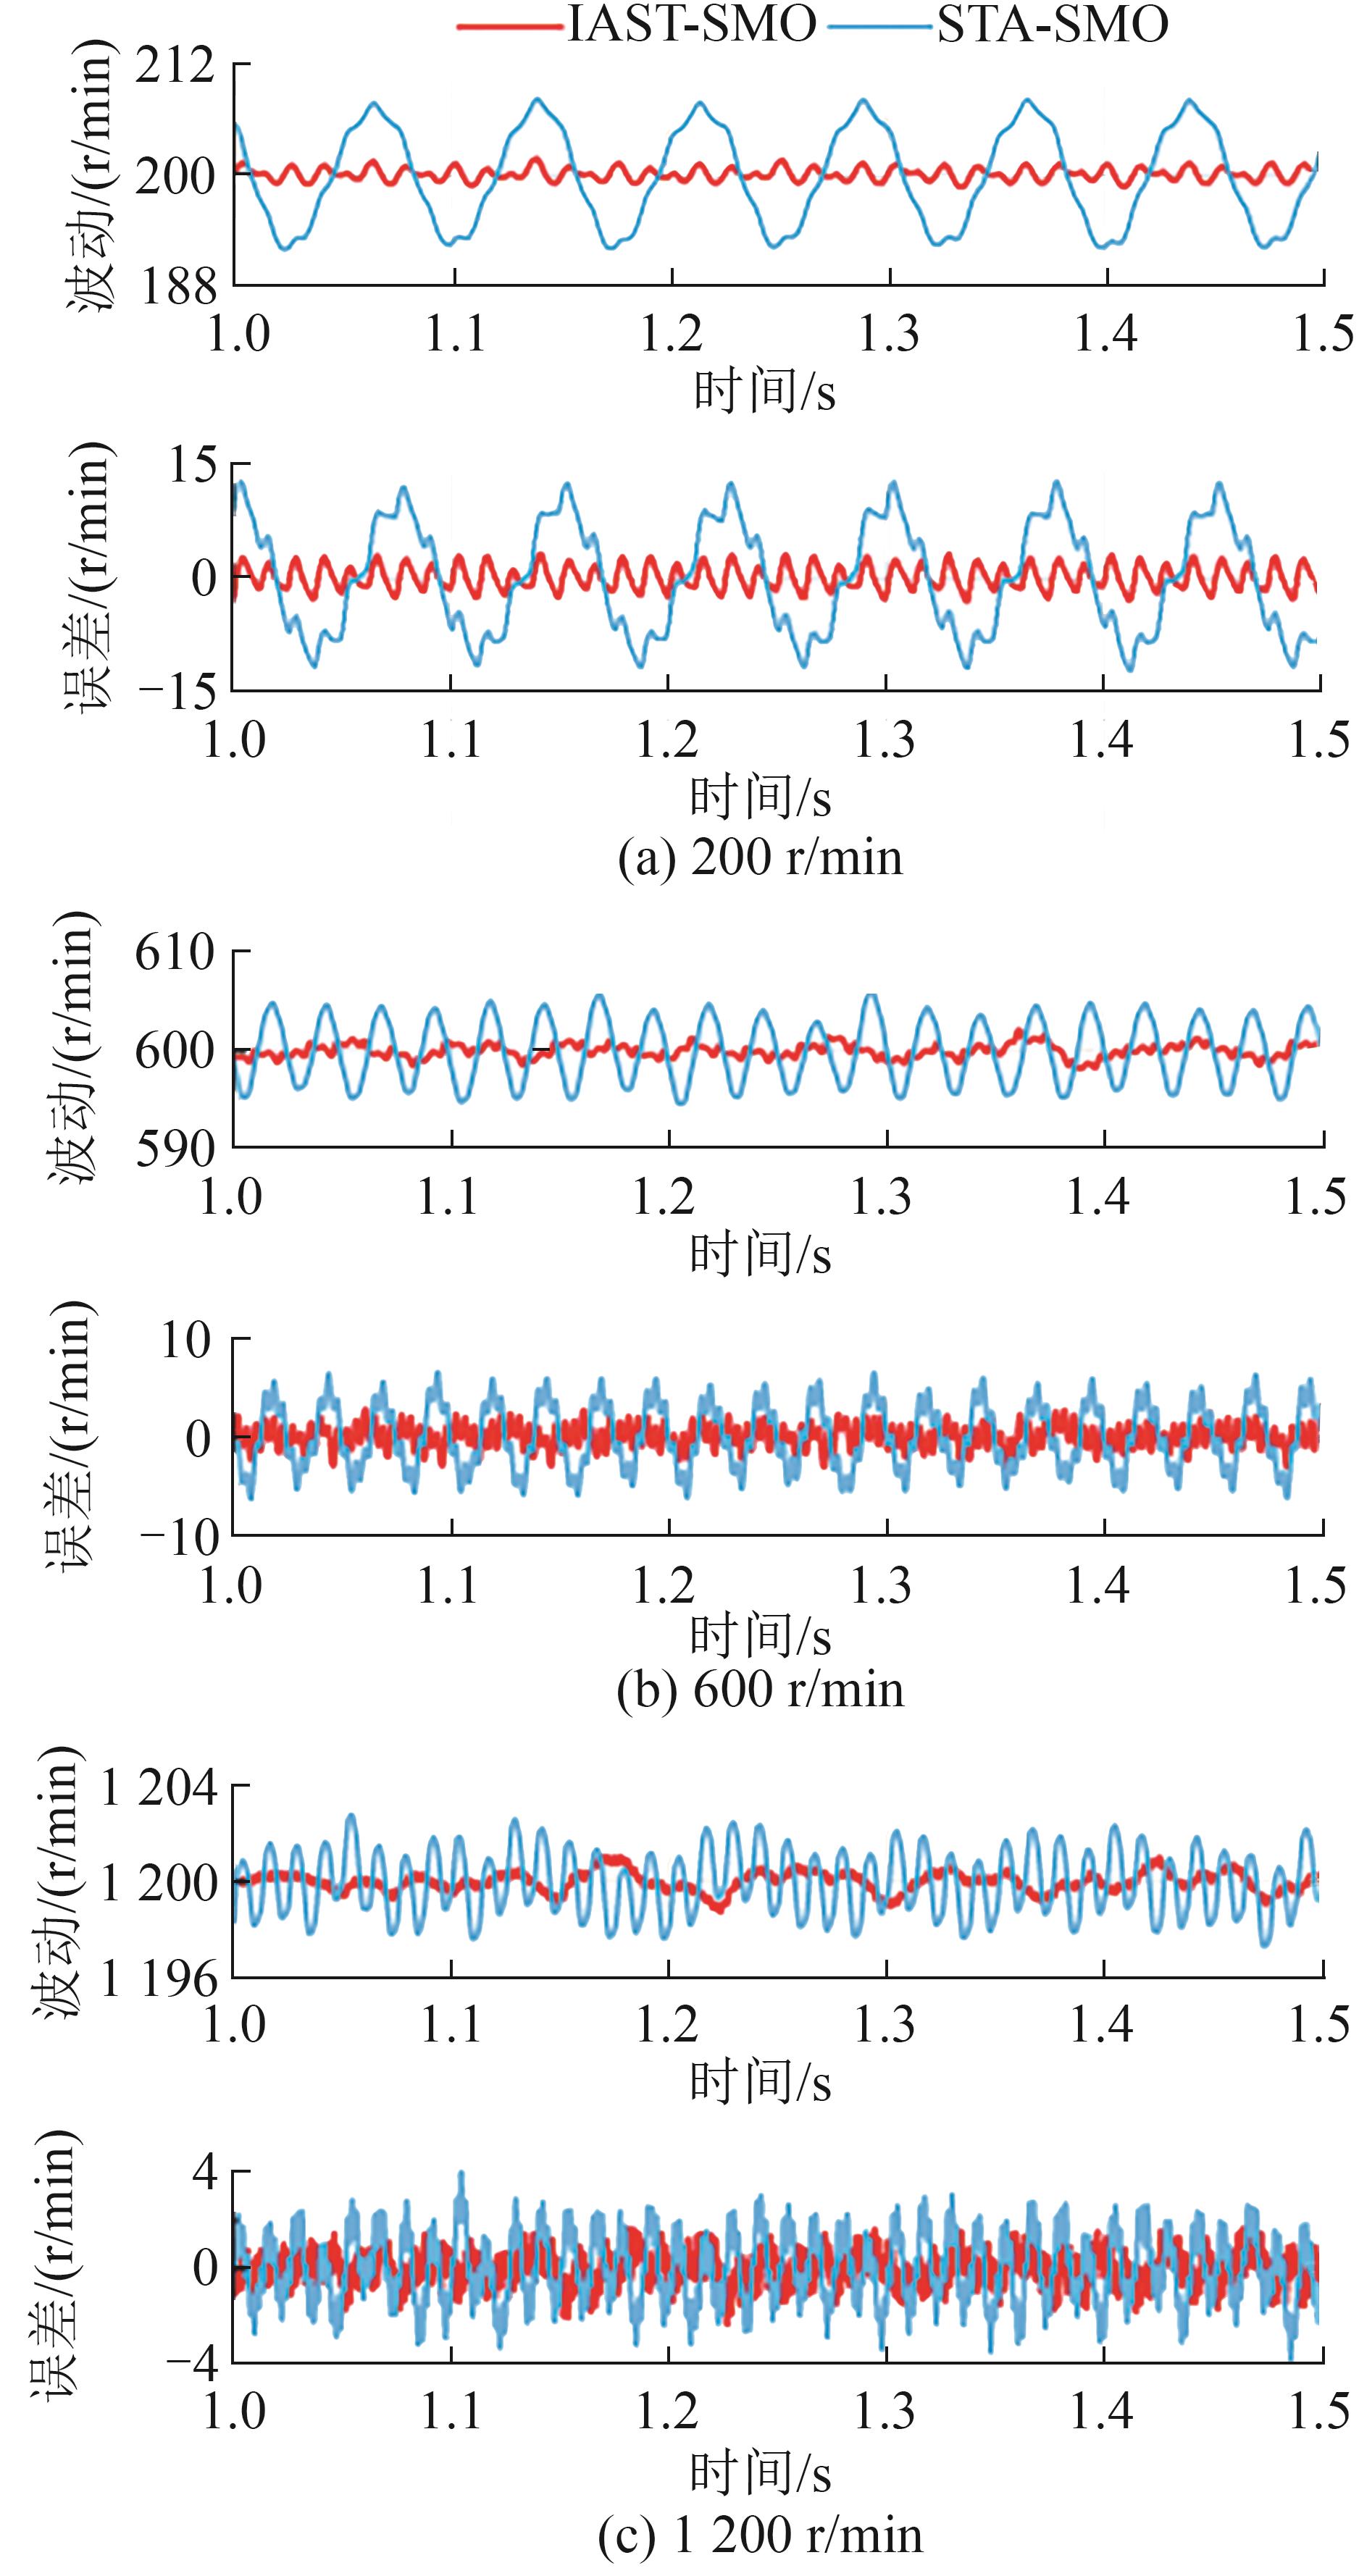
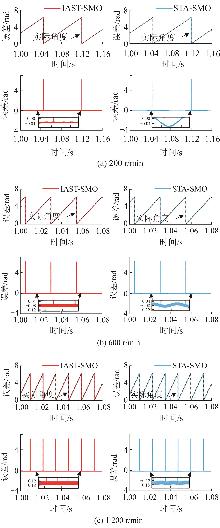
Fig. 9
Comparison of rotor positing
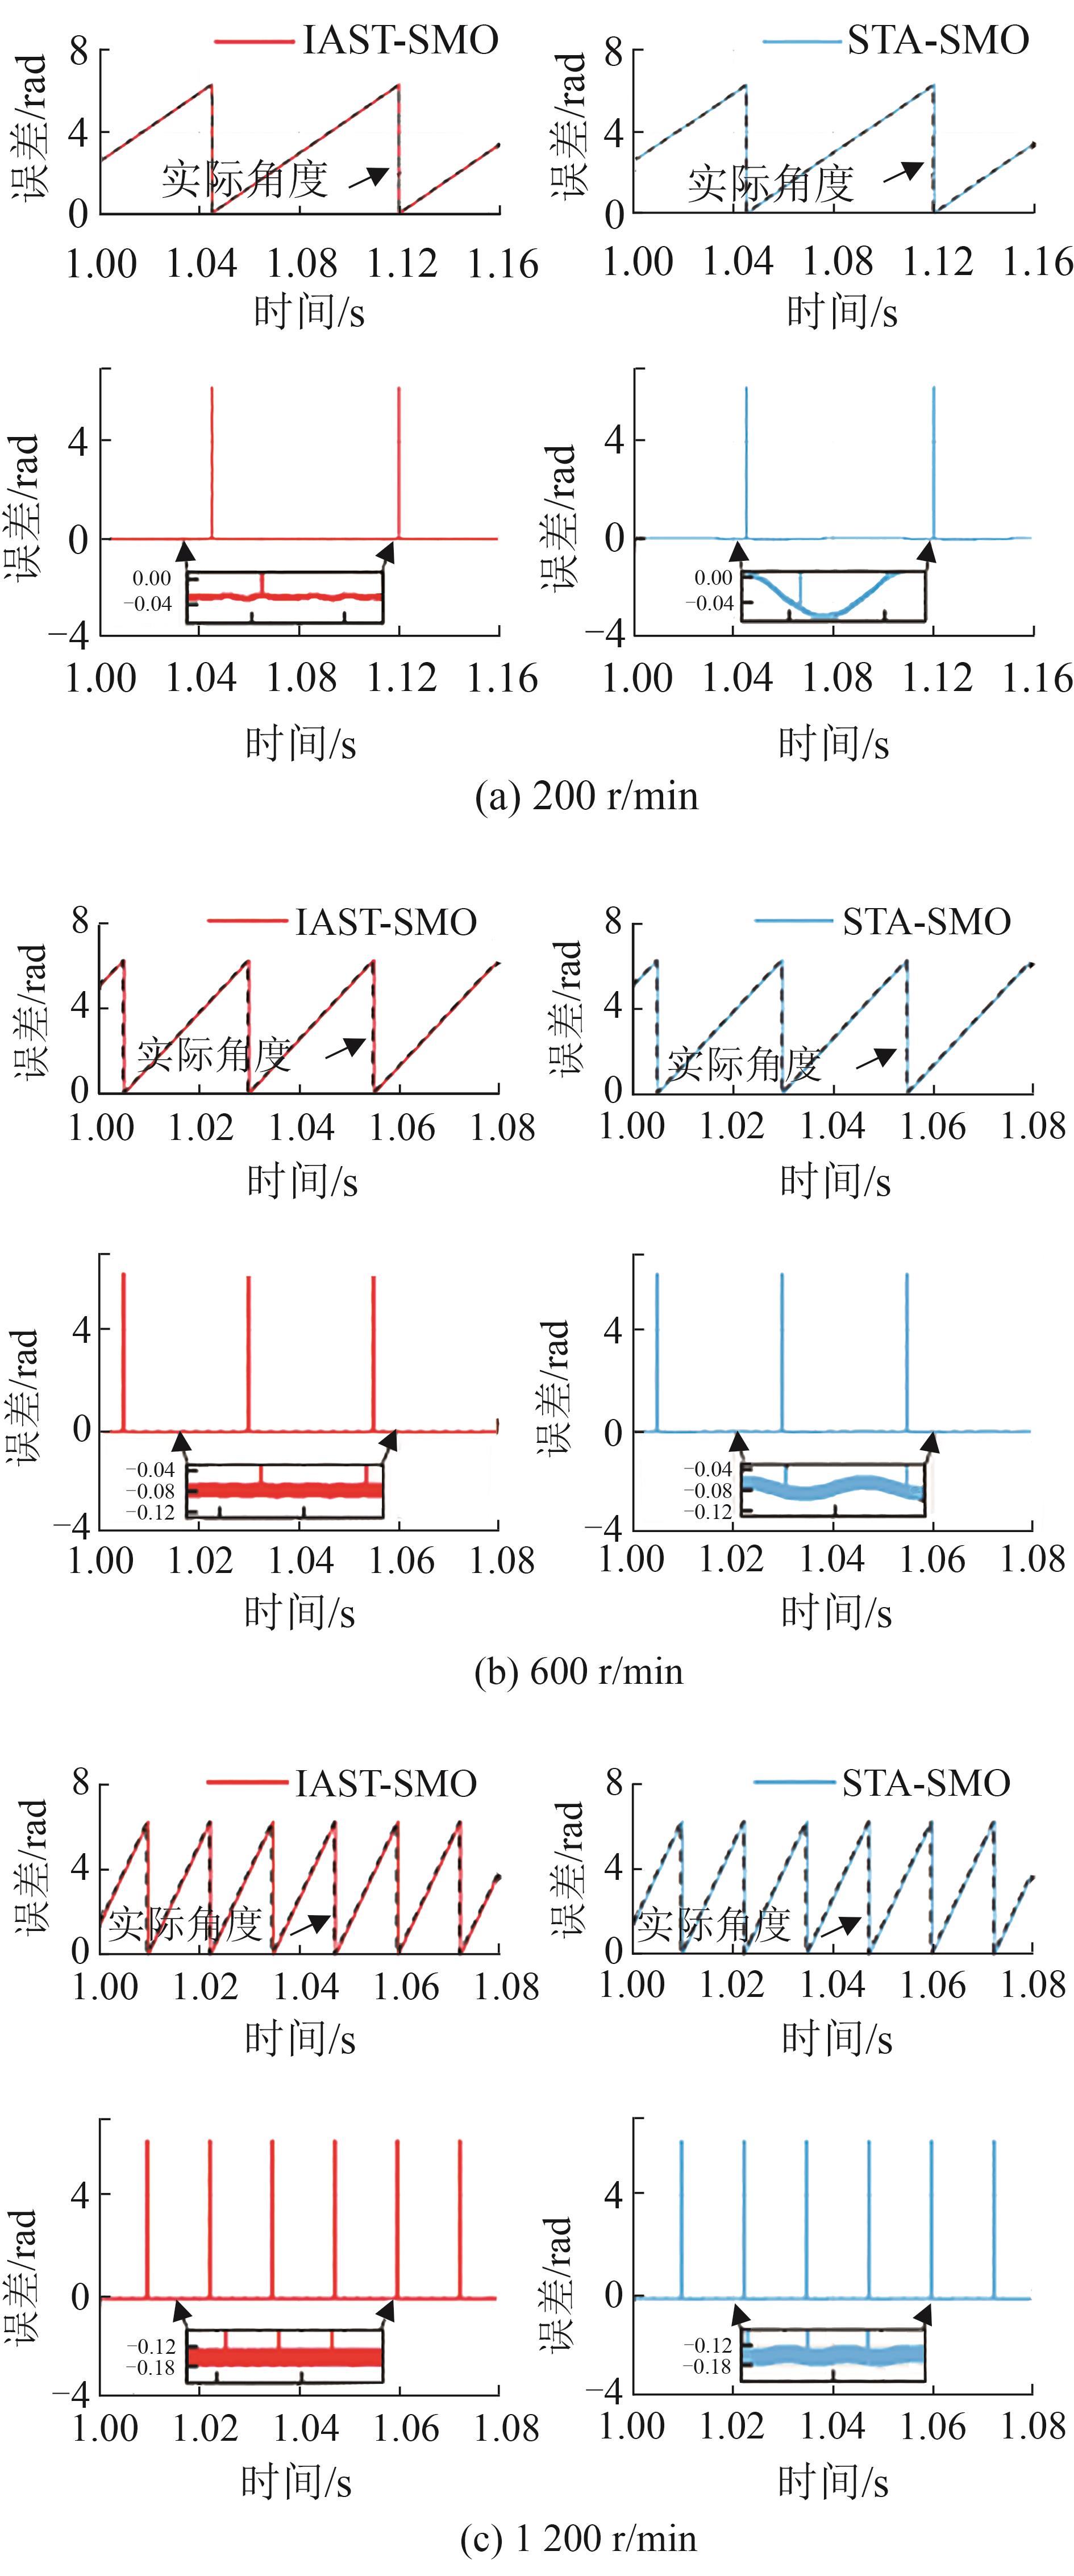
Fig. 10
Comparison of rotor speeds after filtering
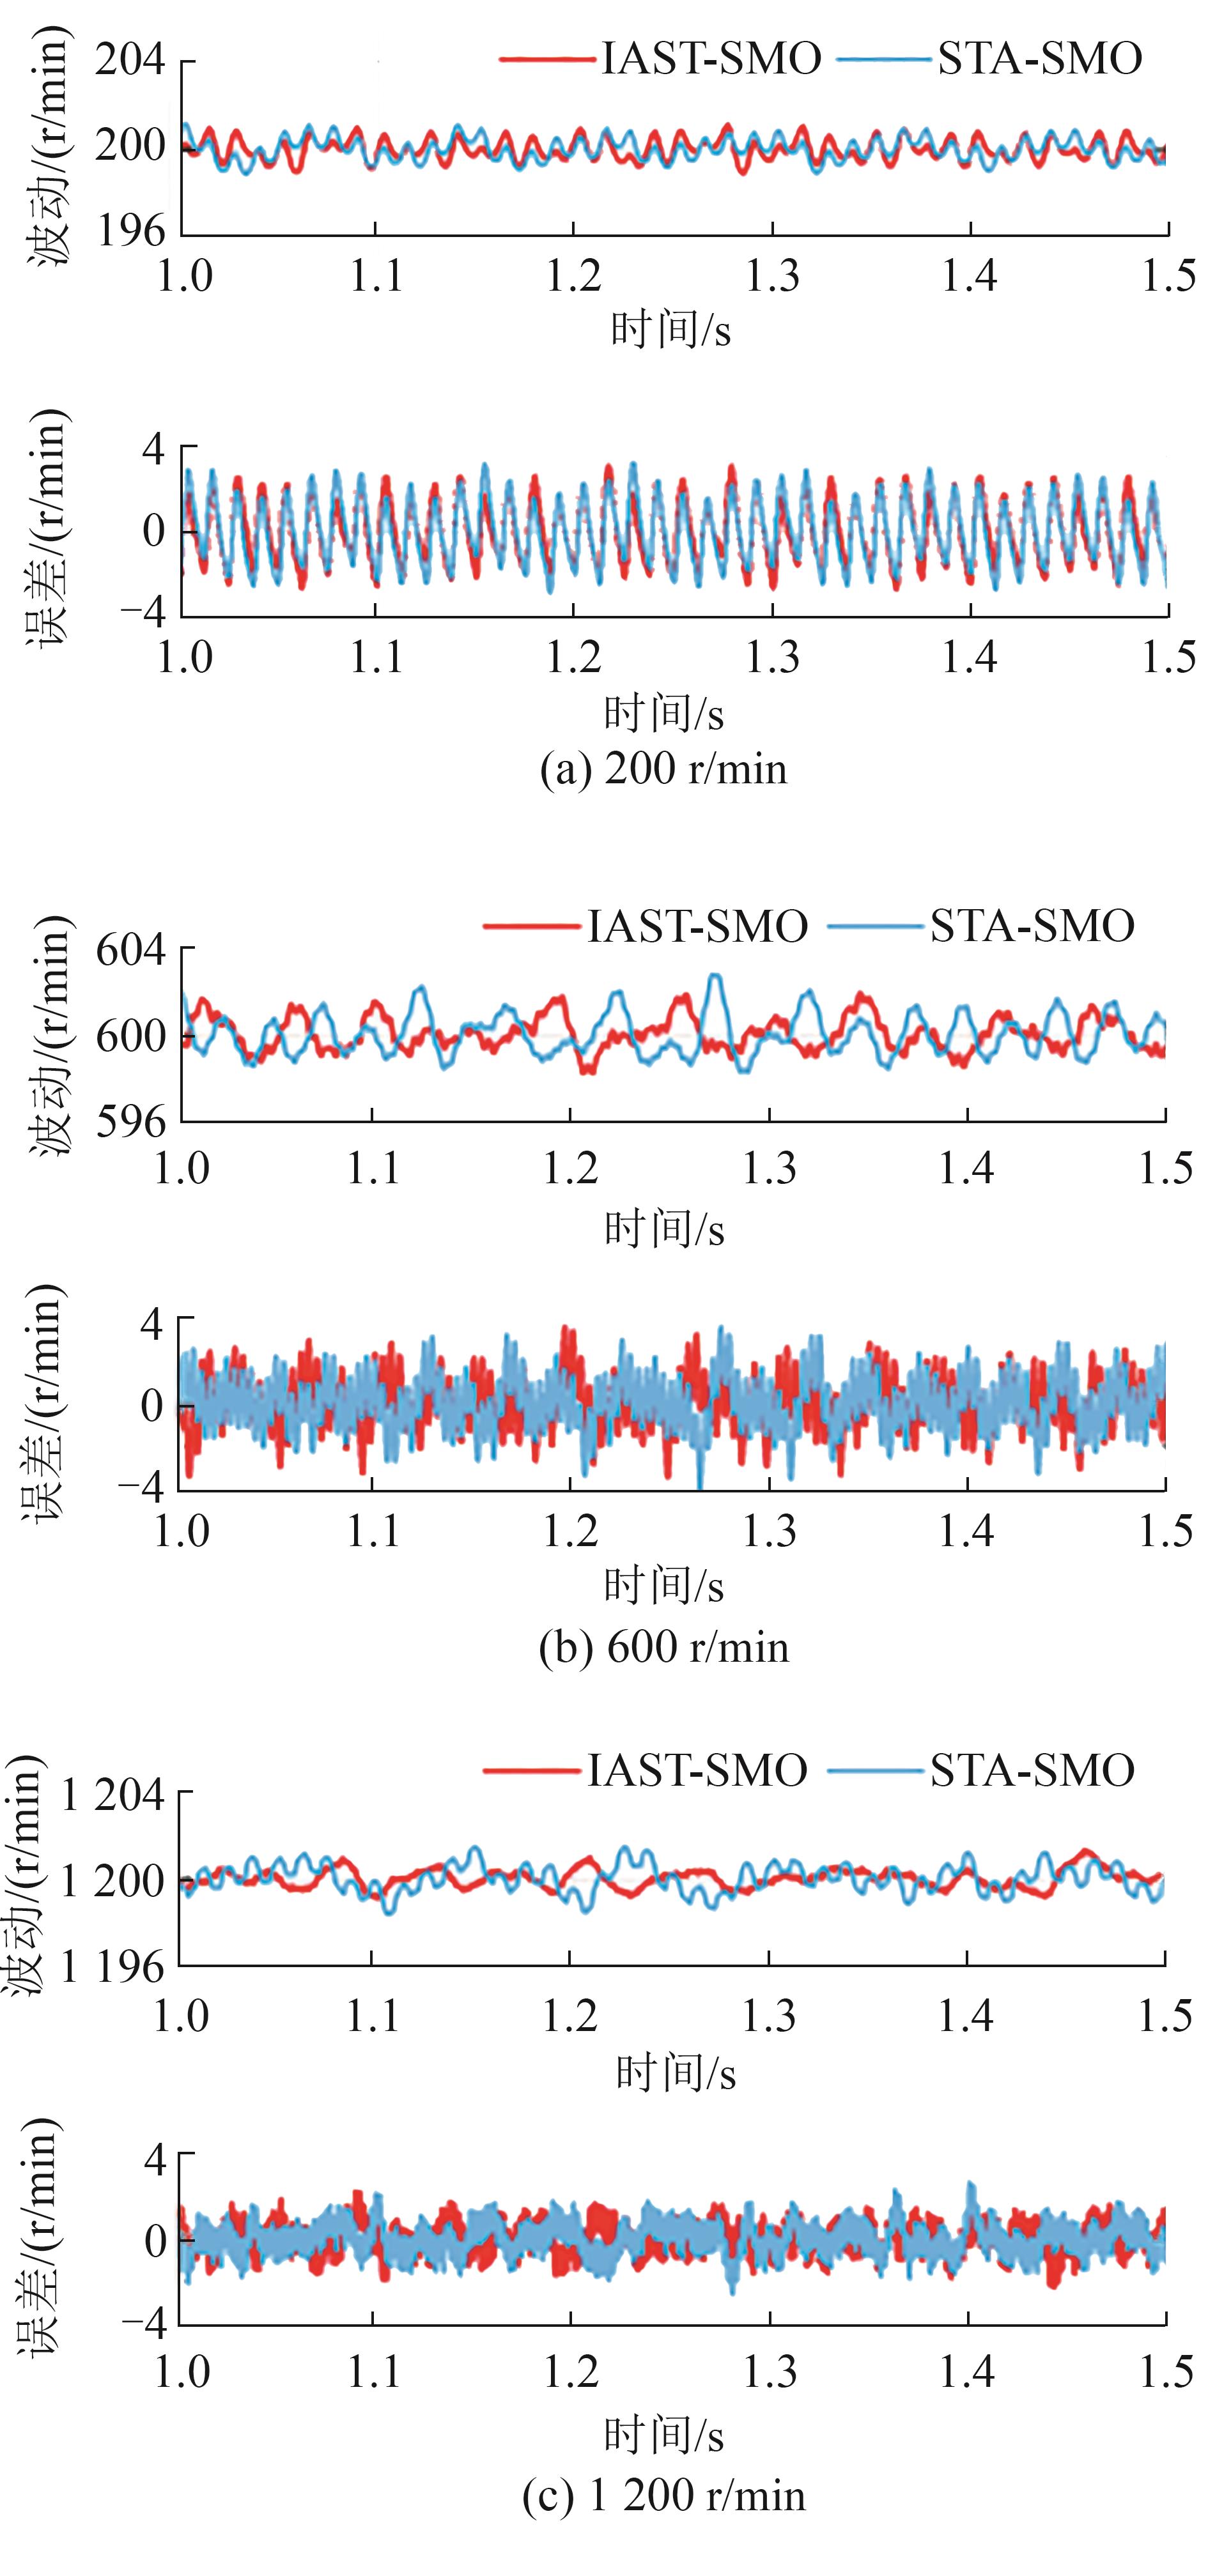
Fig. 11
Comparison of rotor positions after filtering
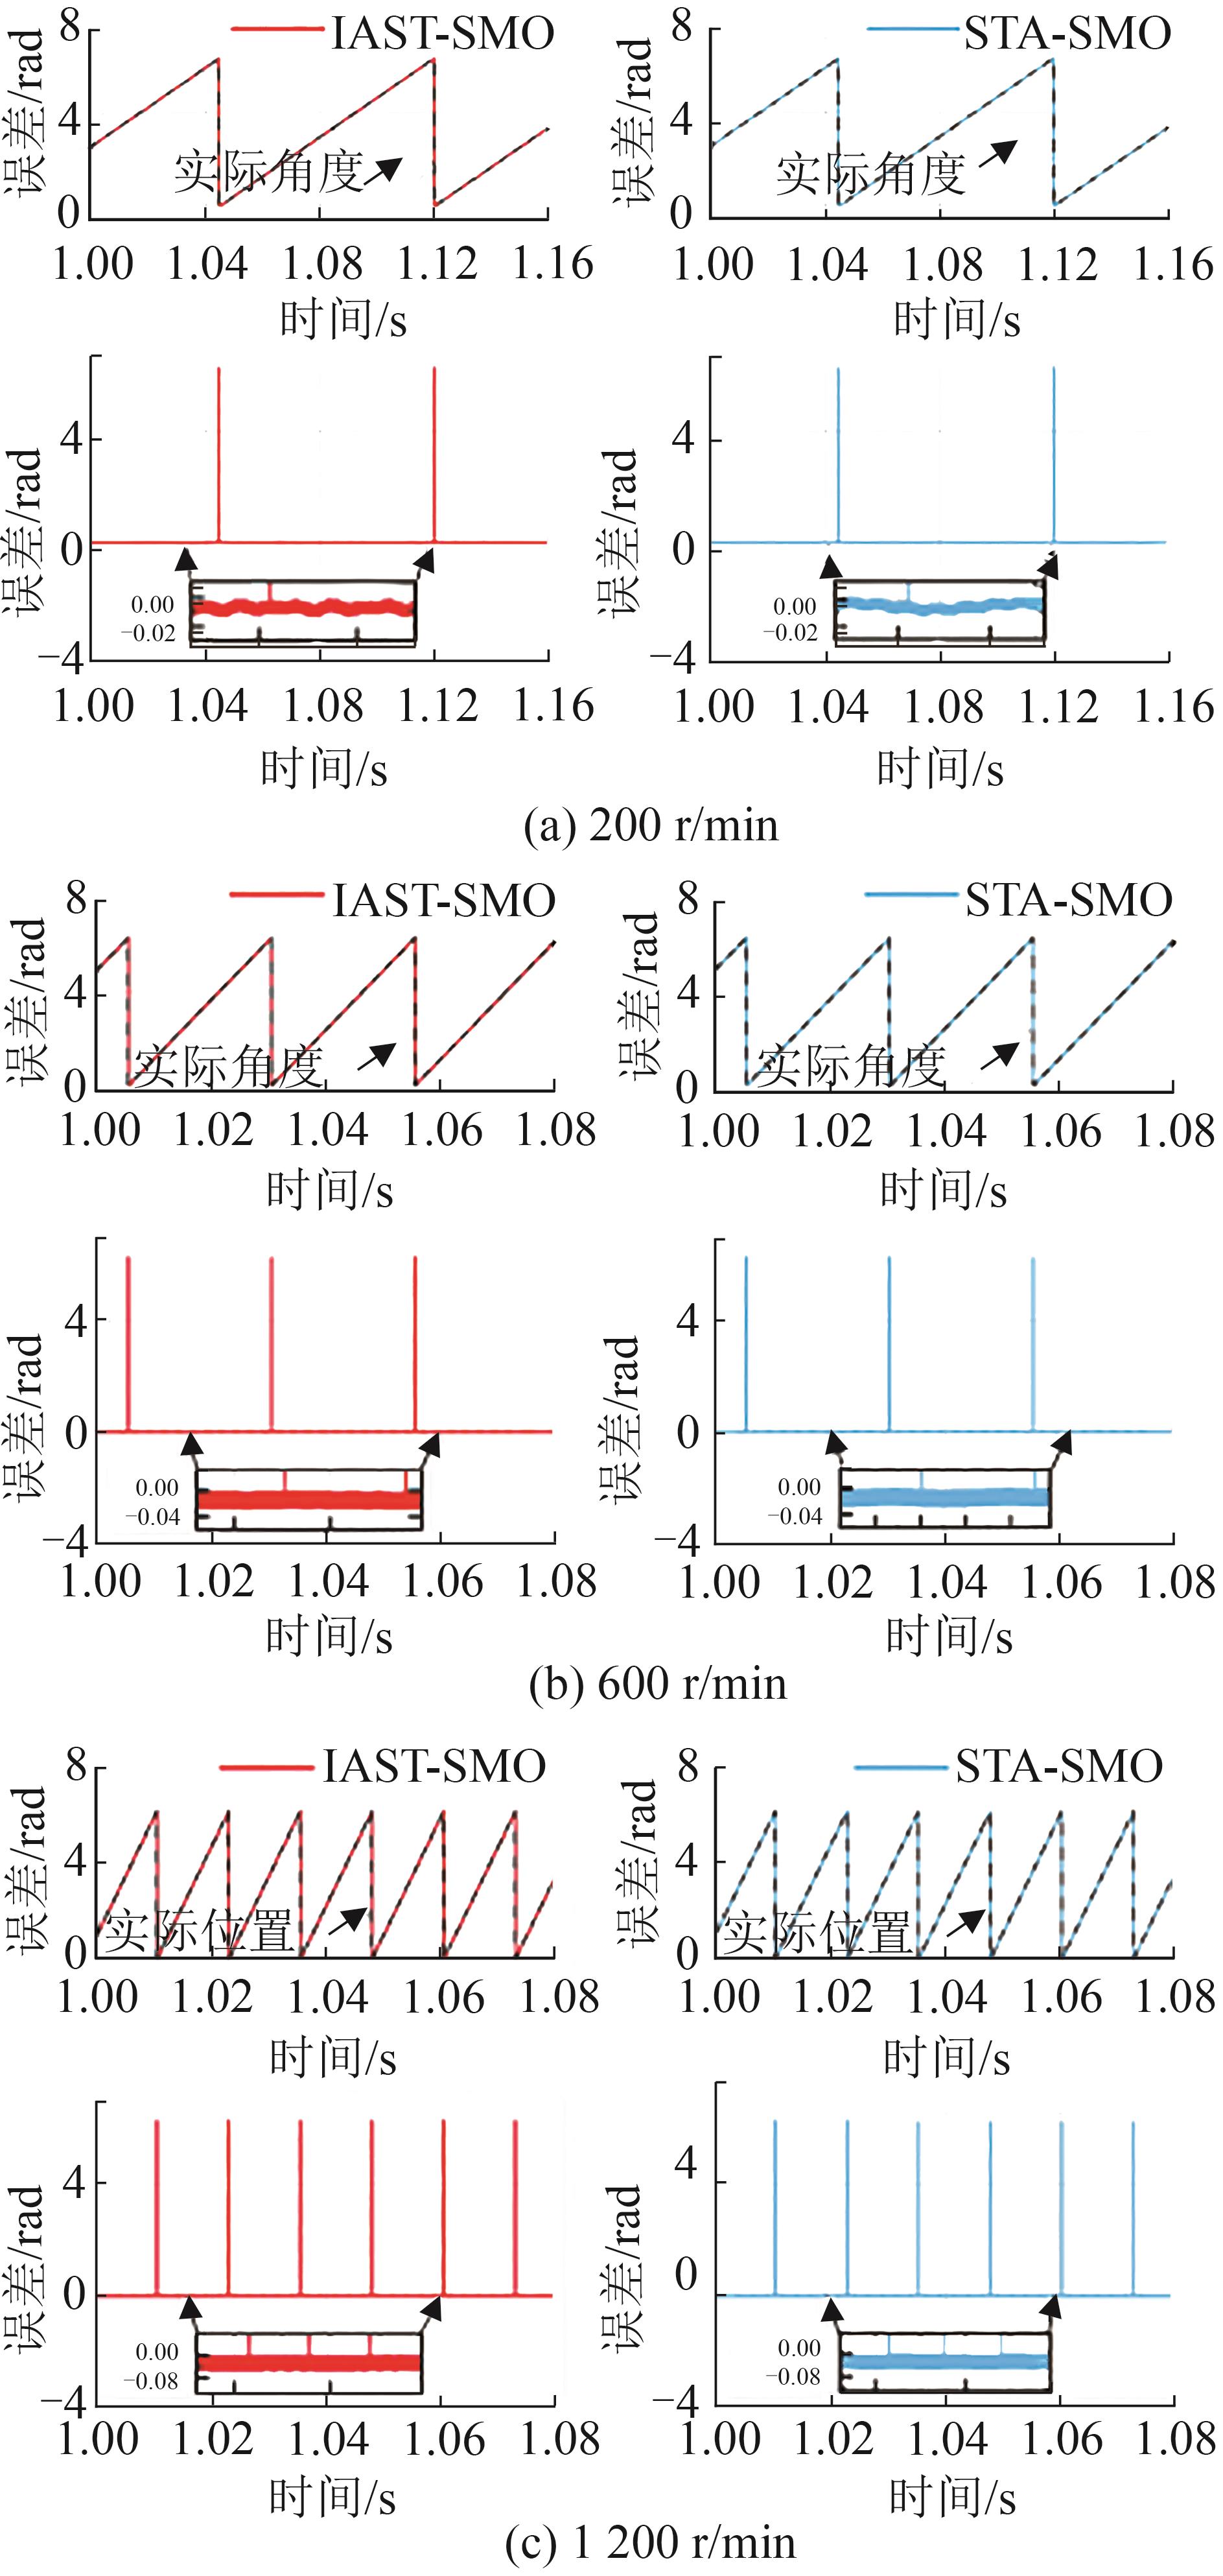
Table 3
Comparison of steady-state performance under improved filter control strategies
| 转速/(r/min) | 控制方式 | 转速波动/(r/min) | 转速观测误差/(r/min) | 位置观测误差 |
|---|---|---|---|---|
| 200 | STA-SMO | 1.3 | 3.2 | 0.013 |
| IAST-SMO | 1.1 | 3.0 | 0.012 | |
| 600 | STA-SMO | 2.7 | 3.9 | 0.029 |
| IAST-SMO | 1.9 | 3.6 | 0.028 | |
| 1 200 | STA-SMO | 1.6 | 2.6 | 0.053 |
| IAST-SMO | 1.3 | 2.2 | 0.052 |
Fig. 12
Harmonic analysis of observed back electromotive force using IAST-SMO and IAST-SMO + VG-ACCF at 600 r/min
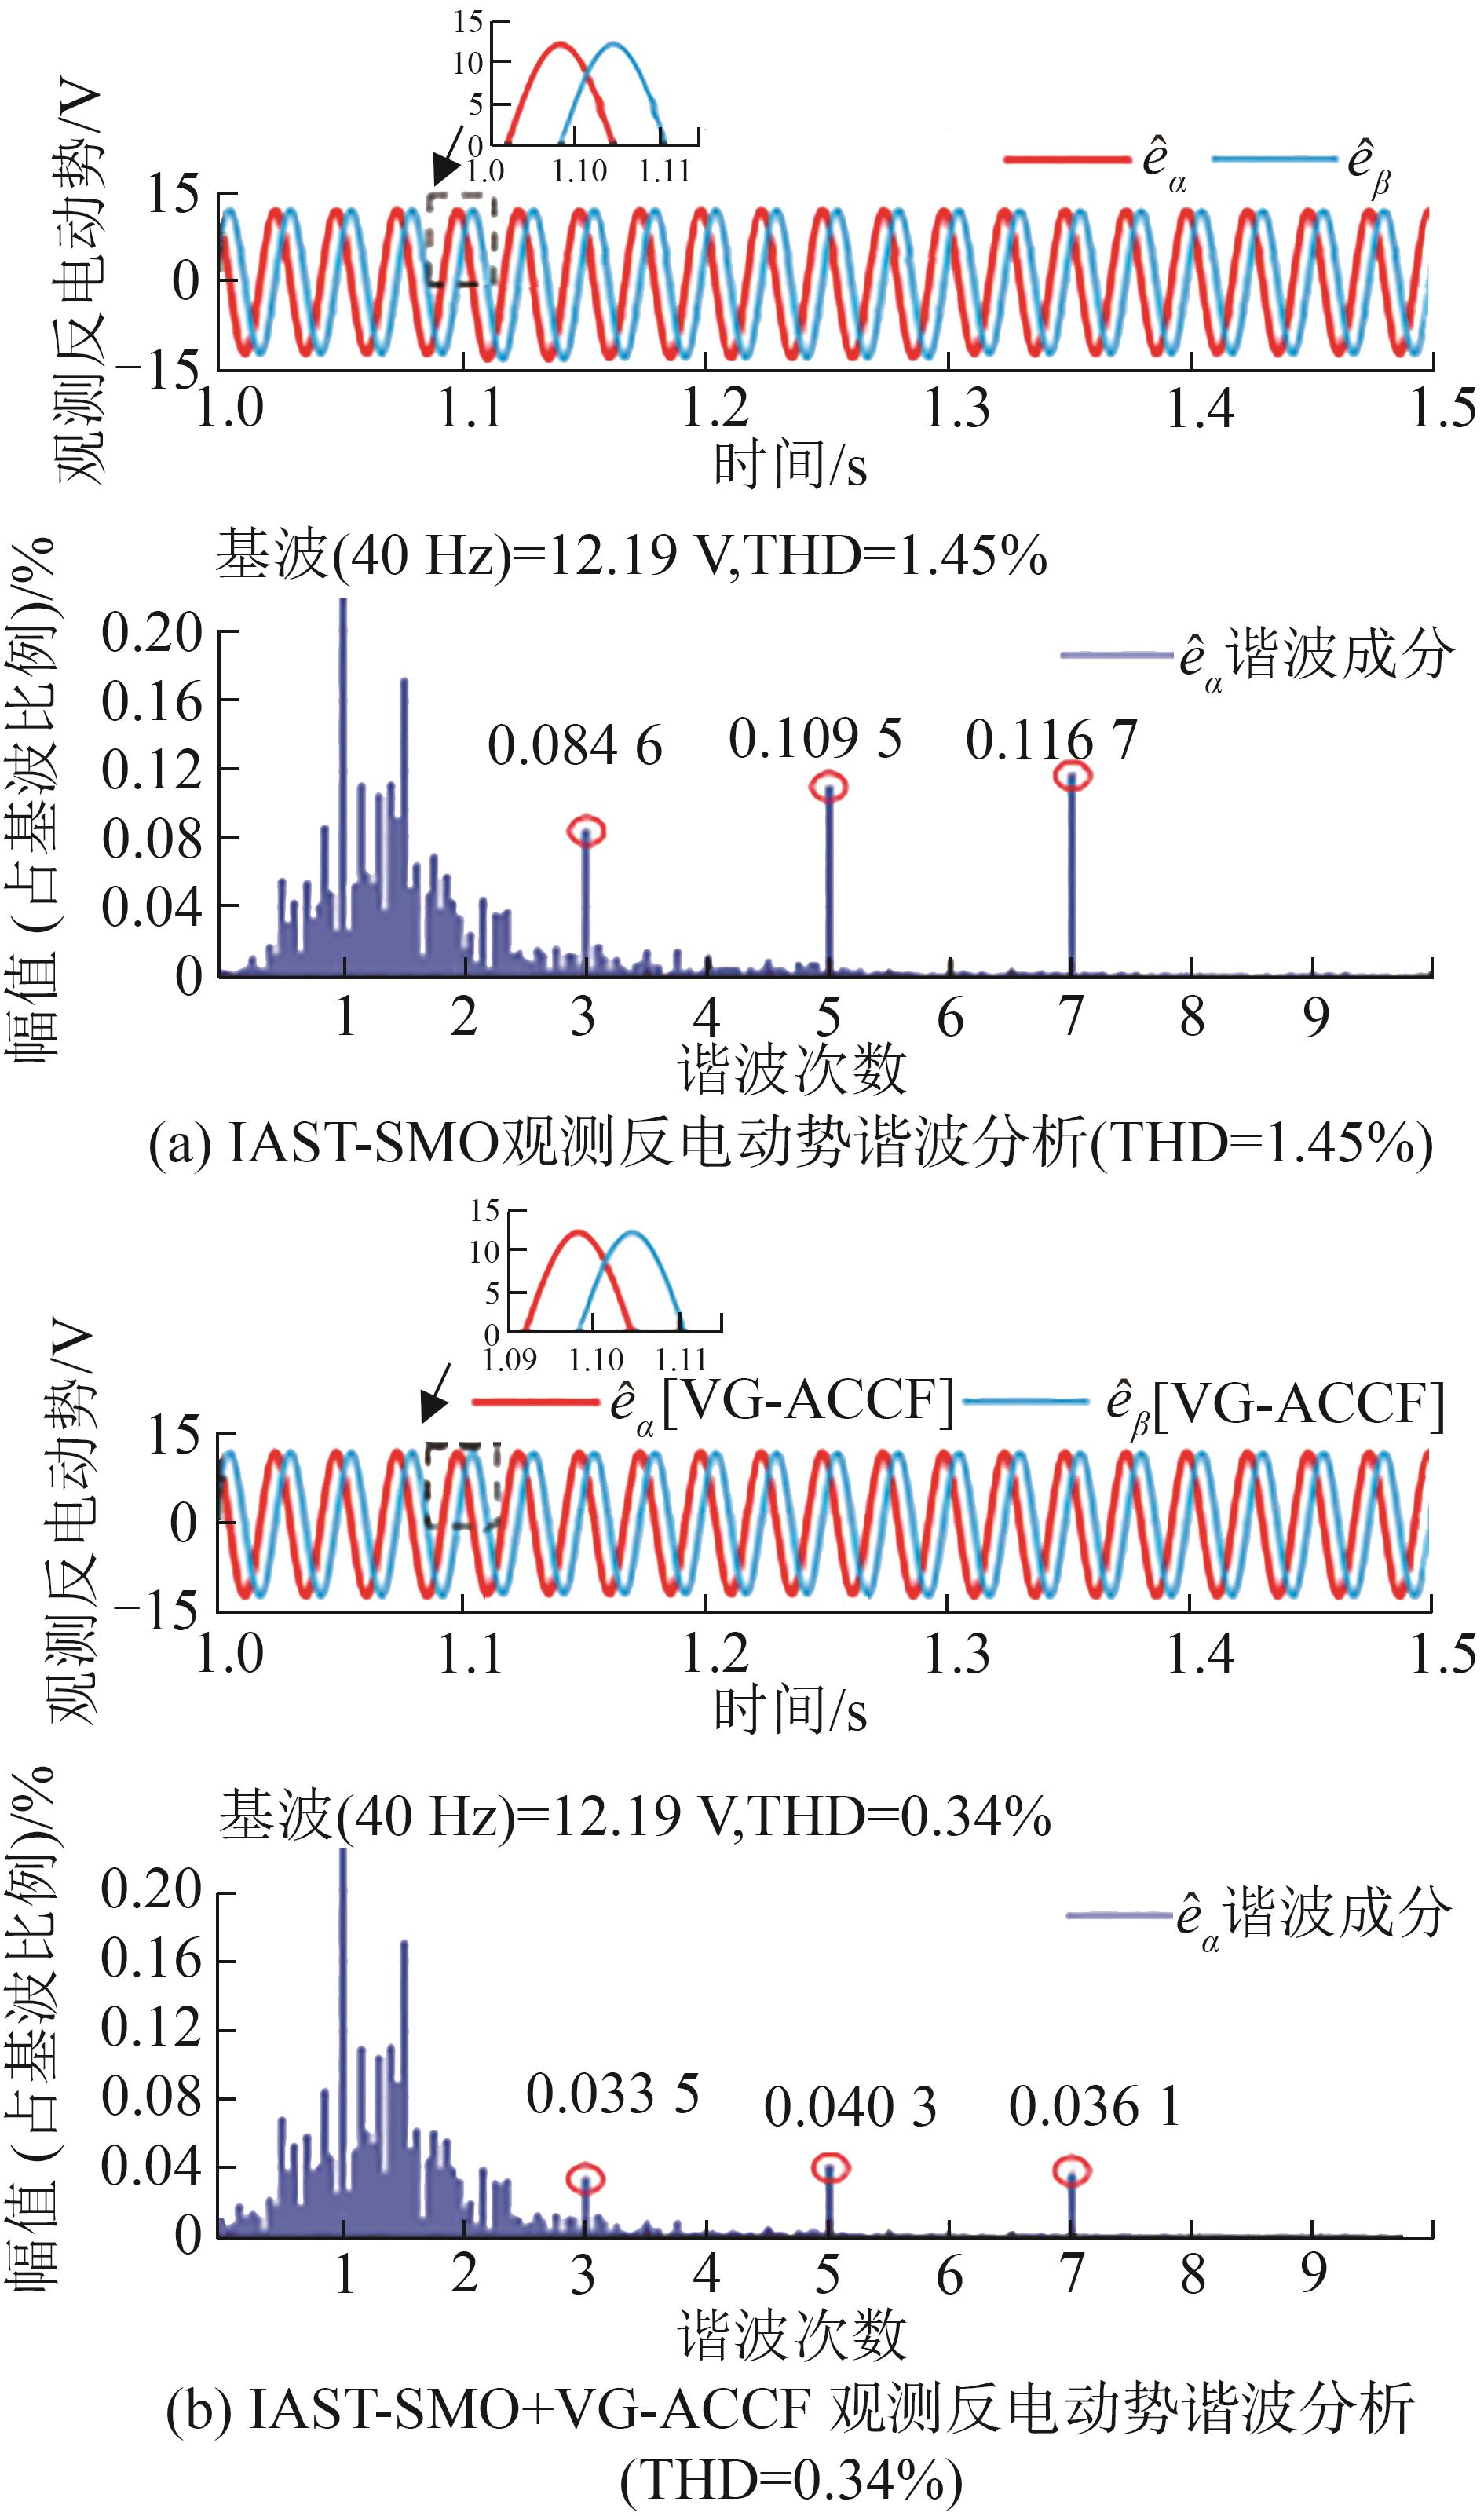
Fig. 13
Harmonic analysis of observed back electromotive force using IAST-SMO and IAST-SMO + VG-ACCF at 1 200 r/min
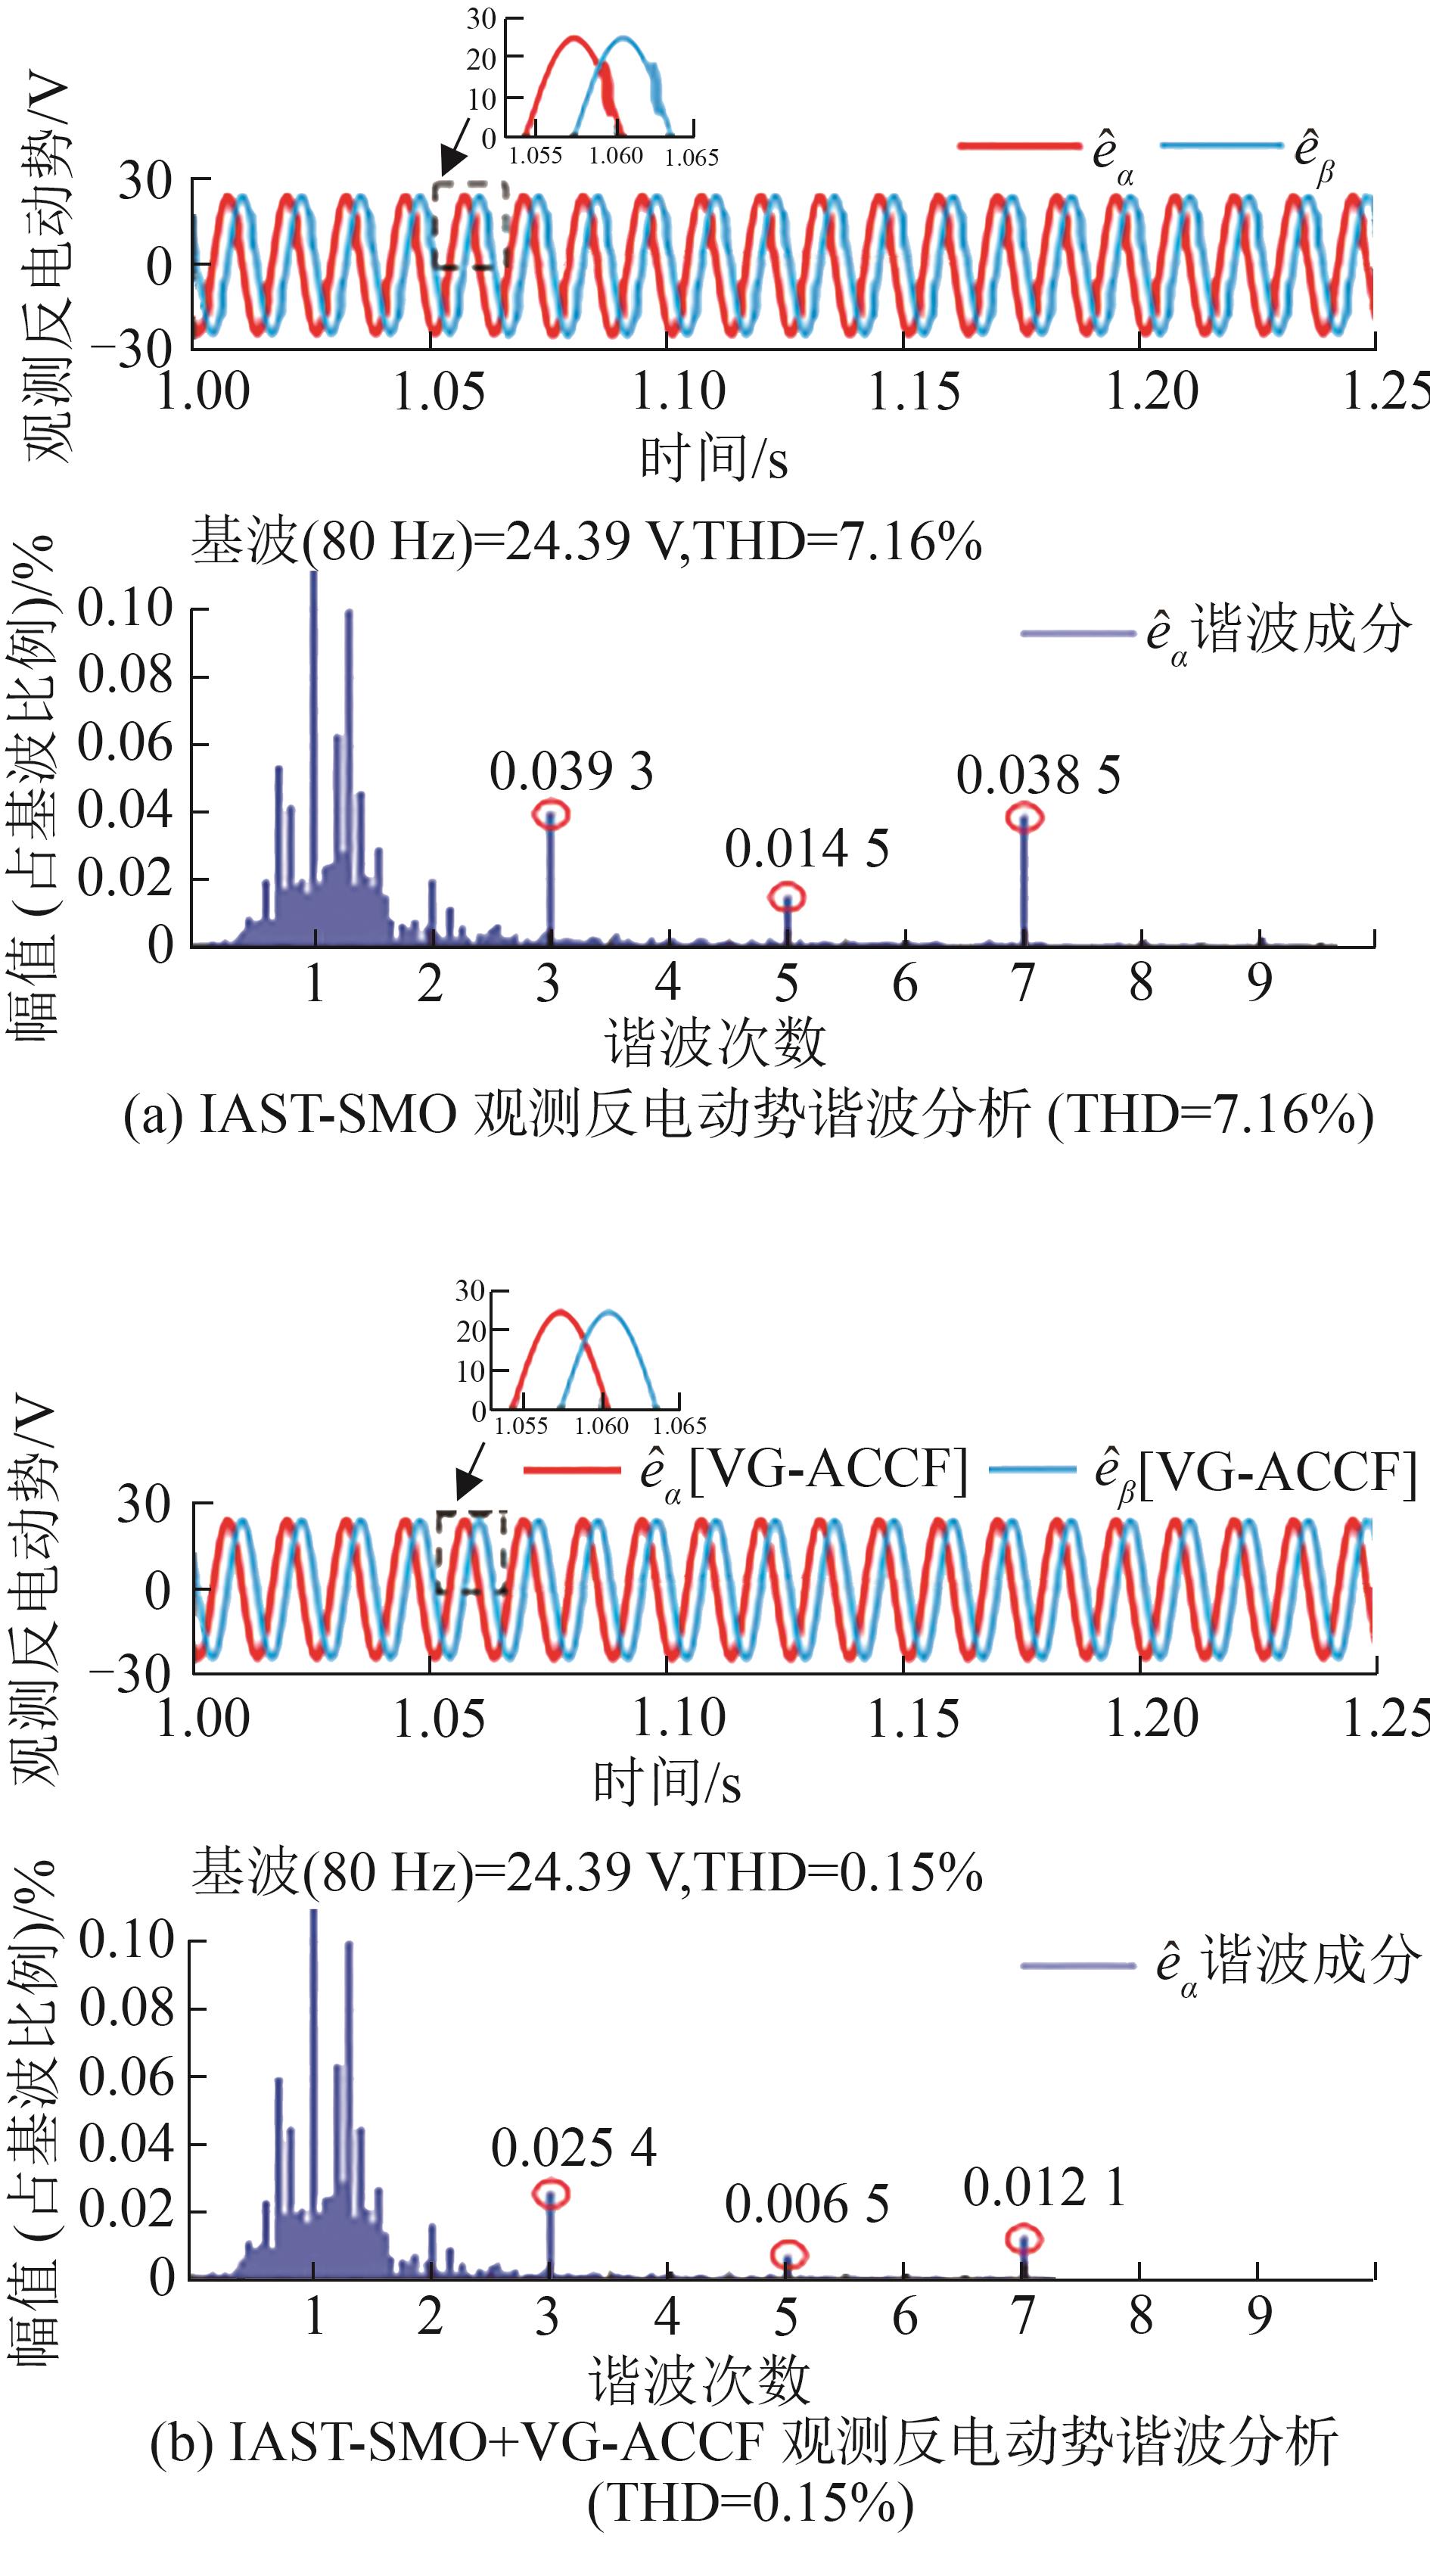
Fig. 14
Comparison of rotor speeds in no-load variable-speed condition
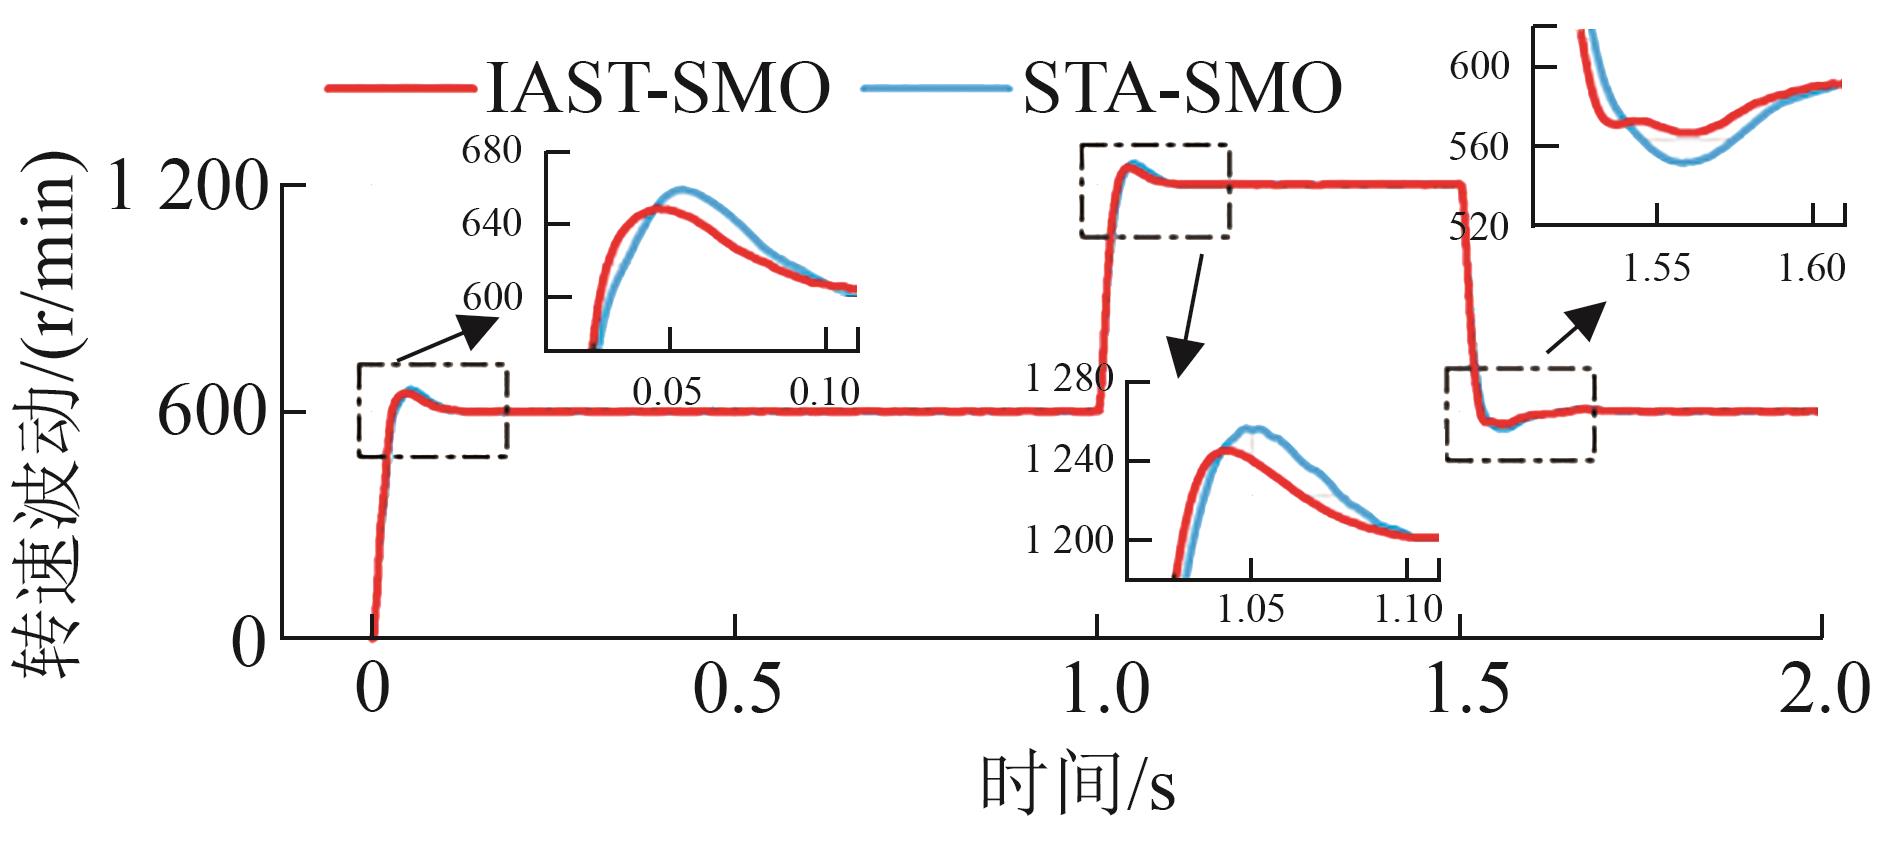
Fig. 15
Variation of back electromotive force in no-load variable-speed condition
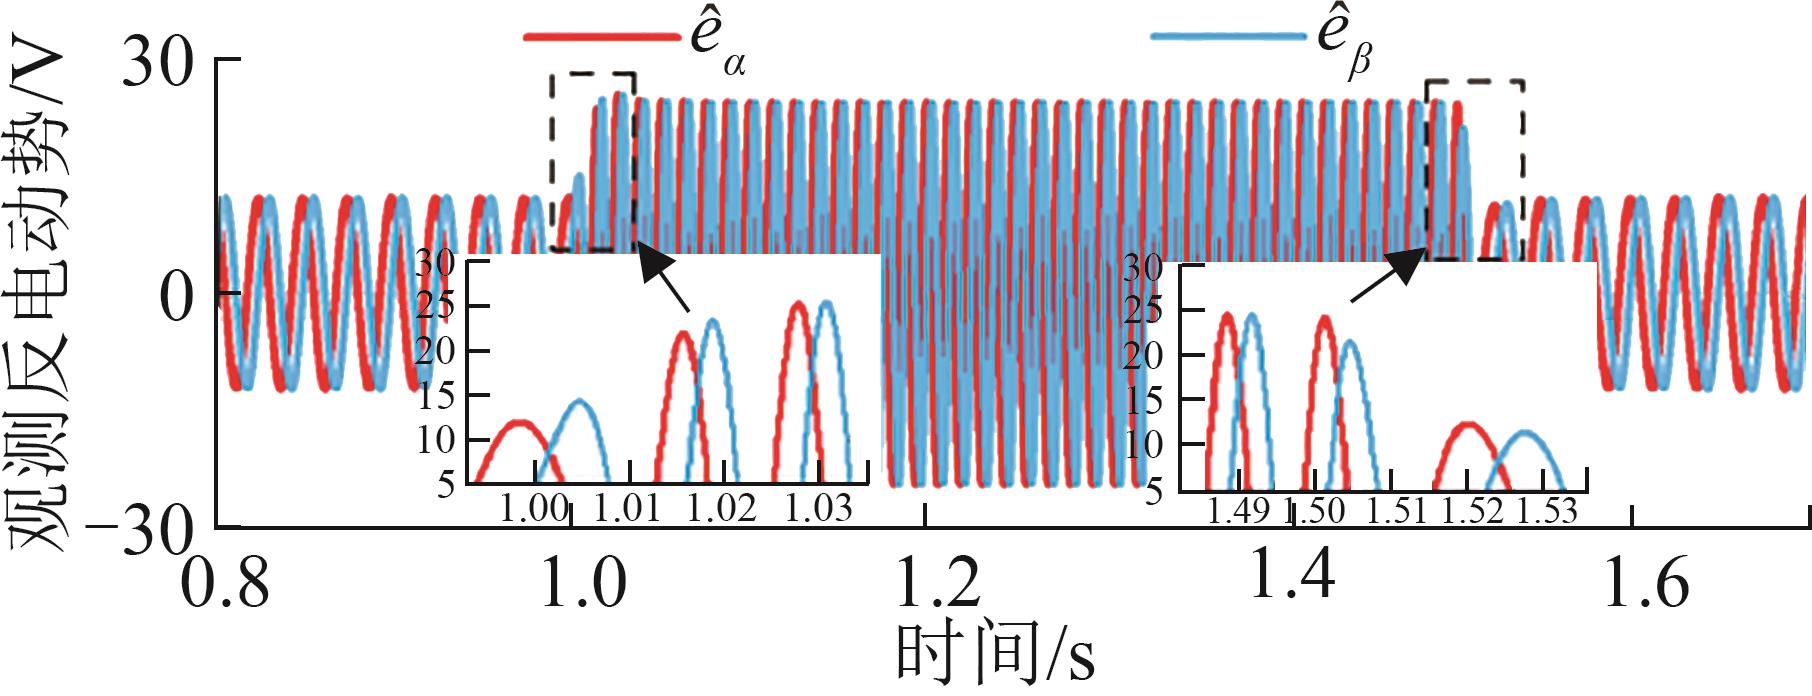
Table 4
Comparison of dynamic performance under variable-speed control in no-load conditions
| 控制方式 | 超调量/(r/min) | 上升/下降时间 | 稳定时间 |
|---|---|---|---|
| STA-SMO | 58.9 | 24.66 | 94.92 |
| IAST-SMO | 48.6 | 23.02 | 89.23 |
| STA-SMO | 57 | 20.75 | 78.04 |
| IAST-SMO | 45.9 | 18.67 | 65.47 |
| STA-SMO | 66.9 | 25.03 | 101.66 |
| IAST-SMO | 52.1 | 22.31 | 93.96 |
Fig. 16
Comparison of rotor speeds in constant-speed variable-load condition
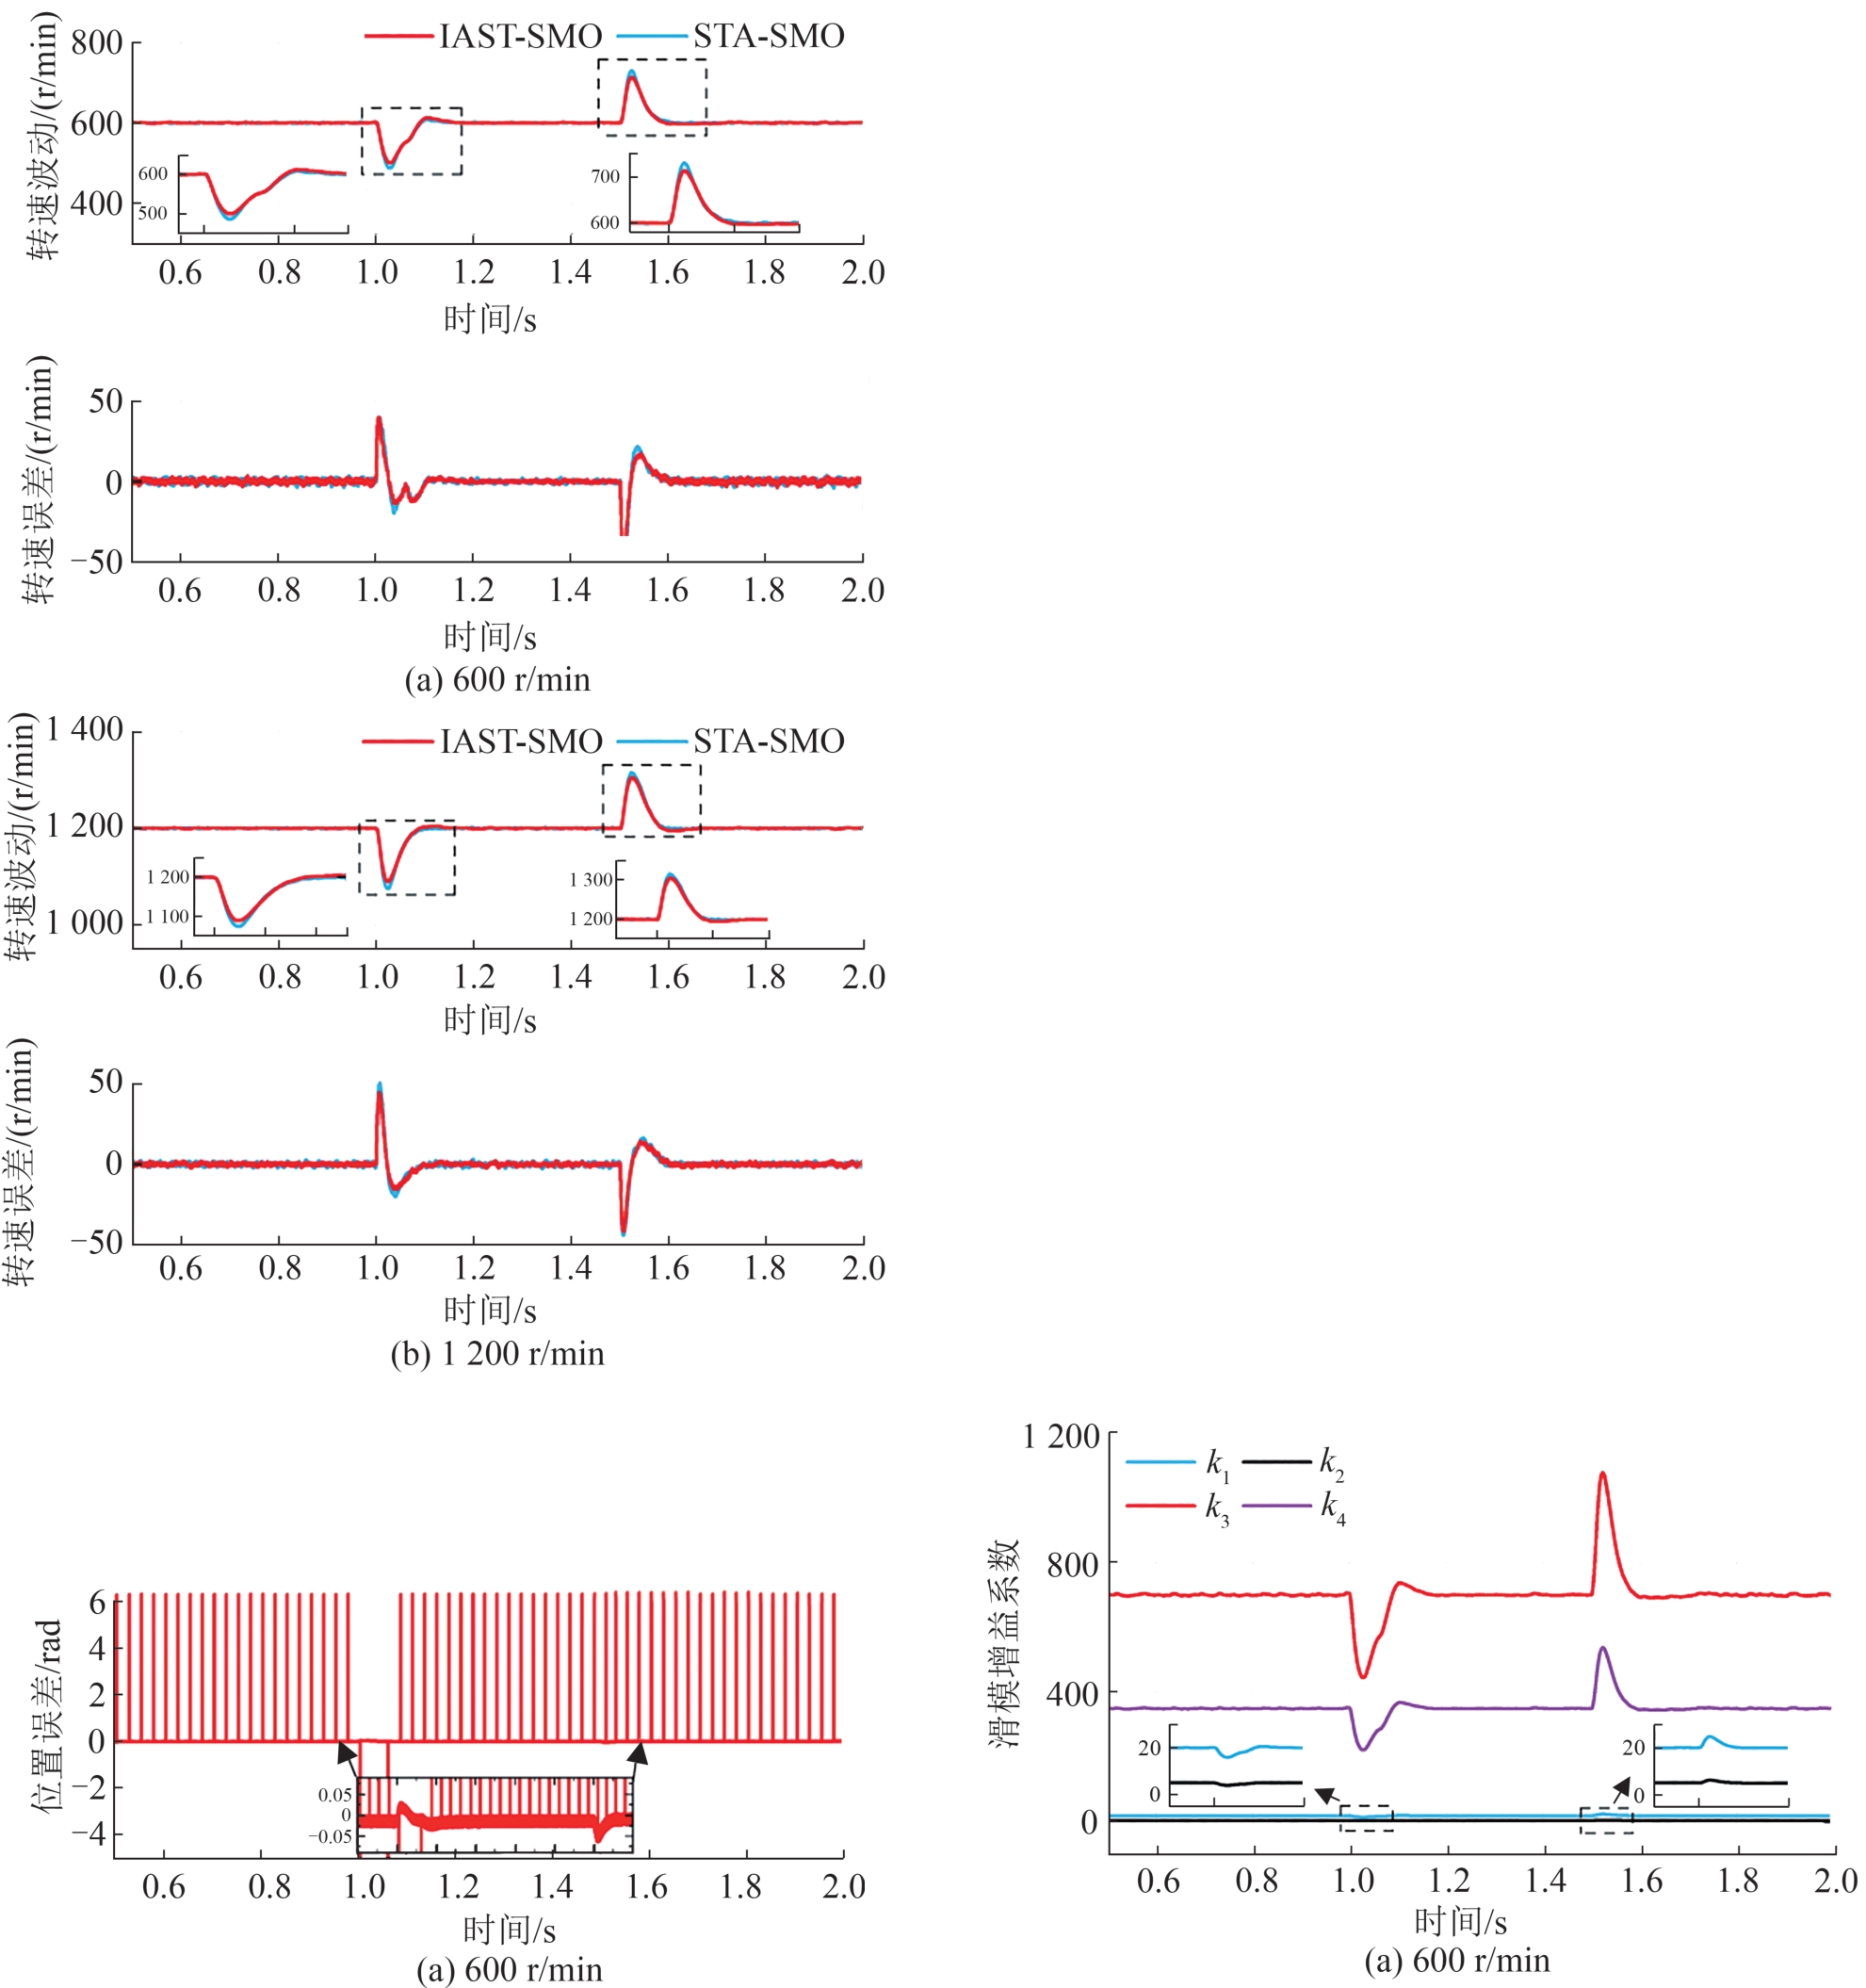
Fig. 17
Comparison of rotor positions in constant-speed variable-load condition
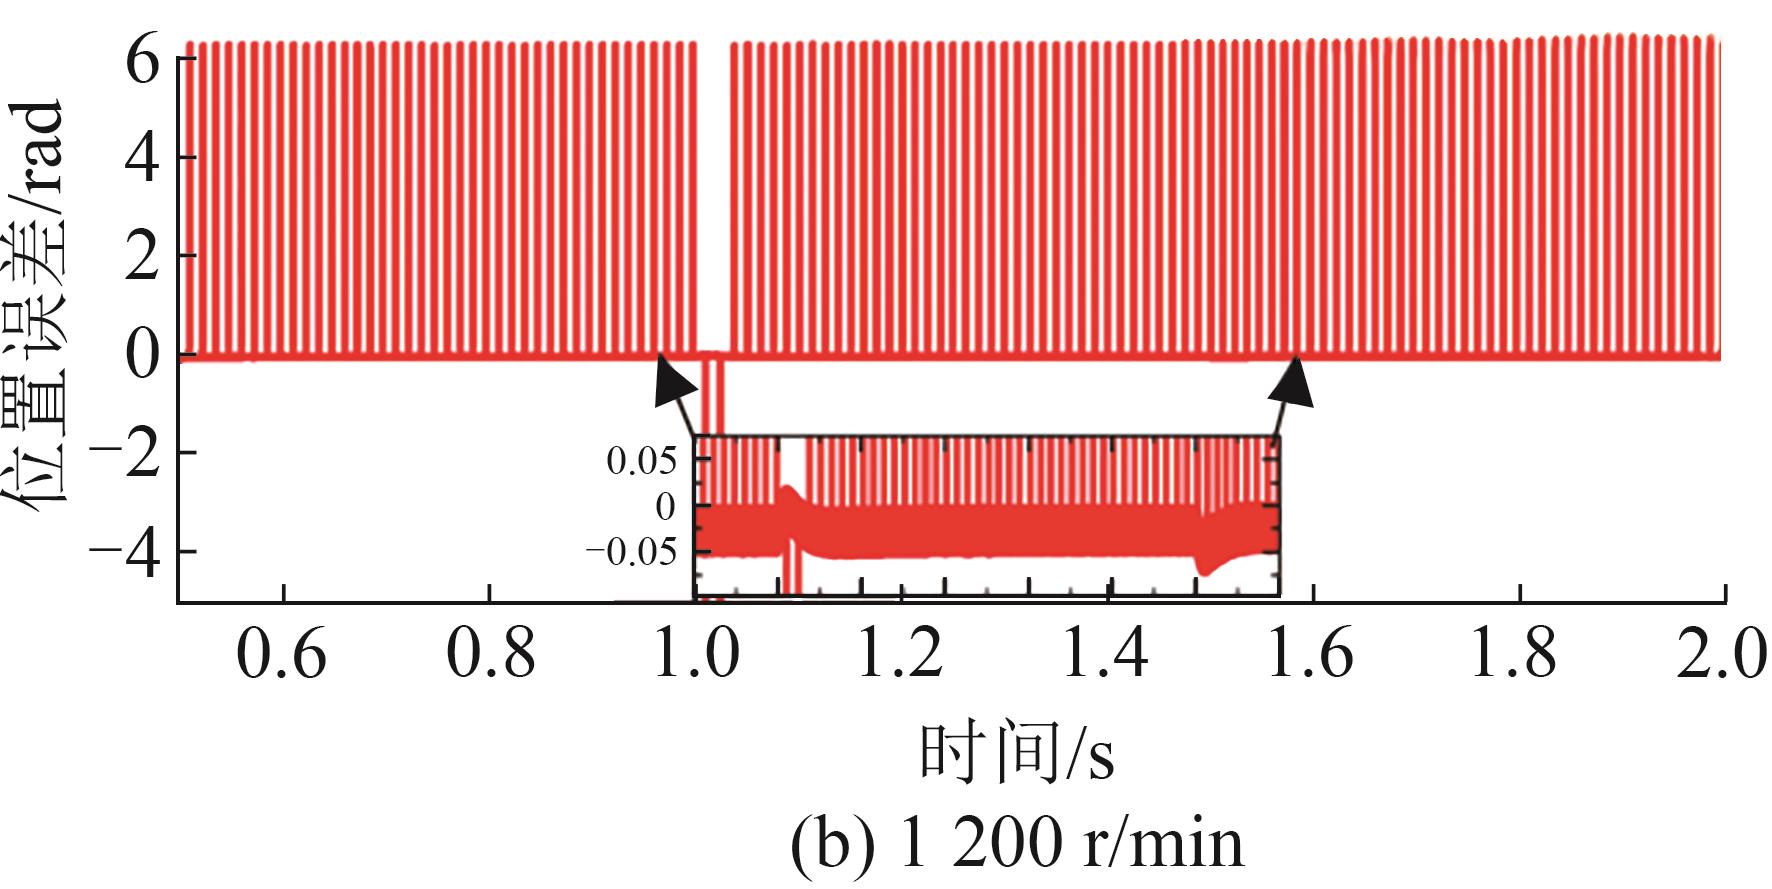
Table 5
Comparison of dynamic performance under variable-load control in constant-speed conditions
| 转速/(r/min) | 控制方式 | 负载变化 | 转速波动/(r/min) | 稳定时间 |
|---|---|---|---|---|
| 600 | STA-SMO | 1 | 112.7 | 83.42 |
| 2 | 129.8 | 76.66 | ||
| IAST-SMO | 1 | 102.9 | 78.71 | |
| 2 | 118.2 | 69.12 | ||
| 1 200 | STA-SMO | 1 | 125.1 | 63.60 |
| 2 | 115.2 | 65.84 | ||
| IAST-SMO | 1 | 115.3 | 60.51 | |
| 2 | 109 | 63.00 |
Fig. 18
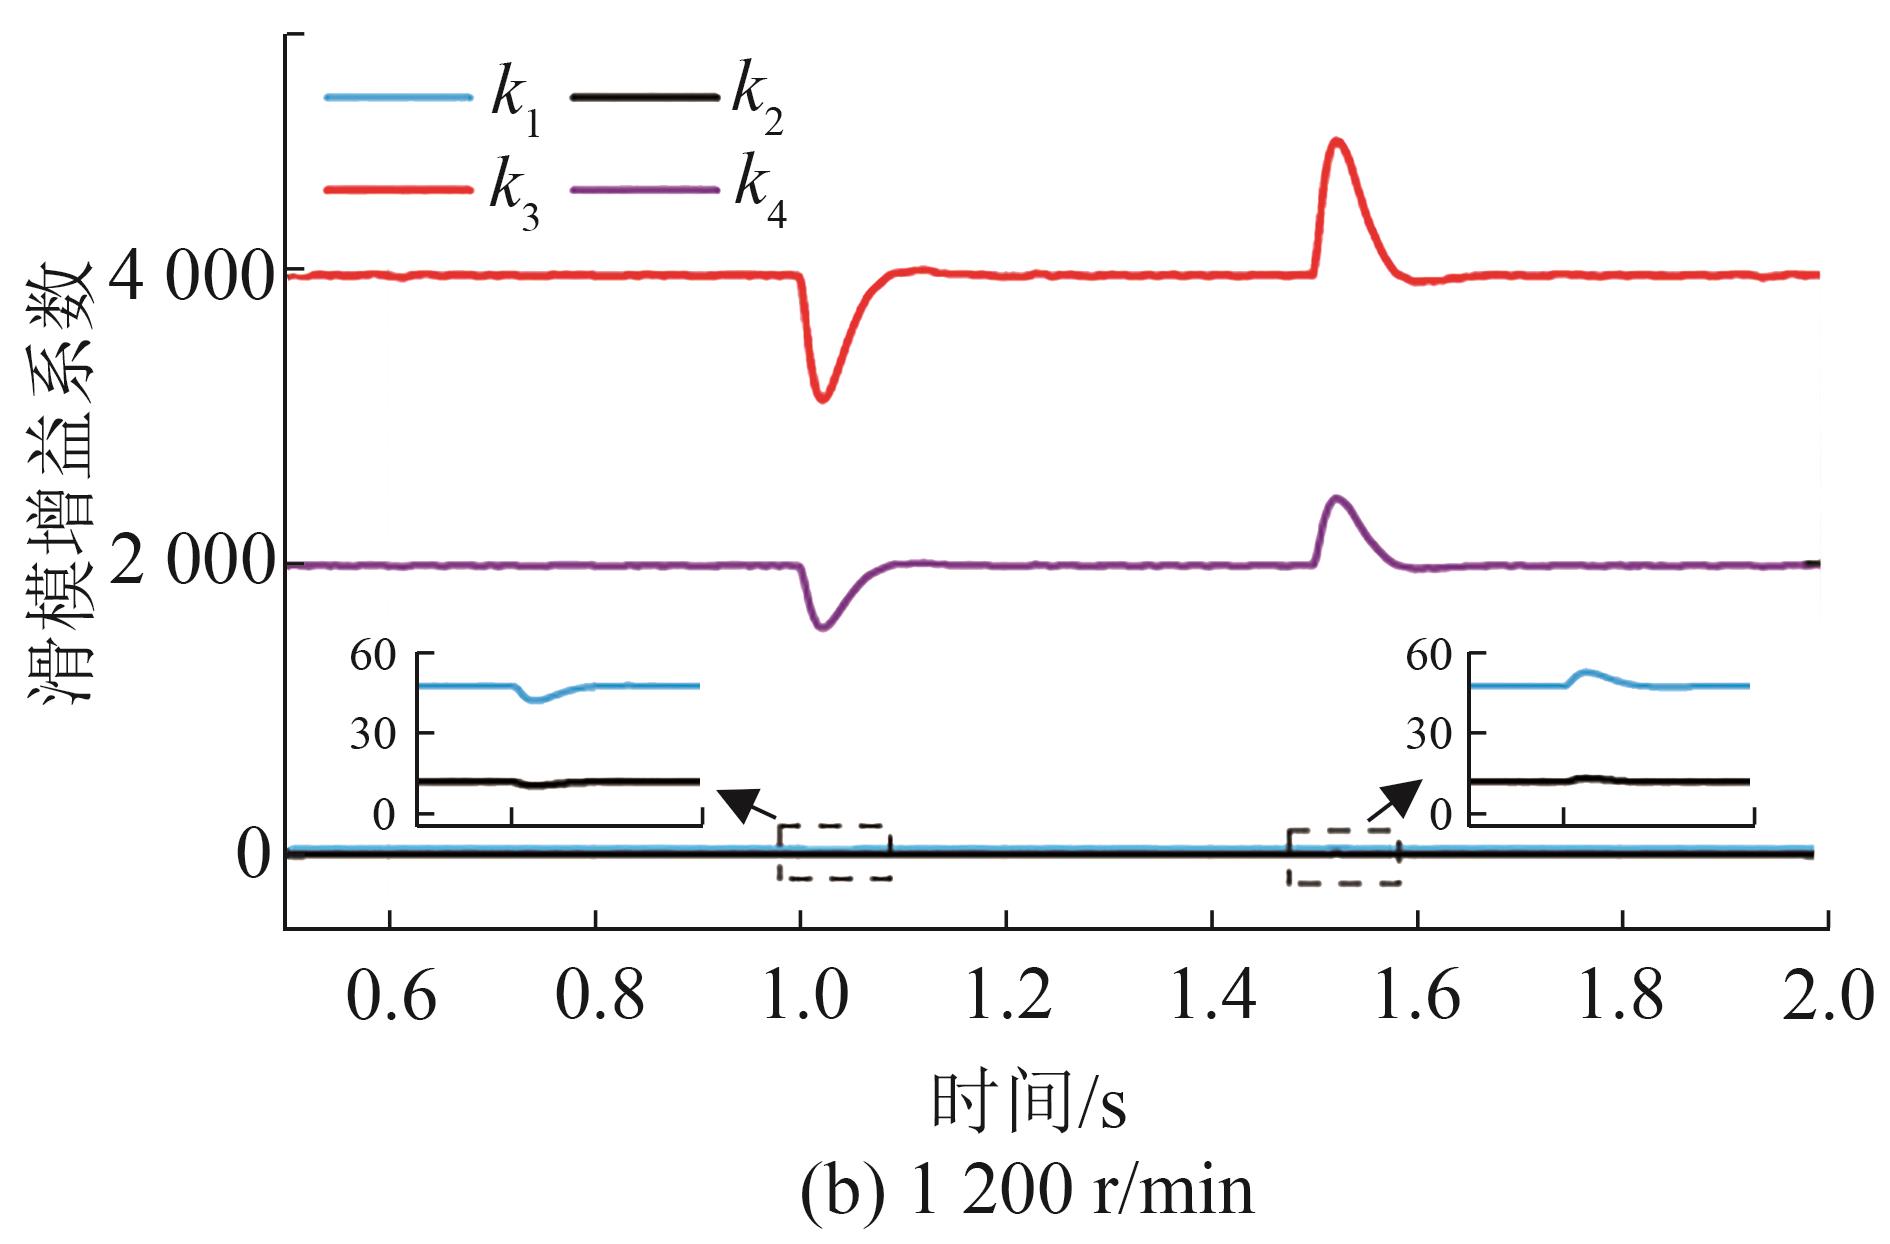
Variation of adaptive sliding-mode gain
| [1] | Li Guangqi, Yang Yongheng, Dai Zhiyong, et al. Undesirable Oscillations of Phase Locked Loop-based Position and Speed Estimator for Sensorless Control[J]. IEEE Transactions on Power Electronics, 2023, 38(7): 8754-8761. |
| [2] | 马立新, 朱勇杰, 季乐延. 神经网络优化的无感永磁同步电机控制系统[J]. 系统仿真学报, 2021, 33(3): 622-630. |
| Ma Lixin, Zhu Yongjie, Ji Leyan. Neural Network Optimized Sensorless Permanent Magnet Synchronous Motor Control System[J]. Journal of System Simulation, 2021, 33(3): 622-630. | |
| [3] | 张海刚, 聂圆圆, 张磊, 等. 基于改进卡尔曼滤波的无速度传感器探究[J]. 系统仿真学报, 2018, 30(10): 3761-3769. |
| Zhang Haigang, Nie Yuanyuan, Zhang Lei, et al. Research on Sensorless Control Method Based on Improved Kalman Filter of Sliding Mode Observer[J]. Journal of System Simulation, 2018, 30(10): 3761-3769. | |
| [4] | 王孝洪, 连维钊, 翟名扬. 基于改进型滑模观测器的永磁同步电机无位置传感器控制[J]. 控制理论与应用, 2023, 40(7): 1243-1251. |
| Wang Xiaohong, Lian Weizhao, Zhai Mingyang. Sensorless Control Method of Permanent Magnet Synchronous Motor Based on a Modified Sliding-mode Observer[J]. Control Theory & Applications, 2023, 40(7): 1243-1251. | |
| [5] | 孙洪博, 张晓宇, 柳向斌. 永磁同步电机无传感器控制研究综述[J]. 控制工程, 2024, 31(10): 1786-1796. |
| Sun Hongbo, Zhang Xiaoyu, Liu Xiangbin. A Review of Sensorless Control for Permanent Magnet Synchronous Motors[J]. Control Engineering of China, 2024, 31(10): 1786-1796. | |
| [6] | Wu Xuan, Yang Dan, Huang Sheng, et al. Improved Rotor Flux Observer with Disturbance Rejection for Sensorless SPMSM Control[J]. IEEE Transactions on Transportation Electrification, 2024, 10(2): 3603-3612. |
| [7] | 王南越, 尹明德, 周兆钟, 等. 基于龙伯格观测器的BLDC滑模控制系统仿真研究[J]. 电机与控制应用, 2023, 50(10): 24-30, 38. |
| Wang Nanyue, Yin Mingde, Zhou Zhaozhong, et al. Simulation Research on Sliding Mode Control System of BLDC Based on Luenberger Observer[J]. Electric Machines & Control Application, 2023, 50(10): 24-30, 38. | |
| [8] | 陈晗, 张永昌, 蒋涛, 等. 基于MRAS的无刷双馈电机无位置传感器鲁棒控制[J]. 电机与控制学报, 2024, 28(10): 24-33. |
| Chen Han, Zhang Yongchang, Jiang Tao, et al. Position Sensorless Robust Control of Brushless Doubly Fed Generator Based on the MRAS Observer[J]. Electric Machines and Control, 2024, 28(10): 24-33. | |
| [9] | 时隋翔, 刘瀚文, 王玉彬. 基于EKF的IPMSM无位置传感器控制估计误差补偿方法[J]. 电机与控制应用, 2024, 51(8): 20-29. |
| Shi Suixiang, Liu Hanwen, Wang Yubin. Estimation Error Compensation Method for Sensorless Control of Interior Permanent Magnet Synchronous Motors Based on Extended Kalman Filter[J]. Electric Machines & Control Application, 2024, 51(8): 20-29. | |
| [10] | 吴定会, 杨德亮, 陈锦宝. 基于滑模观测器的永磁同步电机矢量控制[J]. 系统仿真学报, 2018, 30(11): 4256-4267. |
| Wu Dinghui, Yang Deliang, Chen Jinbao. Vector Control of PMSM Based on Sliding Mode Observer[J]. Journal of System Simulation, 2018, 30(11): 4256-4267. | |
| [11] | Zuo Ying, Lai Chunyan, Iyer K L V. A Review of Sliding Mode Observer Based Sensorless Control Methods for PMSM Drive[J]. IEEE Transactions on Power Electronics, 2023, 38(9): 11352-11367. |
| [12] | Ren Ningning, Fan Le, Zhang Zan. Sensorless PMSM Control with Sliding Mode Observer Based on Sigmoid Function[J]. Journal of Electrical Engineering & Technology, 2021, 16(2): 933-939. |
| [13] | Wang Hanqing, Jiao Ticao, Xing Xuening, et al. Speed Regulation of PMSM Systems Based on a New Sliding Mode Reaching Law[J]. IEEE Access, 2024, 12: 24062-24070. |
| [14] | Wang Bo, Shao Yanzhen, Yu Yong, et al. High-order Terminal Sliding-mode Observer for Chattering Suppression and Finite-time Convergence in Sensorless SPMSM Drives[J]. IEEE Transactions on Power Electronics, 2021, 36(10): 11910-11920. |
| [15] | Zhu Xinkai, Huang Jiwei, Wang Pengda, et al. An Improved Sliding Model Observer Sensorless Control for PMSM Based on Fuzzy Logic Controller and DSOGI-FLL[J]. IEEE Transactions on Transportation Electrification, 2025, 11(1): 823-834. |
| [16] | Zhang Hanyu, Wu Mianzhi, Liu Jinlun, et al. Super Twisting Algorithm based SMO for Permanent Magnet Synchronous Motor Drives[C]//2025 4th International Conference on Electronic Electrical Engineering and Automatic Control (EEEAC). Piscataway: IEEE, 2025: 187-193. |
| [17] | Chang Junping, Cheng Mingyang. Rotor Position Estimation for a Position-sensorless FOC PMSM Drive——A Super-twisting-based Sliding Mode Observer Approach[J]. IEEE Access, 2025, 13: 164540-164551. |
| [18] | Zheng Shiqiang, Zhou Chong, Mao Kun. Novel Adaptive Super-twisting Sliding Mode Observer for the Control of the PMSM in the Centrifugal Compressors of Hydrogen Fuel Cells[J]. Energies, 2025, 18(17): 4675. |
| [19] | Zhang Kaibi, Fan Binghao. Research on Sensorless Control Algorithm for PMSM with Improved Super-twisting Sliding Mode Observer Based on SOGI-FLL[C]//2024 36th Chinese Control and Decision Conference (CCDC). Piscataway: IEEE, 2024: 2692-2697. |
| [20] | Moreno Jaime A, Osorio Marisol. A Lyapunov Approach to Second-order Sliding Mode Controllers and Observers[C]//2008 47th IEEE Conference on Decision and Control. Piscataway: IEEE, 2008: 2856-2861. |
| [21] | Ilioudis Vasilios C. Chattering Reduction Applied in PMSM Sensorless Control Using Second Order Sliding Mode Observer[C]//2015 9th International Conference on Compatibility and Power Electronics (CPE). Piscataway: IEEE, 2015: 240-245. |
| [22] | Qin Qinghai, Yi Xinqiang, Yu Zhongjun, et al. Enhanced Adaptive Disturbance Observer for Sensorless Control of PMSM with Multiharmonics Suppression Characteristics[J]. IEEE Journal of Emerging and Selected Topics in Power Electronics, 2025, 13(5): 5775-5786. |
| [23] | An Quntao, Zhang Jianqiu, An Qi, et al. Frequency-adaptive Complex-coefficient Filter-based Enhanced Sliding Mode Observer for Sensorless Control of Permanent Magnet Synchronous Motor Drives[J]. IEEE Transactions on Industry Applications, 2020, 56(1): 335-343. |
| [1] | Huilin Zhang, Yujie Jin, Haima Yang. Sensorless Control of PMSM Based on an ANFIS Optimized Flux Sliding Mode Observer [J]. Journal of System Simulation, 2022, 34(8): 1682-1690. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
 http://www.china-simulation.com

