系统仿真学报 ›› 2026, Vol. 38 ›› Issue (9): 2502-2517.doi: 10.16182/j.issn1004731x.joss.25-1261
• 专栏:自动驾驶与智能交通系统仿真 • 上一篇
王怀军1,2, 余宗华2, 徐陈鑫2, 李军怀1,2, 李辰智3, 尹俊杰2
收稿日期:2025-12-23
修回日期:2026-04-29
出版日期:2026-09-30
发布日期:2026-10-02
通讯作者:
李军怀
第一作者简介:王怀军(1981-),男,教授,博士,研究方向为智能感知与识别、三维重建等。
基金资助:Wang Huaijun1,2, Yu Zonghua2, Xu Chenxin2, Li Junhuai1,2, Li Chenzhi3, Yin Junjie2
Received:2025-12-23
Revised:2026-04-29
Online:2026-09-30
Published:2026-10-02
Contact:
Li Junhuai
摘要:
针对低重叠度点云初始位姿偏差大导致配准误差显著的问题,提出一种混合自注意力与交叉注意力的两阶段优化方法。通过等变自注意力增强方向特征表征,结合不变交叉注意力实现语义对齐,并采用正八面体群建模旋转等变性完成粗配准;引入多种注意力变体在锚点维度聚合特征,结合局部-全局模块实现精配准。在3DLoMatch数据集上,所提方法的注册召回率达77.0%,内点率为44.3%,添加随机旋转后注册召回率仍保持72.0%。实验表明,该方法通过等变特征提取与多注意力融合有效提升了低重叠场景的配准精度与旋转鲁棒性。
中图分类号:
王怀军,余宗华,徐陈鑫等 . 面向低重叠度的混合注意力点云配准方法[J]. 系统仿真学报, 2026, 38(9): 2502-2517.
Wang Huaijun,Yu Zonghua,Xu Chenxin,et al . Hybrid Attention for Low-overlap Point Cloud Registration[J]. Journal of System Simulation, 2026, 38(9): 2502-2517.
表1
主要符号说明
| 符号 | 定义与说明 |
|---|---|
| P, Q | 源点云与目标点云 |
| N, M | 原始源点云与目标点云的点数量 |
| T | 刚性变换矩阵 |
| R, t | 旋转矩阵与平移向量 |
| 点云P和Q中的三维坐标点 | |
| G | 离散旋转群(本文采用正八面体群) |
| g | 离散旋转群G中的一个特定旋转操作 |
| A | 正八面体离散旋转群的锚点数量 |
| Nʹ, Mʹ | 降采样后的点云点数量 |
| C | 特征通道维度 |
| 源点云与目标点云的等变特征 | |
| 注意力机制中的可训练权重矩阵 | |
| Rep(·) | 点云旋转特征置换操作函数 |
| 注意力权重分数 |
图1
SE(3)等变与不变特征提取网络结构
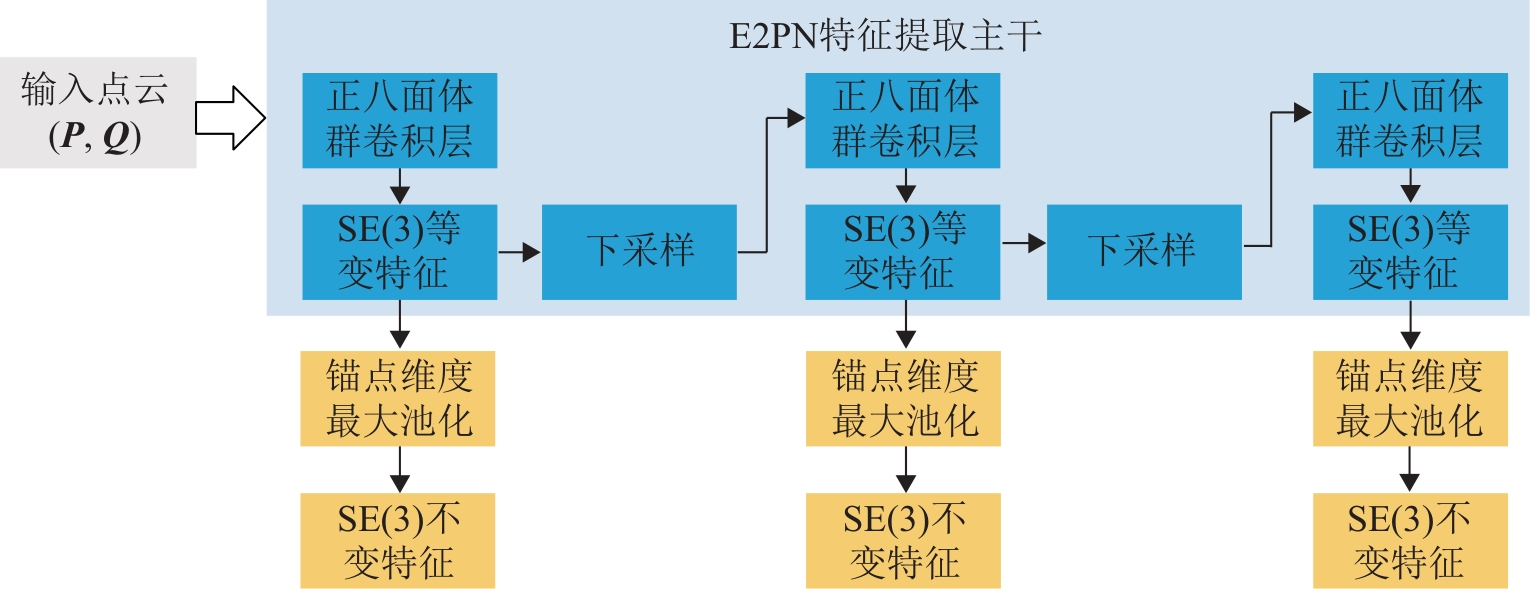
图2
正八面体通过顶点索引置换表示旋转操作示意图
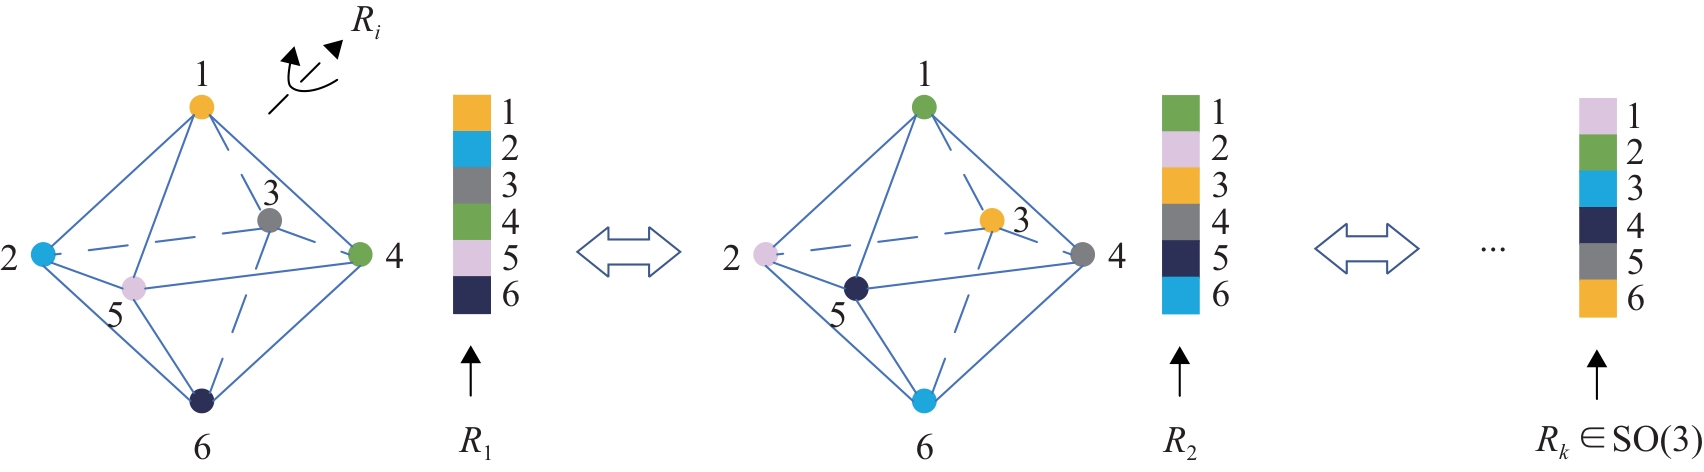
图3
SE(3)等变Transformer模块架构
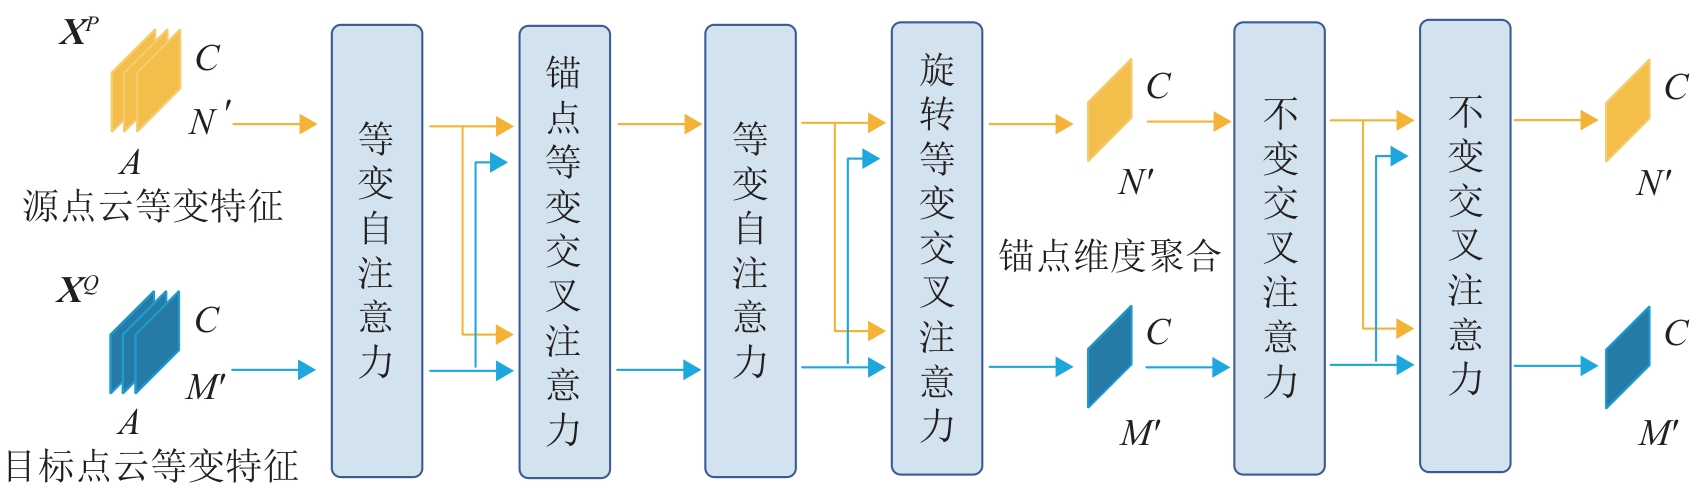
图4
等变自注意力网络
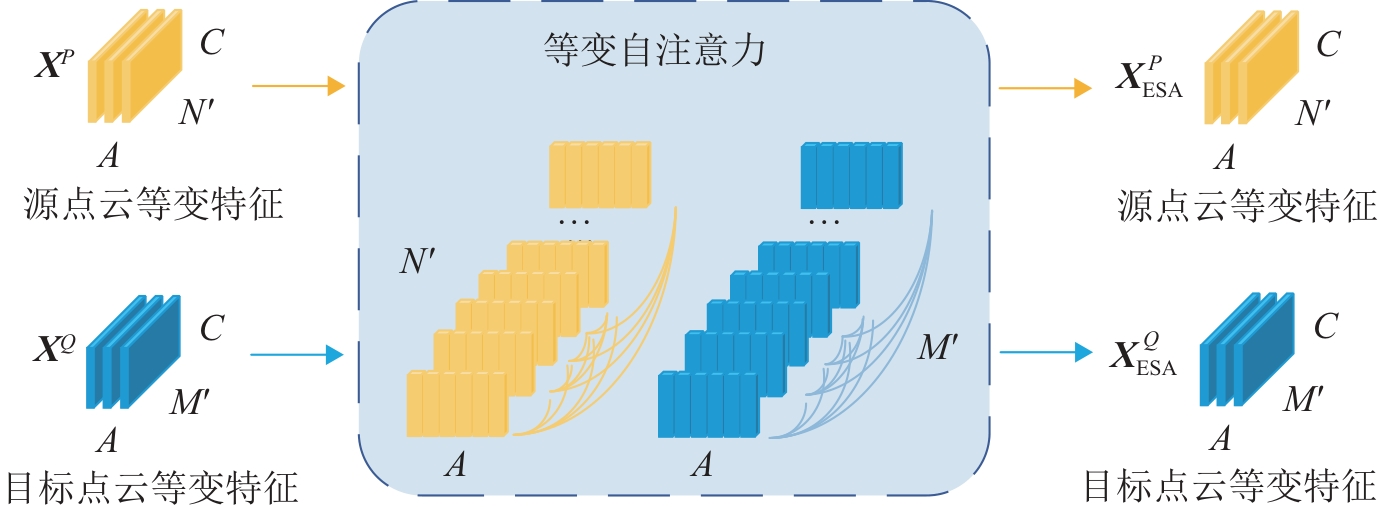
图5
基于锚点的等变交叉注意力网络
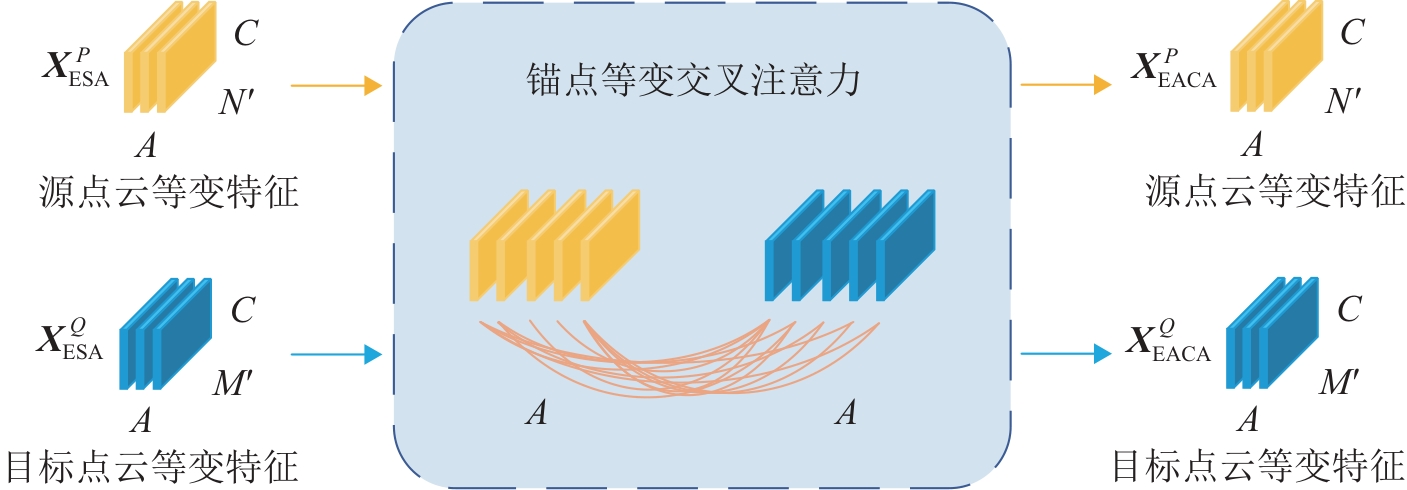
图6
基于旋转的等变交叉注意力网络
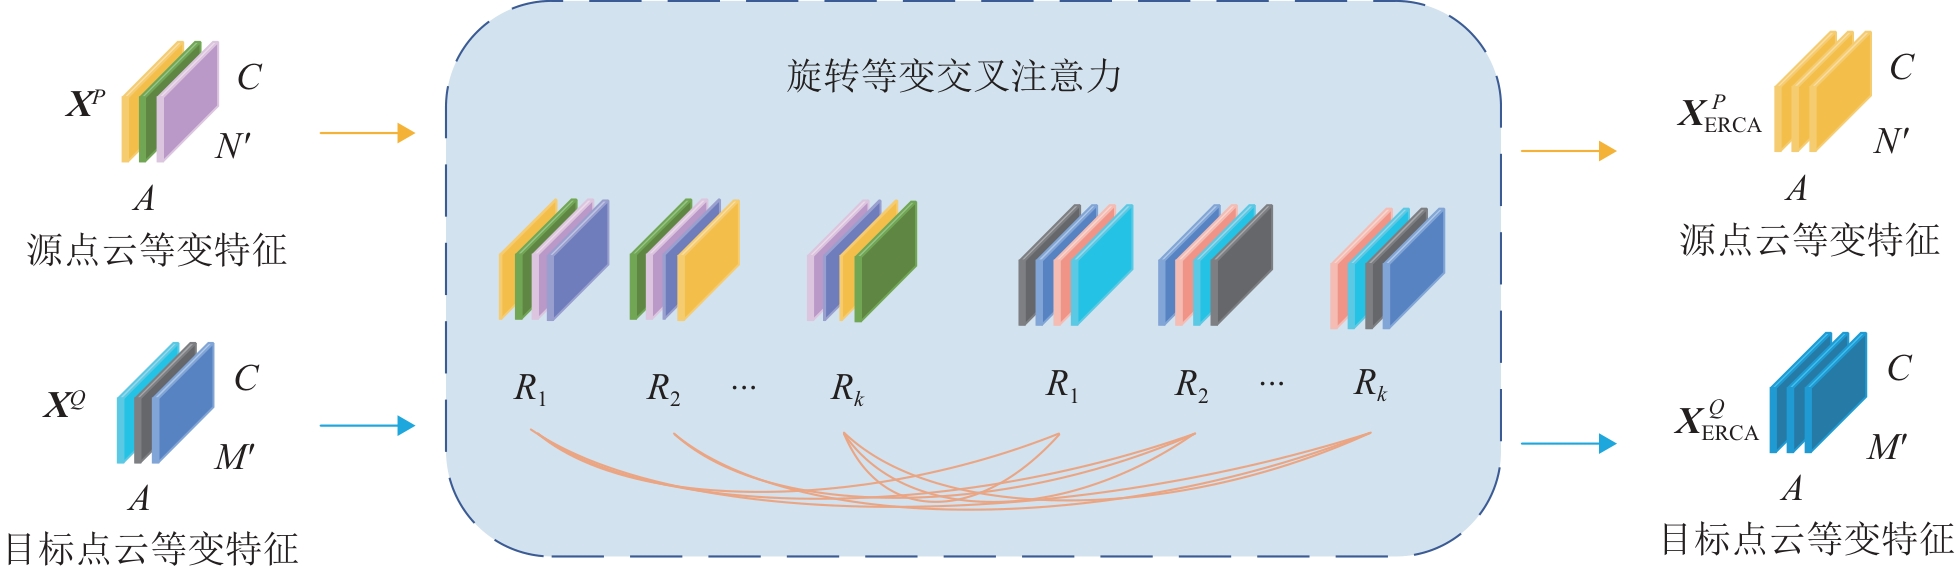
图7
不变交叉注意力网络
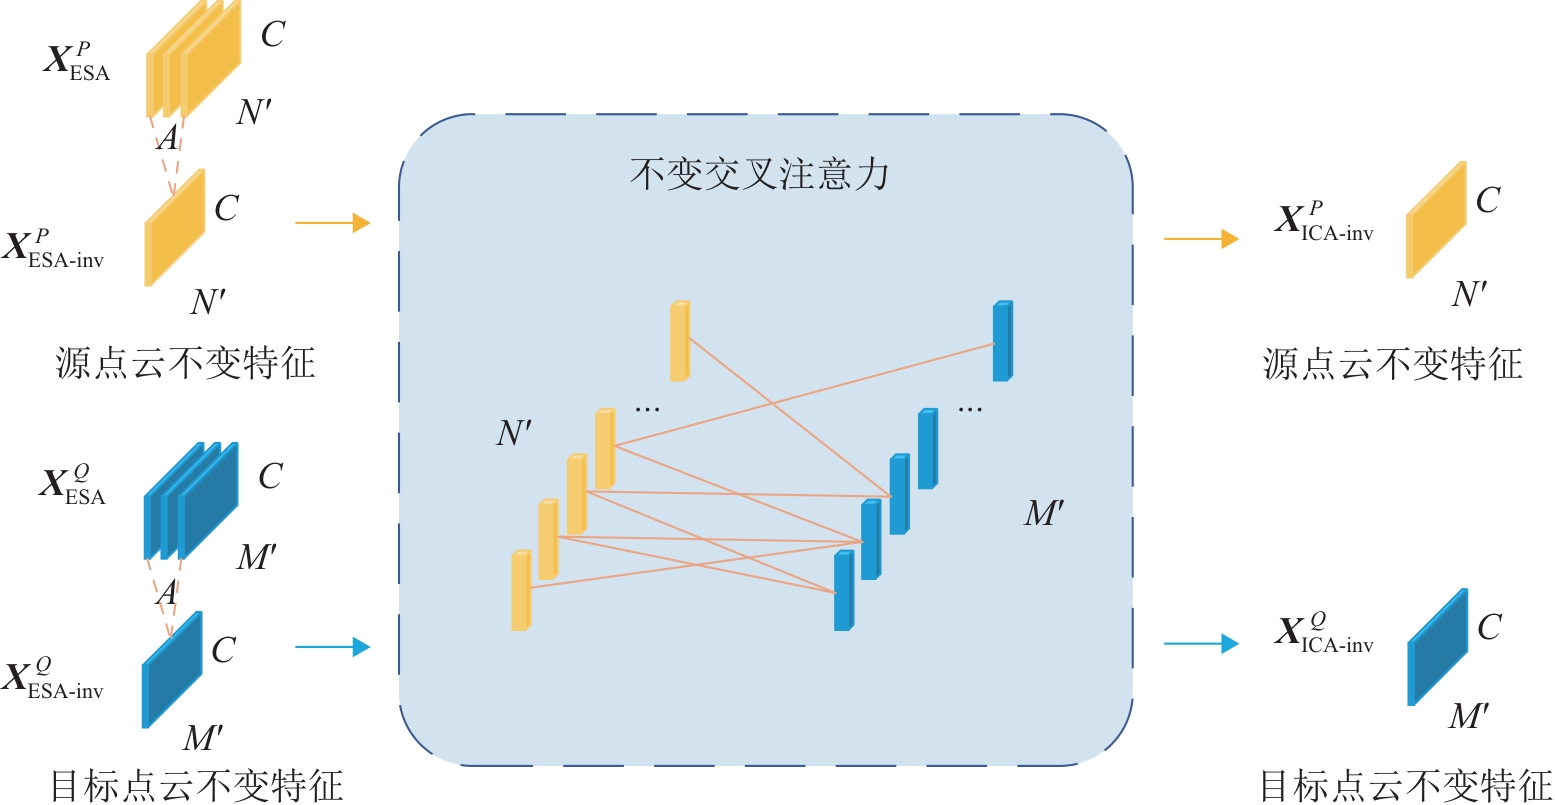
表2
实验环境配置
| 配置 | 规格 |
|---|---|
| 操作系统 | Windows 10 |
| GPU | NVIDIA GeForce RTX 4090 D |
| Python | 3.8.20 |
| CUDA | 11.8 |
| PyTorch | 2.0.0 |
表3
不同点云配准方法在3DLoMatch数据集上的评估结果 (%)
| 方法 | 随机旋转前 | 随机旋转后 | ||||
|---|---|---|---|---|---|---|
| RR | IR | FMR | RR | IR | FMR | |
| GeoTransformer[ | 75.0 | 43.5 | 88.3 | 71.8 | 40.0 | 85.8 |
| Lepard[ | 65.4 | 28.4 | 83.1 | 49.0 | 24.4 | 79.5 |
| RIGA[ | 65.1 | 32.1 | 85.1 | 66.9 | 32.1 | 84.5 |
| CoFiNet[ | 67.5 | 24.4 | 83.1 | 62.5 | 21.5 | 78.6 |
| FCGF[ | 40.1 | 21.4 | 76.6 | 40.8 | 21.6 | 75.4 |
| D3Feat[ | 37.2 | 13.2 | 67.3 | 36.1 | 13.5 | 67.6 |
| Predator[ | 59.8 | 26.7 | 78.6 | 57.7 | 26.2 | 75.7 |
| SpinNet[ | 59.8 | 20.5 | 75.3 | 58.1 | 20.1 | 75.3 |
| YOHO[ | 65.2 | 25.9 | 79.4 | 65.9 | 26.4 | 79.2 |
| RoReg[ | 70.3 | 39.6 | 82.1 | — | — | — |
| RoITr[ | 74.8 | 54.3 | 89.6 | — | — | — |
| 本文 | 77.0 | 44.3 | 88.8 | 72.0 | 43.6 | 88.0 |
表4
3DLoMatch点云下采样数量对不同配准方法的评估结果 (%)
| 评估指标 | 方法 | 下采样点数量 | ||||
|---|---|---|---|---|---|---|
| 5 000 | 2 500 | 1 000 | 500 | 250 | ||
| RR | RoReg[ | 70.3 | 70.2 | 68.3 | 67.6 | 64.9 |
| GeoTransformer[ | 75.0 | 74.4 | 74.7 | 73.7 | 73.2 | |
| CoFiNet[ | 67.2 | 66.2 | 68.5 | 66.1 | 61.3 | |
| Predator[ | 60.2 | 61.1 | 62.7 | 61.3 | 57.4 | |
| YOHO[ | 65.2 | 65.5 | 63.2 | 56.5 | 48.0 | |
| 本文 | 77.0 | 77.0 | 76.2 | 75.6 | 75.0 | |
| IR | RoReg[ | 39.6 | 39.9 | 33.6 | 32.0 | 34.5 |
| GeoTransformer[ | 43.5 | 47.9 | 54.0 | 56.6 | 58.4 | |
| CoFiNet[ | 24.4 | 25.9 | 26.7 | 26.8 | 27.1 | |
| Predator[ | 26.7 | 28.0 | 28.3 | 25.7 | 25.7 | |
| YOHO[ | 25.9 | 23.3 | 22.6 | 18.2 | 15.0 | |
| 本文 | 44.3 | 50.2 | 54.8 | 56.7 | 57.9 | |
| FMR | RoReg[ | 82.1 | 82.3 | 81.2 | 80.7 | 80.5 |
| GeoTransformer[ | 88.3 | 87.2 | 87.7 | 87.8 | 87.3 | |
| CoFiNet[ | 83.1 | 83.1 | 82.9 | 82.7 | 82.7 | |
| Predator[ | 78.6 | 79.3 | 79.4 | 79.2 | 77.8 | |
| YOHO[ | 79.4 | 78.1 | 76.3 | 73.8 | 69.1 | |
| 本文 | 88.8 | 88.6 | 88.6 | 88.5 | 87.0 | |
表5
随机旋转后3DLoMatch点云下采样数量对不同配准方法的评估结果 (%)
| 评估指标 | 方法 | 下采样点数量 | ||||
|---|---|---|---|---|---|---|
| 5 000 | 2 500 | 1 000 | 500 | 250 | ||
| RR | GeoTransformer[ | 71.8 | 67.8 | 68.0 | 66.7 | 66.5 |
| YOHO[ | 65.9 | — | — | — | — | |
| 本文 | 72.0 | 71.1 | 71.3 | 70.6 | 69.7 | |
| IR | GeoTransformer[ | 40.0 | 44.1 | 50.7 | 53.6 | 55.5 |
| YOHO[ | 26.4 | — | — | — | — | |
| 本文 | 43.6 | 49.5 | 55.1 | 57.5 | 59.0 | |
| FMR | GeoTransformer[ | 85.8 | 86.1 | 86.0 | 86.0 | 85.9 |
| YOHO[ | 79.2 | — | — | — | — | |
| 本文 | 88.0 | 88.4 | 88.5 | 88.1 | 87.2 | |
表6
在KITTI数据集上的评估结果
| 方法 | RRE/(°) | RTE/cm | RR/% |
|---|---|---|---|
| FCGF[ | 0.30 | 9.5 | 96.6 |
| D3Feat[ | 0.30 | 7.2 | 99.8 |
| SpinNet[ | 0.47 | 9.9 | 99.1 |
| Predator[ | 0.27 | 6.8 | 99.8 |
| CoFiNet[ | 0.41 | 8.2 | 99.8 |
| GeoTransformer[ | 0.24 | 6.8 | 99.8 |
| 本文 | 0.22 | 6.7 | 99.8 |
图8
可视化配准结果
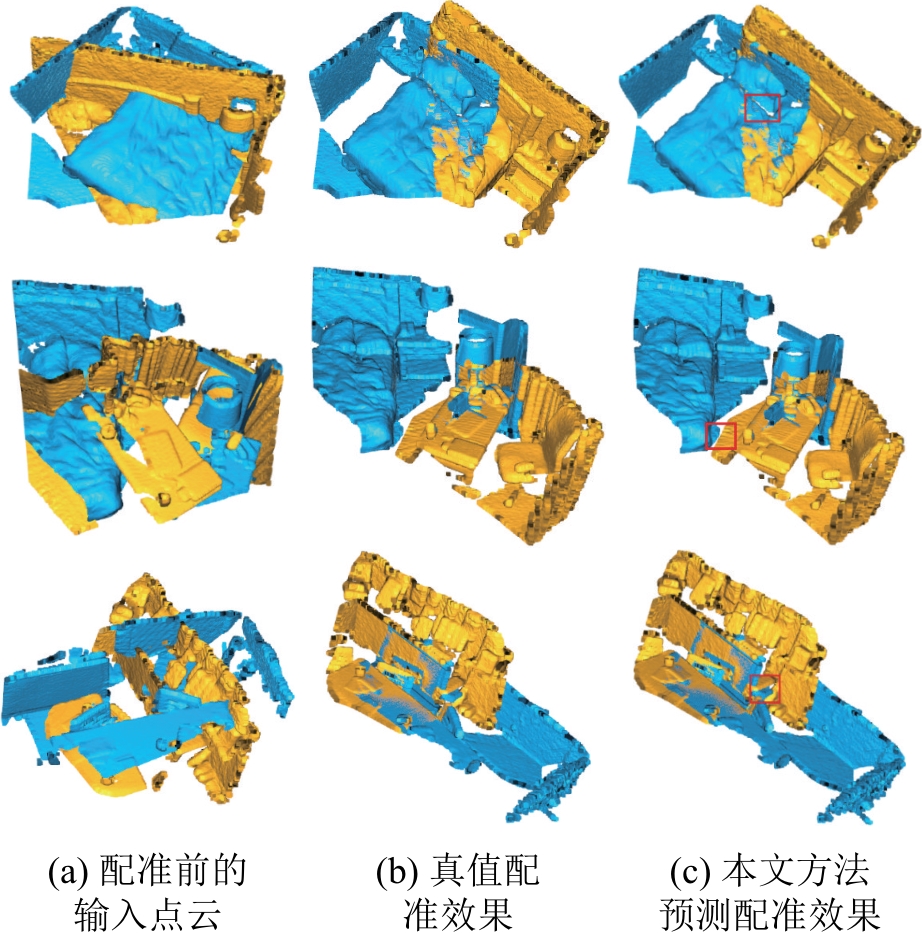
表7
在3DLoMatch测试集上的消融实验 (%)
| 方法 | RR | IR | FMR |
|---|---|---|---|
| KPConv替换 | 58.5 | 31.2 | 79.3 |
| 单层特征提取 | 71.8 | 38.7 | 83.6 |
| 本文 | 77.0 | 44.3 | 88.8 |
表8
SE(3)等变Transformer模块在3DLoMatch测试集上的消融实验 (%)
| 方法 | RR | IR | FMR |
|---|---|---|---|
| 普通自注意力替换等变自注意力 | 68.2 | 35.4 | 79.6 |
| 移除基于锚点的等变交叉注意力 | 73.5 | 39.1 | 84.2 |
| 移除基于旋转的等变交叉注意力 | 74.8 | 41.7 | 85.9 |
| 本文 | 77.0 | 44.3 | 88.8 |
表9
特征输出维度在3DLoMatch测试集上的灵敏度分析
| 特征维度 | RR | IR | FMR |
|---|---|---|---|
| 256 | 72.4 | 38.5 | 83.2 |
| 512 | 75.1 | 41.8 | 86.5 |
| 1 024 | 77.0 | 44.3 | 88.8 |
| 2 048 | 76.5 | 43.9 | 88.1 |
表10
降采样阶段数在3DLoMatch测试集上的灵敏度分析
| 降采样阶段数 | RR | IR | FMR |
|---|---|---|---|
| 3 | 71.5 | 39.2 | 82.5 |
| 4 | 77.0 | 44.3 | 88.8 |
| 5 | 74.2 | 40.5 | 85.3 |
| [1] | 鲁斌, 王明晗, 孙洋, 等. 全局信息感知与局部特征融合的高效三维目标检测[J]. 系统仿真学报, 2024, 36(11): 2616-2630. |
| Lu Bin, Wang Minghan, Sun Yang, et al. Global-local Fusion for Efficient 3D Object Detection[J]. Journal of System Simulation, 2024, 36(11): 2616-2630. | |
| [2] | 王若萱, 吴建平, 徐辉. 自动驾驶汽车感知系统仿真的研究及应用综述[J]. 系统仿真学报, 2022, 34(12): 2507-2521. |
| Wang Ruoxuan, Wu Jianping, Xu Hui. Overview of Research and Application on Autonomous Vehicle Oriented Perception System Simulation[J]. Journal of System Simulation, 2022, 34(12): 2507-2521. | |
| [3] | Salas-Moreno R F, Newcombe R A, Strasdat H, et al. SLAM++: Simultaneous Localisation and Mapping at the Level of Objects[C]//2013 IEEE Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE, 2013: 1352-1359. |
| [4] | 李海英, 徐浩男, 郝俊芳. 面向三维场景的电力设备高斯溅射建模研究[J]. 系统仿真学报, 2026, 38(3): 595-607. |
| Li Haiying, Xu Haonan, Hao Junfang. Research on Gaussian Splatting Modeling of Power Equipment in 3D Scenes[J]. Journal of System Simulation, 2026, 38(3): 595-607. | |
| [5] | 周伟, 苍慜楠, 程浩宗. 基于AR技术的文物数字化三维图像重建方法[J]. 图学学报, 2025, 46(2): 369-381. |
| Zhou Wei, Cang Minnan, Cheng Haozong. Research on the Method of 3D Image Reconstruction for Cultural Relics Based on AR Technology[J]. Journal of Graphics, 2025, 46(2): 369-381. | |
| [6] | 张顺利, 徐艳芝, 周明全, 等. 基于自适应邻域匹配的点云配准方法[J]. 计算机学报, 2019, 42(9): 2114-2126. |
| Zhang Shunli, Xu Yanzhi, Zhou Mingquan, et al. Registration of Point Clouds Based on Matching of General Adaptive Neighborhood[J]. Chinese Journal of Computers, 2019, 42(9): 2114-2126. | |
| [7] | Thomas Hugues, Qi C R, Deschaud Jean-Emmanuel, et al. KPConv: Flexible and Deformable Convolution for Point Clouds[C]//2019 IEEE/CVF International Conference on Computer Vision (ICCV). Piscataway: IEEE, 2019: 6410-6419. |
| [8] | Guo Menghao, Cai Junxiong, Liu Zhengning, et al. PCT: Point Cloud Transformer[J]. Computational Visual Media, 2021, 7(2): 187-199. |
| [9] | 杜沅昊, 耿秀丽, 徐诚智, 等. 基于改进灰狼算法和自适应分裂KD-tree的点云配准方法[J]. 系统仿真学报, 2025, 37(2): 424-435. |
| Du Yuanhao, Geng Xiuli, Xu Chengzhi, et al. Point Cloud Registration Method Based on Improved Grey Wolf Algorithm and Adaptive Splitting KD-tree[J]. Journal of System Simulation, 2025, 37(2): 424-435. | |
| [10] | Koide Kenji, Yokozuka Masashi, Oishi Shuji, et al. Voxelized GICP for Fast and Accurate 3D Point Cloud Registration[C]//2021 IEEE International Conference on Robotics and Automation (ICRA). Piscataway: IEEE, 2021: 11054-11059. |
| [11] | Wei Jiangxia, Cheng Lan, Hu Zhimin, et al. HPNet: High Precision Point Cloud Registration Using Feature Pyramid and Hybrid Position Encoding[J]. Computers & Graphics, 2024, 119: 103896. |
| [12] | Hu Han, Hou Yongkuo, Ding Yulin, et al. V2PNet: Voxel-to-point Feature Propagation and Fusion That Improves Feature Representation for Point Cloud Registration[J]. IEEE Journal of Selected Topics in Applied Earth Observations and Remote Sensing, 2023, 16: 5077-5088. |
| [13] | Zhao Guiyu, Du Zewen, Guo Zhentao, et al. VRHCF: Cross-source Point Cloud Registration via Voxel Representation and Hierarchical Correspondence Filtering[C]//2024 IEEE International Conference on Multimedia and Expo (ICME). Piscataway: IEEE, 2024: 1-6. |
| [14] | Mengjin Lü, Yang Jie, Qi Zhiquan, et al. Rigid Pairwise 3D Point Cloud Registration: A Survey[J]. Pattern Recognition, 2024, 151: 110408. |
| [15] | Slimani Karim, Achard Catherine, Tamadazte Brahim. RoCNet++: Triangle-based Descriptor for Accurate and Robust Point Cloud Registration[J]. Pattern Recognition, 2024, 147: 110108. |
| [16] | Fischer Kai, Simon Martin, Ölsner Florian, et al. StickyPillars: Robust and Efficient Feature Matching on Point Clouds using Graph Neural Networks[C]//2021 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2021: 313-323. |
| [17] | Chen Suyi, Xu Hao, Li Haipeng, et al. PointRegGPT: Boosting 3D Point Cloud Registration Using Generative Point-cloud Pairs for Training[C]//Computer Vision — ECCV 2024. Cham: Springer Nature Switzerland, 2025: 272-289. |
| [18] | Poiesi Fabio, Boscaini Davide. Learning General and Distinctive 3D Local Deep Descriptors for Point Cloud Registration[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2023, 45(3): 3979-3985. |
| [19] | Zhao Bao, Liu Qiang, Wang Zihan, et al. HA-TiNet: Learning a Distinctive and General 3D Local Descriptor for Point Cloud Registration[J]. IEEE Transactions on Visualization and Computer Graphics, 2025, 31(9): 5507-5518. |
| [20] | Choy C, Park Jaesik, Koltun V. Fully Convolutional Geometric Features[C]//2019 IEEE/CVF International Conference on Computer Vision (ICCV). Piscataway: IEEE, 2019: 8957-8965. |
| [21] | Wang Haiping, Liu Yuan, Dong Zhen, et al. You Only Hypothesize Once: Point Cloud Registration with Rotation-equivariant Descriptors[C]//Proceedings of the 30th ACM International Conference on Multimedia. New York: ACM, 2022: 1630-1641. |
| [22] | Yu Hao, Qin Zheng, Hou Ji, et al. Rotation-invariant Transformer for Point Cloud Matching[C]//2023 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2023: 5384-5393. |
| [23] | Dias Pais G, Ramalingam S, Venu Madhav Govindu, et al. 3DRegNet: A Deep Neural Network for 3D Point Registration[C]//2020 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2020: 7191-7201. |
| [24] | Lee Junha, Kim Seungwook, Cho Minsu, et al. Deep Hough Voting for Robust Global Registration[C]//2021 IEEE/CVF International Conference on Computer Vision (ICCV). Piscataway: IEEE, 2021: 15974-15983. |
| [25] | Yu Hao, Li Fu, Saleh Mahdi, et al. CoFiNet: Reliable Coarse-to-fine Correspondences for Robust Point Cloud Registration[C]//Proceedings of the 35th International Conference on Neural Information Processing Systems. Red Hook: Curran Associates Inc., 2021: 23872-23884. |
| [26] | Qin Zheng, Yu Hao, Wang Changjian, et al. GeoTransformer: Fast and Robust Point Cloud Registration with Geometric Transformer[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2023, 45(8): 9806-9821. |
| [27] | Chen Hong, Yan Pei, Xiang Sihe, et al. Dynamic Cues-assisted Transformer for Robust Point Cloud Registration[C]//2024 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2024: 21698-21707. |
| [28] | Lin T Y, Zhu Minghan, Ghaffari M. Lie Neurons: Adjoint-equivariant Neural Networks for Semisimple Lie Algebras[C]//Proceedings of the 41st International Conference on Machine Learning. Chia Laguna Resort: PMLR, 2024: 30529-30545. |
| [29] | Deng Congyue, Litany O, Duan Yueqi, et al. Vector Neurons: A General Framework for SO(3)-equivariant Networks[C]//2021 IEEE/CVF International Conference on Computer Vision (ICCV). Piscataway: IEEE, 2021: 12180-12189. |
| [30] | Chen Haiwei, Liu Shichen, Chen Weikai, et al. Equivariant Point Network for 3D Point Cloud Analysis[C]//2021 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2021: 14509-14518. |
| [31] | Zhu Minghan, Ghaffari M, Clark W A, et al. E2PN: Efficient SE(3) — Equivariant Point Network[C]//2023 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2023: 1223-1232. |
| [32] | Luo Shitong, Li Jiahan, Guan Jiaqi, et al. Equivariant Point Cloud Analysis via Learning Orientations for Message Passing[C]//2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2022: 18910-18919. |
| [33] | Zeng A, Song Shuran, Nießner M, et al. 3DMatch: Learning Local Geometric Descriptors from RGB-D Reconstructions[C]//2017 IEEE Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2017: 199-208. |
| [34] | Huang Shengyu, Zan Gojcic, Usvyatsov Mikhail, et al. PREDATOR: Registration of 3D Point Clouds with Low Overlap[C]//2021 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2021: 4265-4274. |
| [35] | Geiger Andreas, Lenz Philip, Urtasun R. Are We Ready for Autonomous Driving? The KITTI Vision Benchmark Suite[C]//2012 IEEE Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE, 2012: 3354-3361. |
| [36] | Bai Xuyang, Luo Zixin, Zhou Lei, et al. PointDSC: Robust Point Cloud Registration Using Deep Spatial Consistency[C]//2021 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2021: 15854-15864. |
| [37] | Li Yang, Harada Tatsuya. Lepard: Learning Partial Point Cloud Matching in Rigid and Deformable Scenes[C]//2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2022: 5544-5554. |
| [38] | Yu Hao, Hou Ji, Qin Zheng, et al. Riga: Rotation-invariant and Globally-aware Descriptors for Point Cloud Registration[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2024, 46(5): 3796-3812. |
| [39] | Bai Xuyang, Luo Zixin, Zhou Lei, et al. D3Feat: Joint Learning of Dense Detection and Description of 3D Local Features[C]//2020 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2020: 6358-6366. |
| [40] | Ao Sheng, Hu Qingyong, Yang Bo, et al. SpinNet: Learning a General Surface Descriptor for 3D Point Cloud Registration[C]//2021 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Piscataway: IEEE, 2021: 11748-11757. |
| [41] | Wang Haiping, Liu Yuan, Hu Qingyong, et al. RoReg: Pairwise Point Cloud Registration with Oriented Descriptors and Local Rotations[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2023, 45(8): 10376-10393. |
| [1] | 李金蔚, 刘晓阳, 鞠儒生. 面向跨模态理解的时序行为定位方法研究[J]. 系统仿真学报, 2026, 38(7): 2053-2067. |
| [2] | 王军, 刘敏, 张啸川, 丁一珊, 冯居辉, 庄晔. 基于神经网络的无人车动力学建模方法[J]. 系统仿真学报, 2026, 38(4): 932-947. |
| [3] | 万飞, 尹勇. 融合GPS先验信息的3D高斯溅射大规模场景配准技术[J]. 系统仿真学报, 2026, 38(3): 563-571. |
| [4] | 冯雪健, 丁晗, 童逸琦, 霍超颖, 张燕津. 一种目标典型航迹形状仿真及多视角识别算法[J]. 系统仿真学报, 2026, 38(3): 725-735. |
| [5] | 刘沛津, 张闽心, 何林, 孙艺阁, 苏庭琪. 面向城市复杂环境视觉地点识别算法研究[J]. 系统仿真学报, 2026, 38(3): 818-828. |
| [6] | 邹长军, 葛志宇, 钟晨曦. 基于时空Swin Transformer的流固耦合交互序列图像预测网络[J]. 系统仿真学报, 2026, 38(1): 112-124. |
| [7] | 马仑, 杨跃, 王迨贺, 廖桂生, 李幸. 联合自注意力机制与权值共享的人体行为识别模型[J]. 系统仿真学报, 2025, 37(9): 2409-2419. |
| [8] | 王秉珩, 刘庭瑞, 杨帆, 张欢, 李伟, 马萍, 杨明. 仿真可信度智能评估需求及方法研究[J]. 系统仿真学报, 2025, 37(7): 1710-1722. |
| [9] | 陈坤, 陈亮, 谢济铭, 刘丰博, 陈泰熊, 位路宽. 基于LSTM-GNN的畸形交叉口自适应信号控制仿真研究[J]. 系统仿真学报, 2025, 37(6): 1343-1351. |
| [10] | 许明, 齐光尧, 奇格奇. 基于动态反投影网络的细粒度交通流推断模型[J]. 系统仿真学报, 2025, 37(3): 657-666. |
| [11] | 江达伟, 董阳阳, 张立东, 路宵, 董春曦. 基于深度学习的空中目标威胁评估技术研究[J]. 系统仿真学报, 2025, 37(3): 791-802. |
| [12] | 李维刚, 邹少峰, 王永强, 余楚翔. 基于强度信息特征滤波的激光SLAM算法[J]. 系统仿真学报, 2025, 37(2): 392-403. |
| [13] | 杜沅昊, 耿秀丽, 徐诚智, 刘银华. 基于改进灰狼算法和自适应分裂KD-Tree的点云配准方法[J]. 系统仿真学报, 2025, 37(2): 424-435. |
| [14] | 李想, 任晓羽, 周永兵, 张剑. 基于改进D3QN算法的随机工时下柔性综合调度问题研究[J]. 系统仿真学报, 2025, 37(2): 474-486. |
| [15] | 张文康, 孙霄峰, 钟一平, 尹勇. 基于图神经网络的船舶液舱晃荡数值仿真[J]. 系统仿真学报, 2025, 37(12): 3087-3099. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
 http://www.china-simulation.com

